Related Experiment Video
Updated: Jan 6, 2026
Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
Finding normally hyperbolic invariant manifolds in two and three degrees of freedom with Hénon-Heiles-type potential
Shibabrat Naik1, Stephen Wiggins1
1School of Mathematics, University of Bristol, University Walk, Clifton BS8 1TW, Bristol, United Kingdom.

Abstract:
We present a method based on a Lagrangian descriptor for revealing the high-dimensional phase space structures that are of interest in nonlinear Hamiltonian systems with index-1 saddle. These phase space structures include a normally hyperbolic invariant manifold and its stable and unstable manifolds, which act as codimension-1 barriers to phase space transport. In this article, finding the invariant manifolds in high-dimensional phase space will constitute identifying coordinates on these invariant manifolds. The method of Lagrangian descriptor is demonstrated by applying to classical two and three degrees of freedom Hamiltonian systems which have implications for myriad applications in chemistry, engineering, and physics.
More Related Videos
 09:46
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
 08:49
Author Spotlight: Unveiling the Potential of VSFG Microscopy in Studying Mesoscopically Heterogeneous Self-Assembled Structures
Published on: December 1, 2023
Related Concept Videos
 01:30
Hyperbolas
 01:30
Geometry of Hyperbolas
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:04
Force and Potential Energy in Three Dimensions
 01:22
Generalized Hooke's Law
 01:11
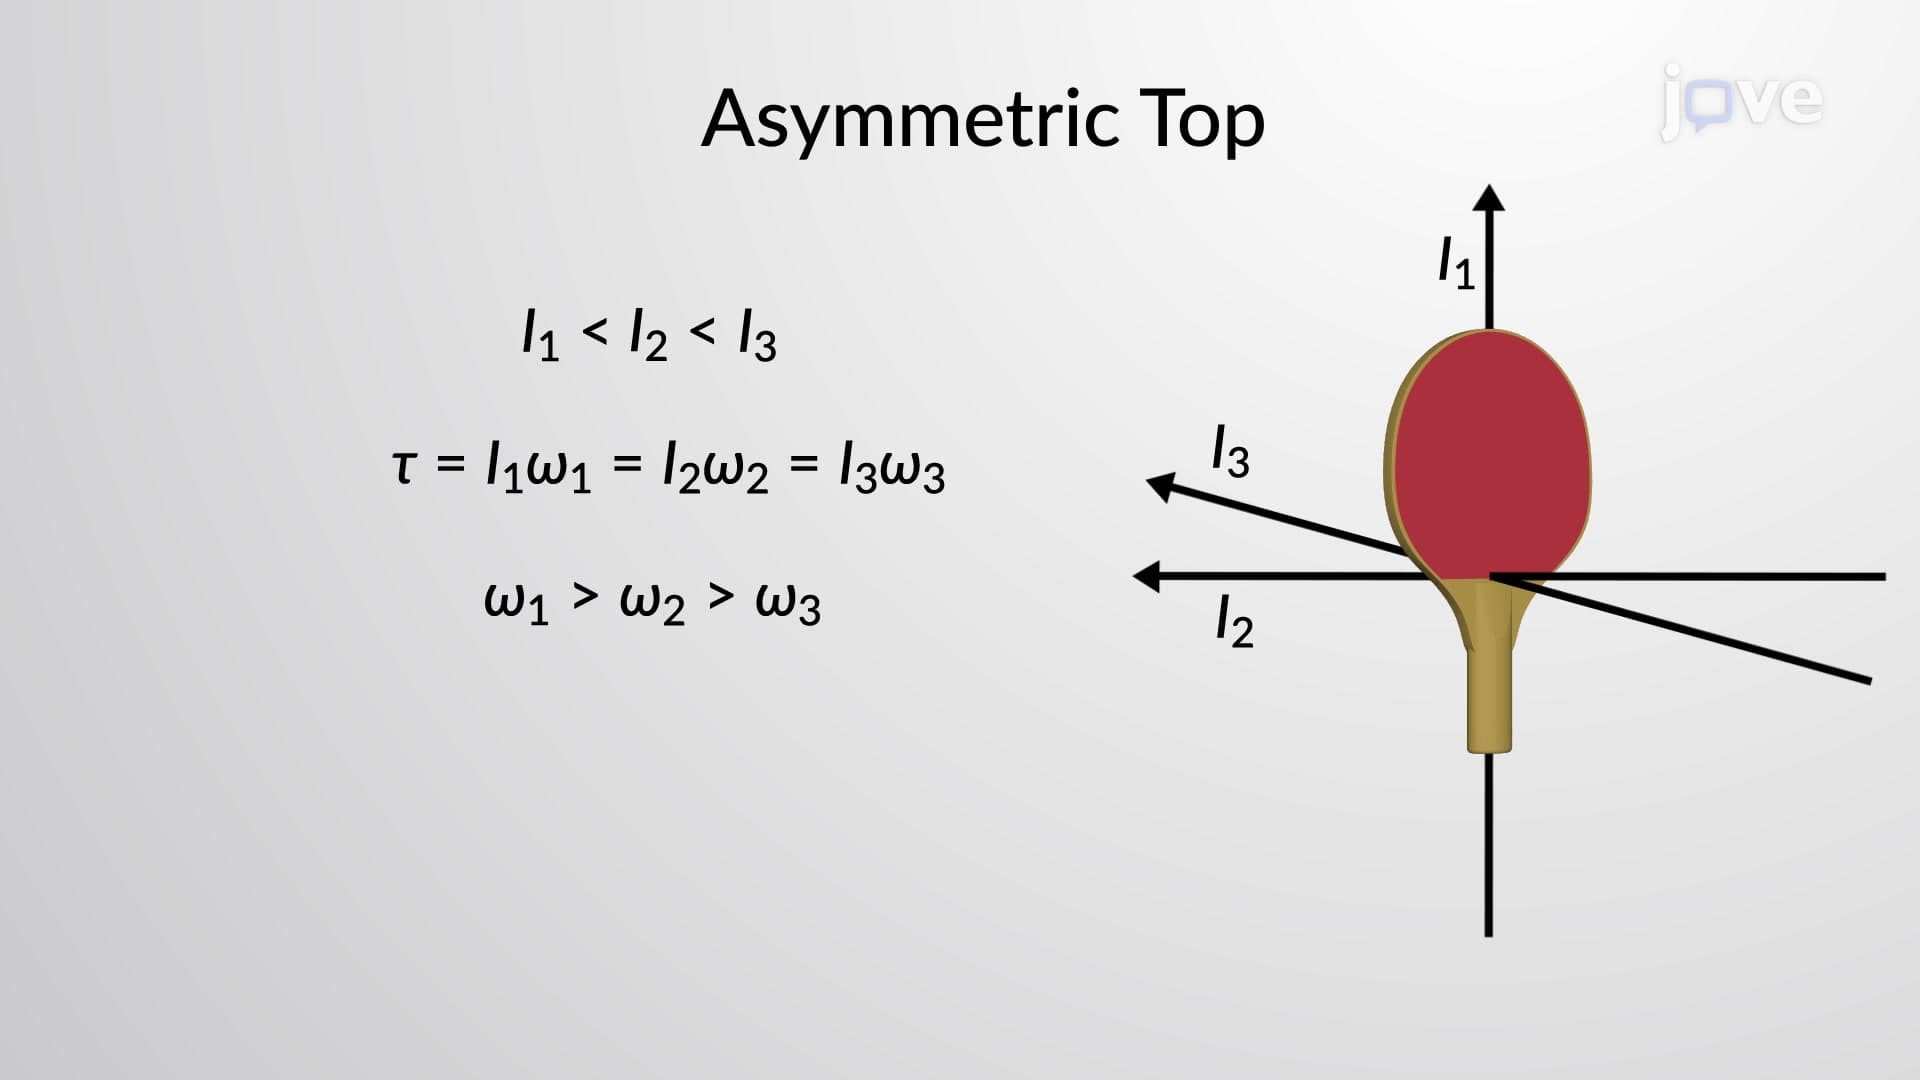
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...