Related Experiment Video
Updated: Jan 5, 2026

Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Modeling and Planning with Macro-Actions in Decentralized POMDPs
Christopher Amato1, George Konidaris2, Leslie P Kaelbling3
1Khoury College of Computer Sciences, Northeastern University, Boston, MA 02115 USA.

Abstract:
Decentralized partially observable Markov decision processes (Dec-POMDPs) are general models for decentralized multi-agent decision making under uncertainty. However, they typically model a problem at a low level of granularity, where each agent's actions are primitive operations lasting exactly one time step. We address the case where each agent has macro-actions: temporally extended actions that may require different amounts of time to execute. We model macro-actions as options in a Dec-POMDP, focusing on actions that depend only on information directly available to the agent during execution. Therefore, we model systems where coordination decisions only occur at the level of deciding which macro-actions to execute. The core technical difficulty in this setting is that the options chosen by each agent no longer terminate at the same time. We extend three leading Dec-POMDP algorithms for policy generation to the macro-action case, and demonstrate their effectiveness in both standard benchmarks and a multi-robot coordination problem. The results show that our new algorithms retain agent coordination while allowing high-quality solutions to be generated for significantly longer horizons and larger state-spaces than previous Dec-POMDP methods. Furthermore, in the multi-robot domain, we show that, in contrast to most existing methods that are specialized to a particular problem class, our approach can synthesize control policies that exploit opportunities for coordination while balancing uncertainty, sensor information, and information about other agents.
More Related Videos
 10:27
Preparation of Highly Porous Coordination Polymer Coatings on Macroporous Polymer Monoliths for Enhanced Enrichment of Phosphopeptides
Published on: July 14, 2015
 06:56
Particles without a Box: Brush-first Synthesis of Photodegradable PEG Star Polymers under Ambient Conditions
Published on: October 10, 2013
Related Concept Videos
 01:06
Fixed Action Patterns
 01:26
Methods of Documentation II: POMR
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:09
Decision Making: P-value Method
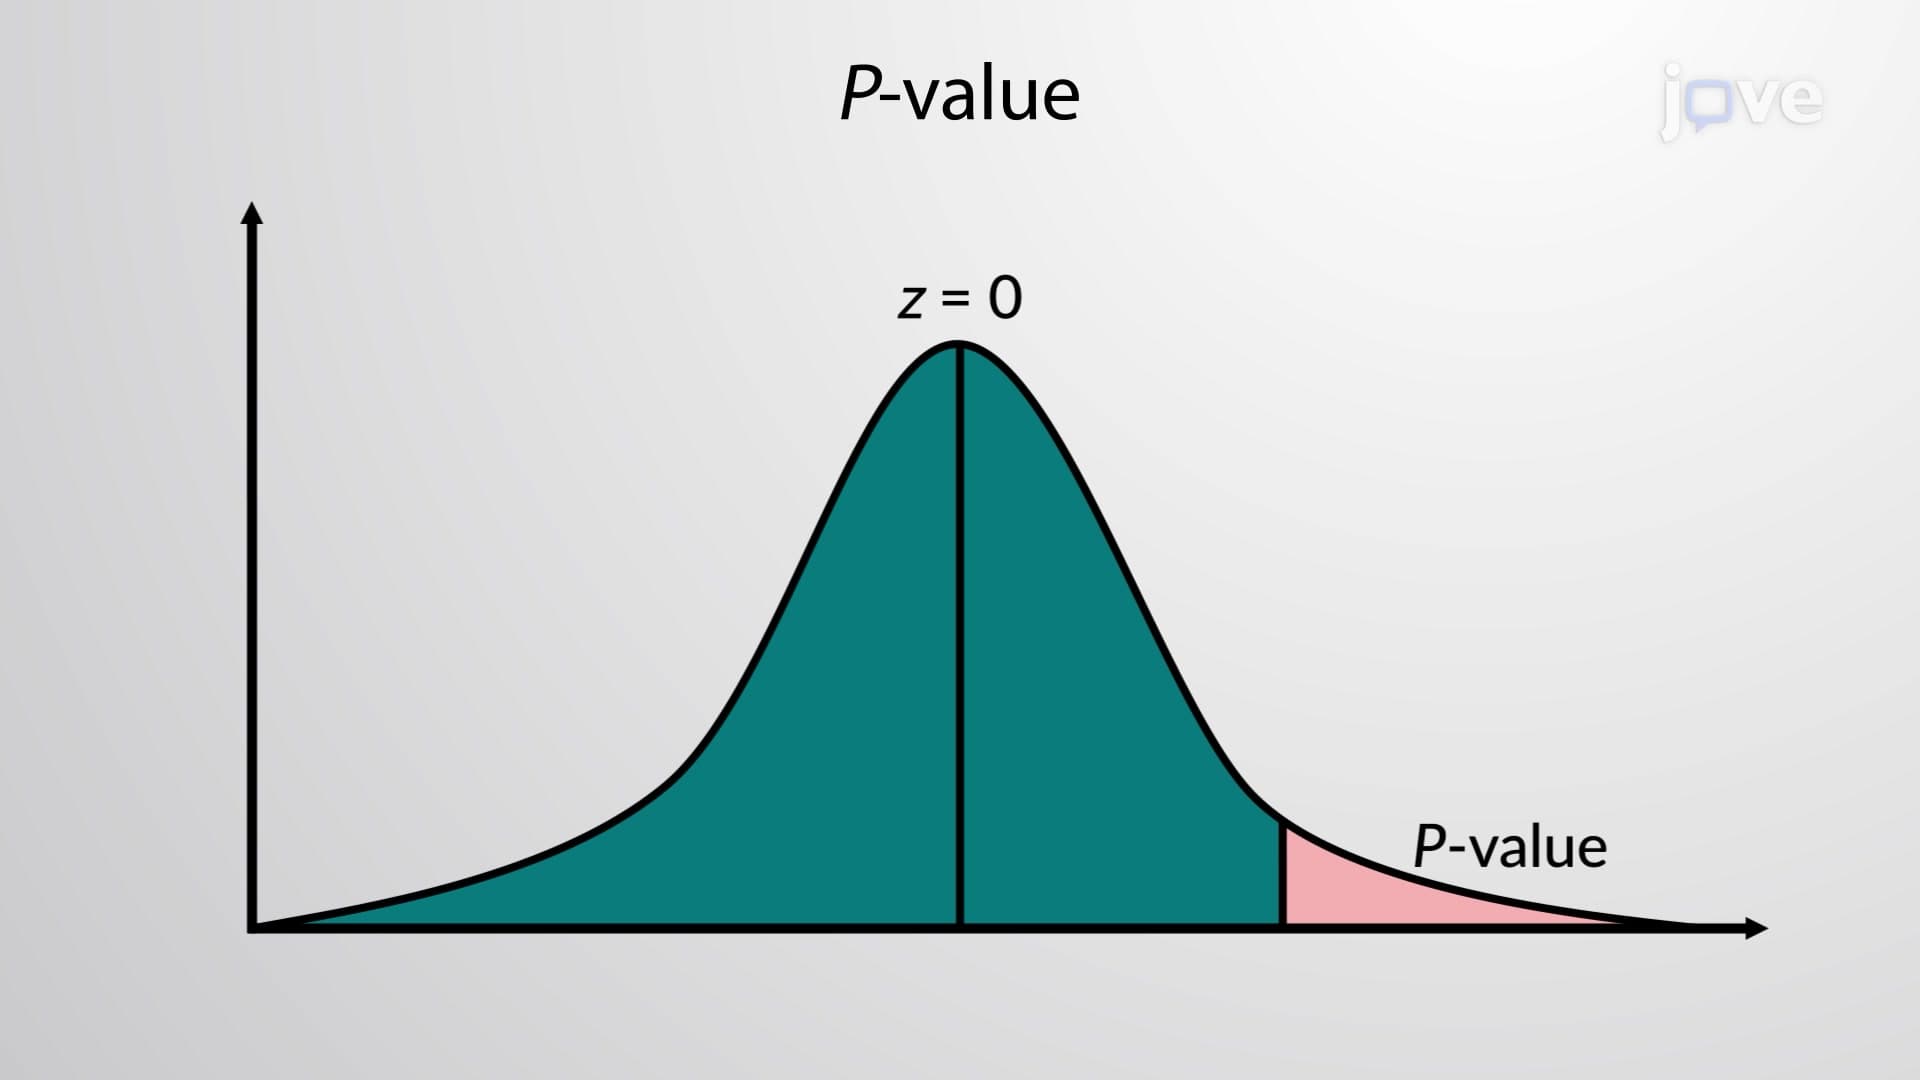
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can...
 01:29
Impression Management Techniques III: Aligning Actions
 01:06
Model Approaches for Pharmacokinetic Data: Distributed Parameter Models
The distributed parameter models are specifically designed to account for variations and differences in some drug classes. This model is particularly useful for assessing regional concentrations of anticancer or...