Related Experiment Video
Updated: Jan 4, 2026
Low-Cost Automated Flight Intercept Trap for the Temporal Sub-Sampling of Flying Insects Attracted to Artificial Light at Night
Published on: December 29, 2021
An Onboard Vision-Based System for Autonomous Landing of a Low-Cost Quadrotor on a Novel Landing Pad
Xuancen Liu1, Shifeng Zhang2, Jiayi Tian3
1College of Aerospace Science and Engineering, National University of Defense Technology, Chang Sha 410073, China. liuxuancen14@nudt.edu.cn.

Abstract:
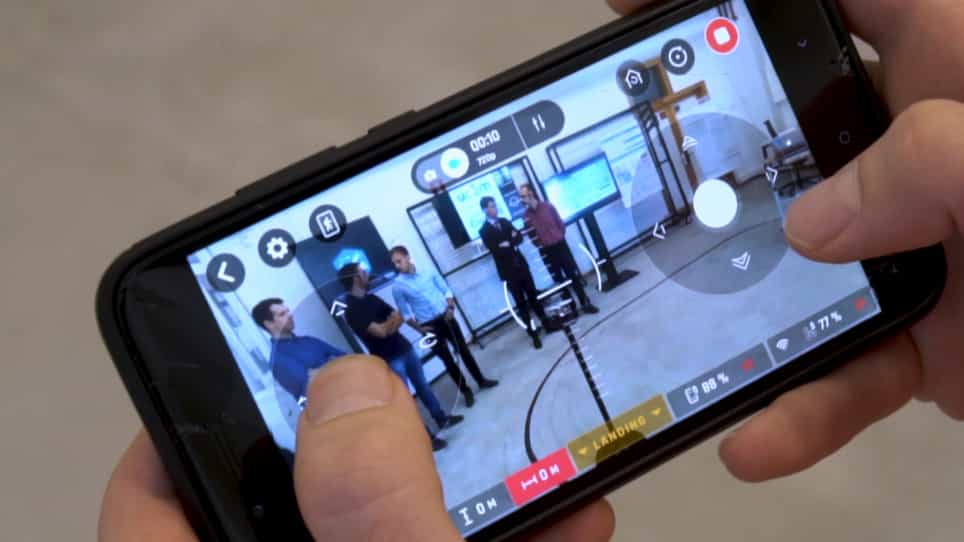
In this paper, an onboard vision-based system for the autonomous landing of a low-cost quadrotor is presented. A novel landing pad with different optical markers sizes is carefully designed to be robustly recognized at different distances. To provide reliable pose information in a GPS (Global Positioning System)-denied environment, a vision algorithm for real-time landing pad recognition and pose estimation is implemented. The dynamic model of the quadrotor is established and a system scheme for autonomous landing control is presented. A series of autonomous flights have been successfully performed, and a video of the experiment is available online. The efficiency and accuracy of the presented vision-based system is demonstrated by using its position and attitude estimates as control inputs for the autonomous landing of a self-customized quadrotor.
More Related Videos

Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:24
PI Controller: Design
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:02
Gyroscope
 01:11
Buoyancy and Stability for Submerged and Floating Bodies