Related Experiment Video
Updated: Jan 4, 2026


An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
ℓ1-gain filter design of discrete-time positive neural networks with mixed delays
Shunyuan Xiao1, Yijun Zhang1, Baoyong Zhang1
1School of Automation, Nanjing University of Science and Technology, Nanjing, 210094, PR China.

Abstract:
This paper mainly focuses on the filter design with ℓ1-gain disturbance attenuation performance for a class of discrete-time positive neural networks. Discrete and distributed time-varying delays occurring in neuron transmission are taken into account. Especially, the probabilistic distribution of distributed delays is described by a Bernoulli random process in the system model. First, criteria on the positiveness and the unique equilibrium of discrete-time neural networks are presented. Second, through linear Lyapunov method, sufficient conditions for globally asymptotic stability with ℓ1-gain disturbance attenuation performance of positive neural networks are proposed. Third, using the results obtained above, criteria on ℓ1-gain stability of the established filtering error system are presented, based on which a linear programming (LP) approach is put forward to design the desired positive filter. Finally, two examples of applications to water distribution network and genetic regulatory network are given to demonstrate the effectiveness and applicability of the derived results.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 05:19
Using Neuron Spiking Activity to Trigger Closed-Loop Stimuli in Neurophysiological Experiments
Published on: November 12, 2019
Related Concept Videos
 01:22
Phase-lead and Phase-lag Controllers
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:24
Convolution: Math, Graphics, and Discrete Signals
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:25
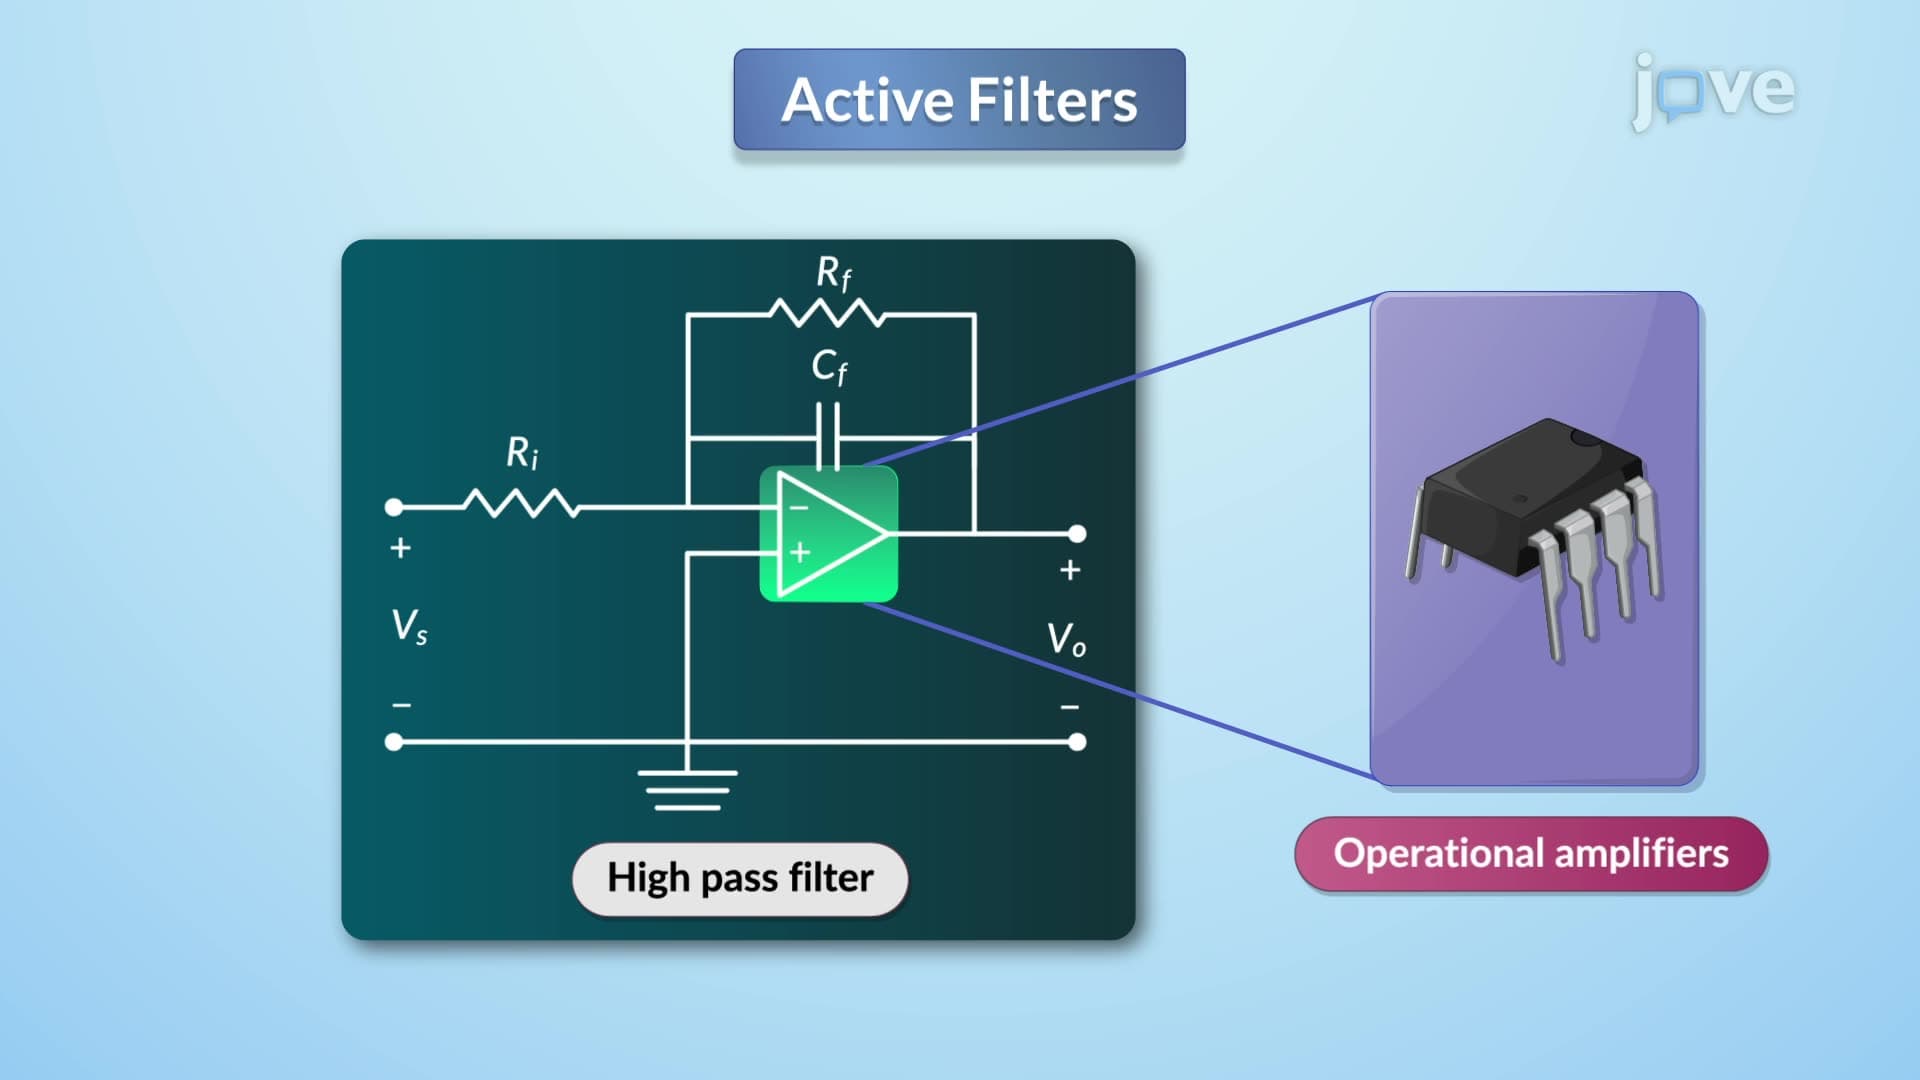
Active Filters
 01:22
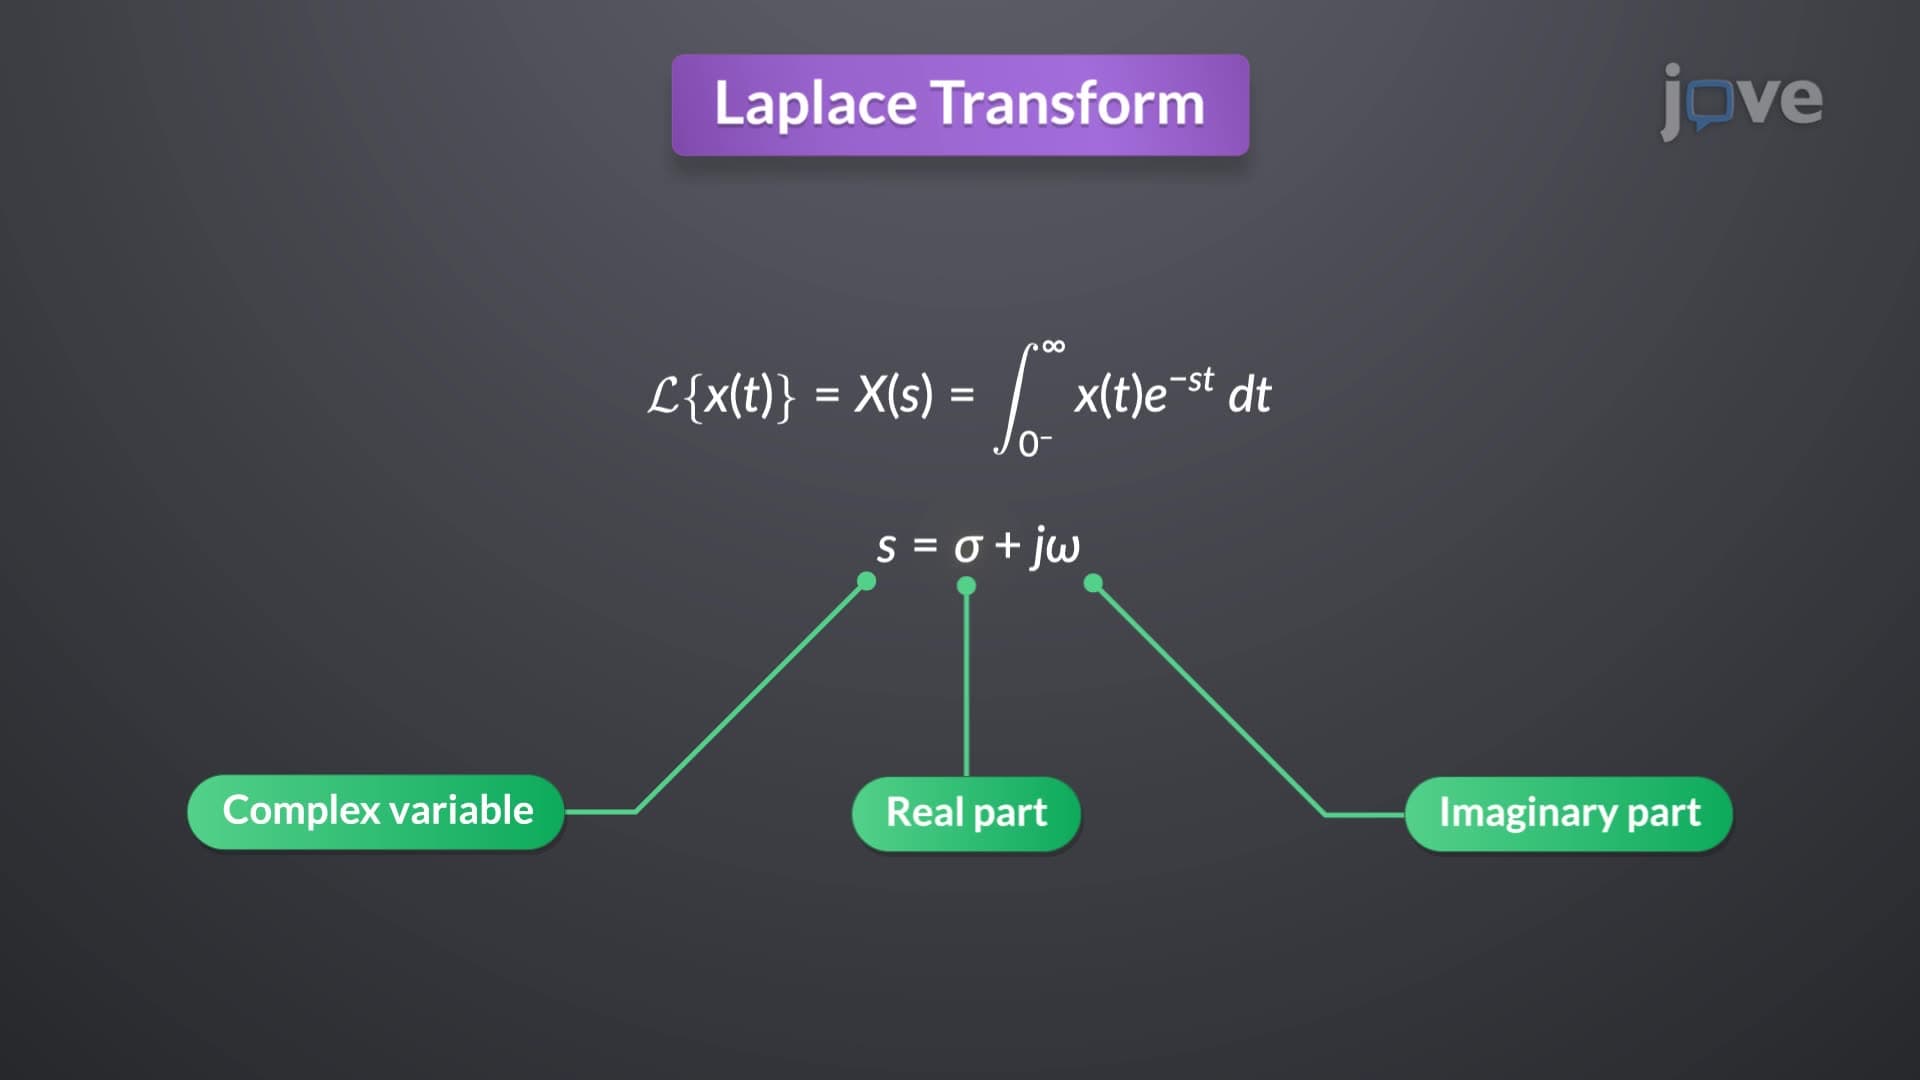
Definition of Laplace Transform