Related Experiment Video
Updated: Jan 4, 2026

Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Mechanoreception for Soft Robots via Intuitive Body Cues
Liangliang Wang1, Zheng Wang1,2
1Department of Mechanical Engineering, The University of Hong Kong, Hong Kong, China.

Abstract:
Mechanoreception, the ability of robots to detect mechanical stimuli from the internal and external environments, contributes significantly to improving safety and task performance during the operation of robots in unstructured environments. Various approaches have been proposed to endow robot systems with mechanoreception. In the case of soft robots, the state-of-the-art mechanosensory solutions typically embedded dedicated deformable sensors into the soft body, giving rise to fabrication complexity and signal sophistication. In this study, we propose a novel mechanoreception scheme to enable pneumatic-driven soft robots to perceive proprioceptive movements as well as external contacts. Both internal and external mechanical parameters can be decoded from intuitive cues of body deformation and pneumatic pressure signals. In contrast to most existing solutions employing dedicated deformable sensors, the proposed approach only utilizes pressure feedback, which is typically available from the pneumatic pressure sensors incorporated in the control loop of most pneumatic soft robots. The concept was implemented and validated on a proprietary robotic gripper with a linear soft pneumatic actuator, demonstrating the capability in simultaneous detection of actuator position and external contact forceAfter the proposed approach, the gripper can achieve both active and passive mechanosensation, with demonstrated experiments in grasping force estimation, contact loss detection, object stiffness identification, and contour measurements. This approach offers an alternative route to achieving excellent internal/environmental awareness without requiring dedicated sensing modalities.
Related Concept Videos
 01:33
Somatosensation
 01:27
Tactile and Chemical Senses
 01:26
Introduction to Special Senses
 01:16
Sensory Functions of the Skin
There are two main categories of receptors on the skin: capsulated and non-capsulated. The non-capsulated ones are mainly the pain receptors. The capsulated ones can be further categorized based on the...
 01:22
Mechanical Systems
 01:31
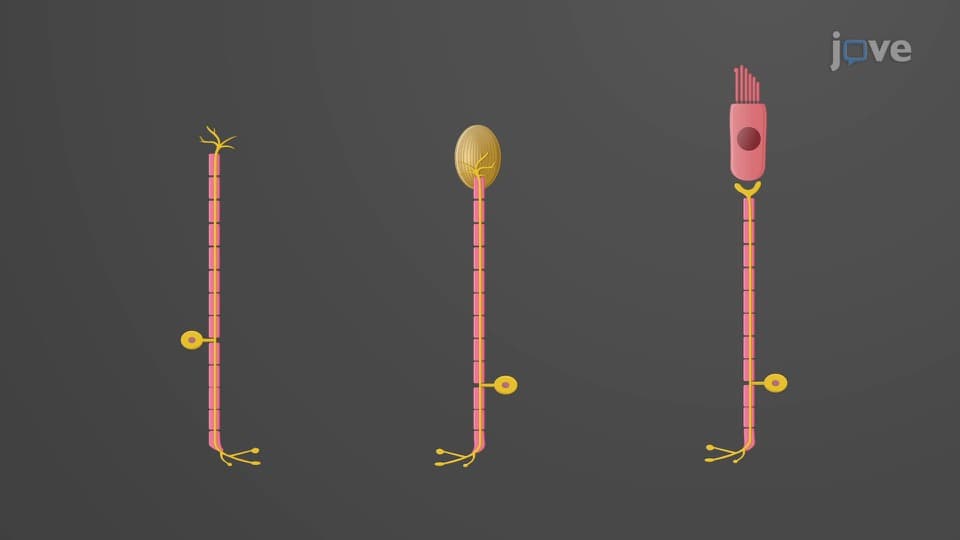
Introduction to Sensory Receptors
The first classification criterion is based on cell type, position, and function. Some receptor cells are neurons with free nerve endings, where their dendrites are embedded in the...