Related Experiment Video
Updated: Jan 3, 2026


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
A Multi-Sensor Based Roadheader Positioning Model and Arbitrary Tunnel Cross Section Automatic Cutting
Changqing Yan1, Wenxiao Zhao2, Xinming Lu3,4
1Department of Information Engineering, Shandong University of Science and Technology, Tai'an 271000, China.

Abstract:
Autonomous posture detection and self-localization of roadheaders is the key to automatic tunneling and roadheader robotization. In this paper, a multi-sensor based positioning method, involving an inertial system for altitude angles measurement, total station for coordinate measurement, and sensors for measuring the real-time length of the hydraulic cylinder is presented for roadheader position measurement and posture detection. Based on this method, a positioning model for roadheader and cutter positioning is developed. Additionally, flexible trajectory planning methods are provided for automatic cutting. Based on the positioning model and the trajectory planning methods, an automatic cutting procedure is proposed and applied in practical tunneling. The experimental results verify the high accuracy and efficiency of both the positioning method and the model. Furthermore, it is indicated that arbitrary shapes can be generated automatically and precisely according to the planned trajectory, employing the automatic cutting procedure. Therefore, unmanned tunneling can be realized by employing the proposed automatic cutting process.
Related Concept Videos
 01:17
Design Example: Alignment of a Road Line Using GIS
 01:26
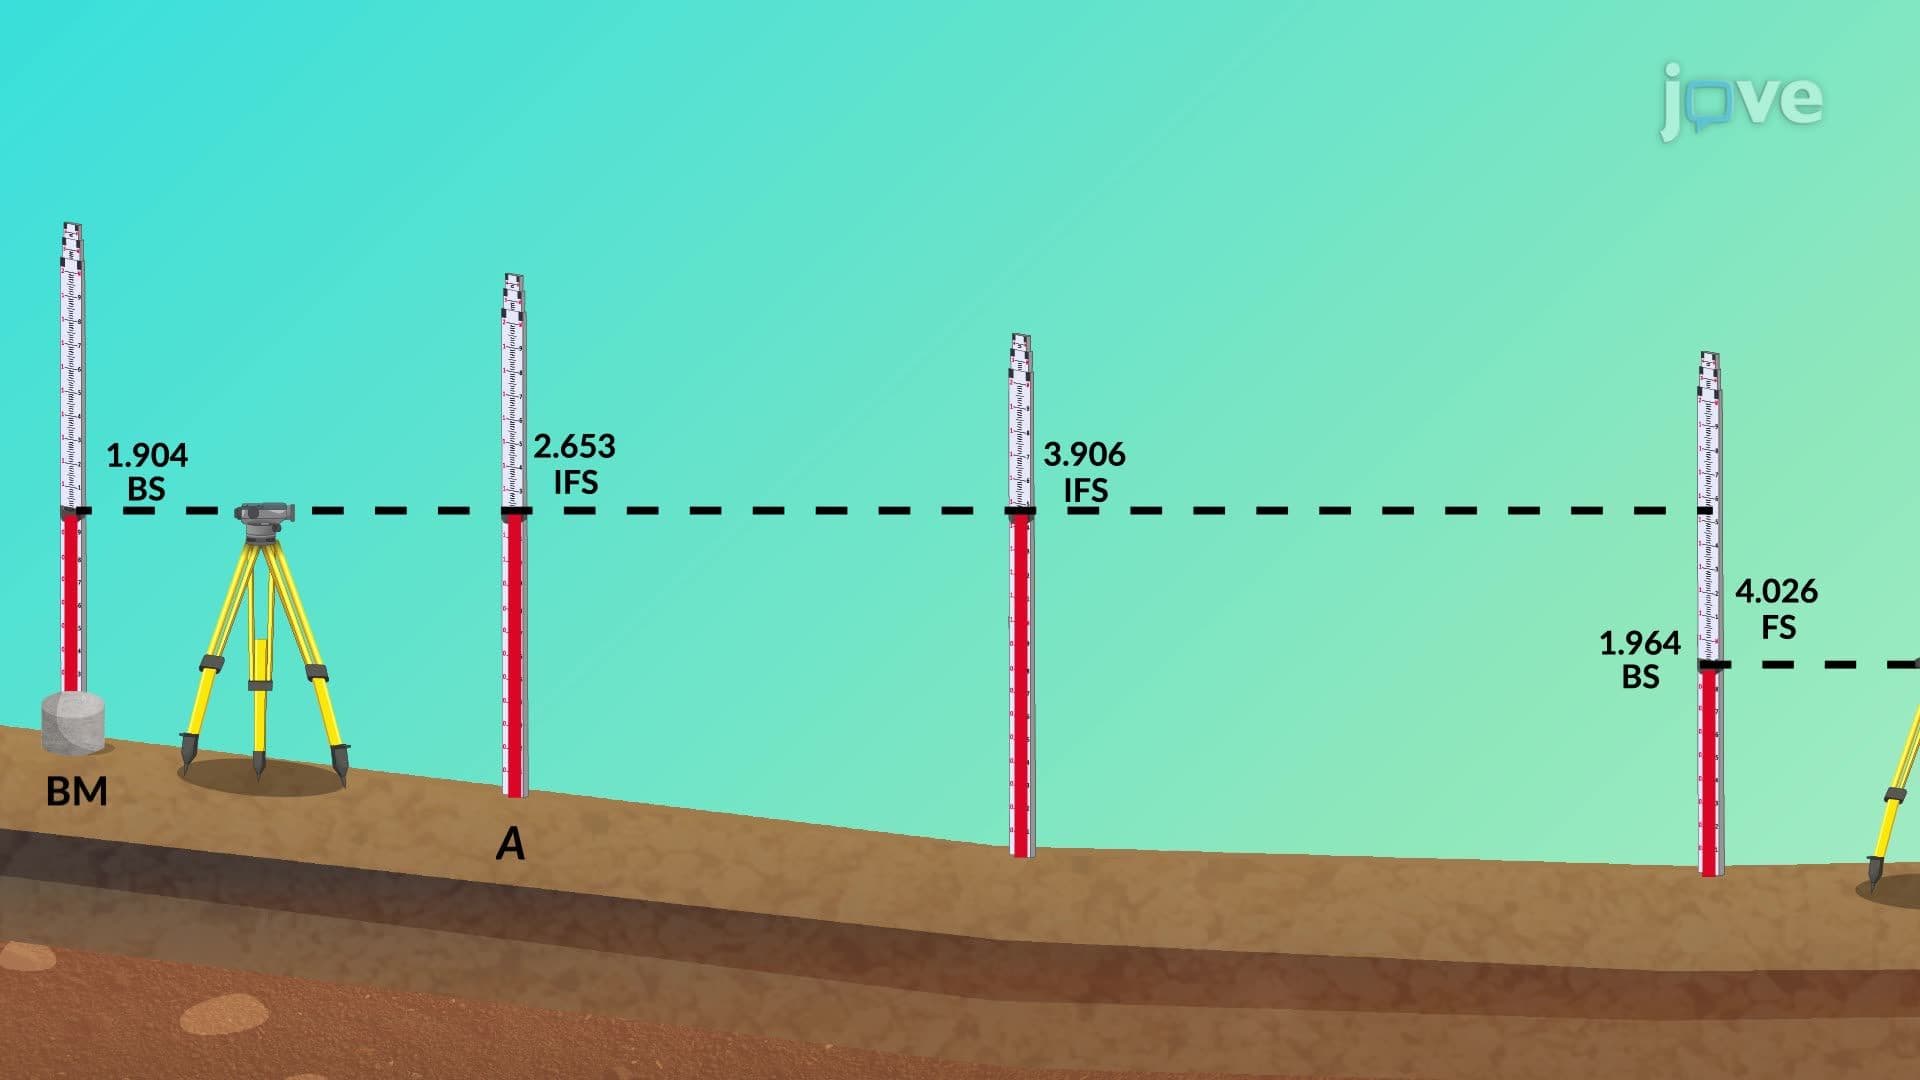
Profile Leveling and Cross Sections