Related Experiment Video
Updated: Jan 3, 2026


Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
Globally Exponentially Stable Tracking Control of Self-Restructuring Nonlinear Systems

Abstract:
This article proposes a neural networks (NNs)-based tracking control approach for a class of uncertain high-order self-restructuring nonaffine dynamic systems. Unlike most existing NN-based works that normally ignore the precondition on the functionality and reliability of NN unit and thus can only ensure semiglobal stability, the proposed method explicitly addresses the issue of reliable in-loop operation of NN approximation-based control unit, resulting in a safeguarded NN-based control solution capable of ensuring globally stable tracking. Furthermore, the control method proposed guarantees exponentially globally stable tracking for systems with self-restructuring nonlinearities and uncertainties, distinguishing itself from those that only yield uniformly ultimately bounded (UUB) regulation/tracking results for nonlinear systems with fixed structures. All of these features are achieved by the proposed strategy consisting of two cooperative control units: 1) safeguard control and 2) NN-based control. The role of the safeguard control is to force the states (starting from any initial condition) to enter a stable region, so that the NN-based control can be activated trustworthily and safely. It is such cooperation of the two units that not only ensures the tracking error entering the stable region first within a prespecified finite time but also guarantees the tracking error converging to zero exponentially thereafter, resulting in global zero-error tracking. Both the theoretical analysis and numerical simulation authenticate the effectiveness of the proposed method.
More Related Videos
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:28
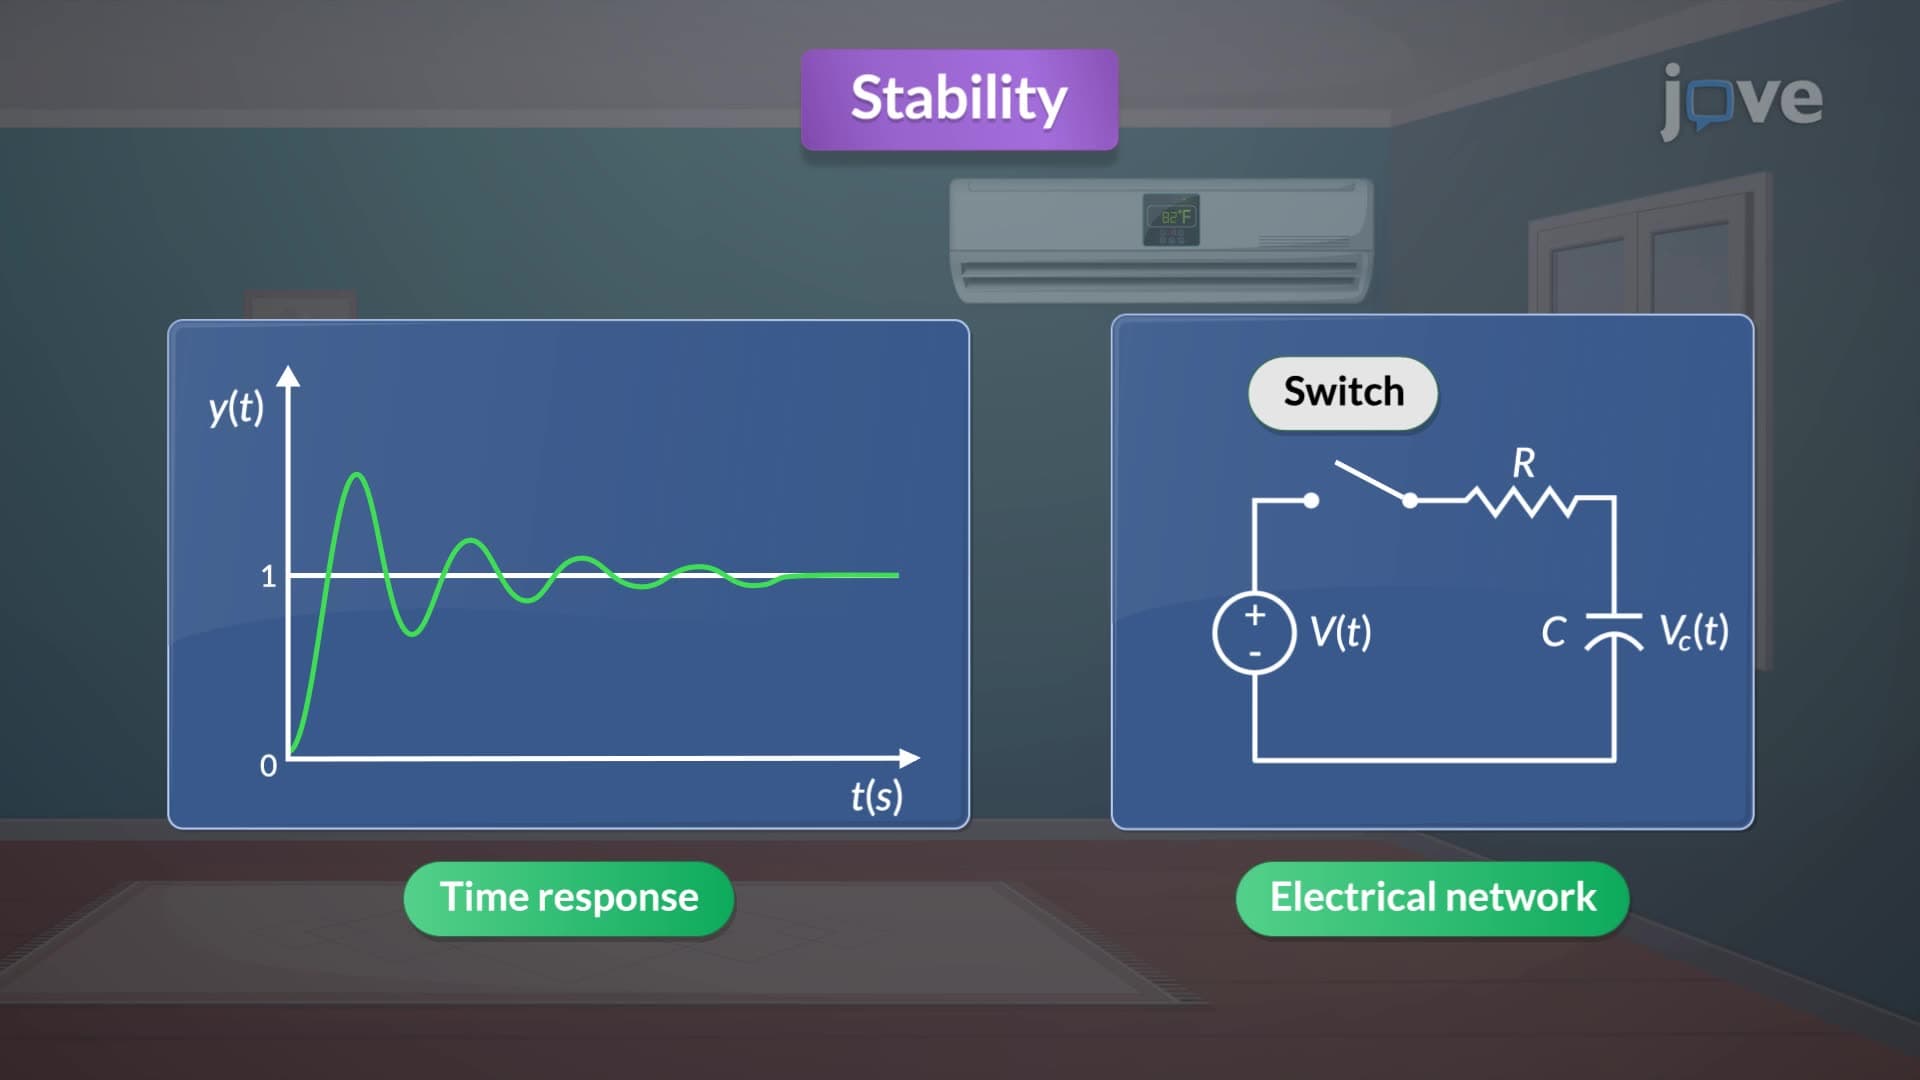
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:10
Control Systems
At the heart...