Related Experiment Video
Updated: Jan 2, 2026

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
A Clamping Force Estimation Method Based on a Joint Torque Disturbance Observer Using PSO-BPNN for Cable-Driven
Zhengyu Wang1,2, Daoming Wang1, Bing Chen1
1School of Mechanical Engineering, Hefei University of Technology, Hefei 230009, China.

Abstract:
The ability to sense external force is an important technique for force feedback, haptics and safe interaction control in minimally-invasive surgical robots (MISRs). Moreover, this ability plays a significant role in the restricting refined surgical operations. The wrist joints of surgical robot end-effectors are usually actuated by several long-distance wire cables. Its two forceps are each actuated by two cables. The scope of force sensing includes multidimensional external force and one-dimensional clamping force. This paper focuses on one-dimensional clamping force sensing method that do not require any internal force sensor integrated in the end-effector's forceps. A new clamping force estimation method is proposed based on a joint torque disturbance observer (JTDO) for a cable-driven surgical robot end-effector. The JTDO essentially considers the variations in cable tension between the actual cable tension and the estimated cable tension using a Particle Swarm Optimization Back Propagation Neural Network (PSO-BPNN) under free motion. Furthermore, a clamping force estimator is proposed based on the forceps' JTDO and their mechanical relations. According to comparative analyses in experimental studies, the detection resolutions of collision force and clamping force were 0.11 N. The experimental results verify the feasibility and effectiveness of the proposed clamping force sensing method.

Related Concept Videos
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:15
Torque Free Motion
 01:30
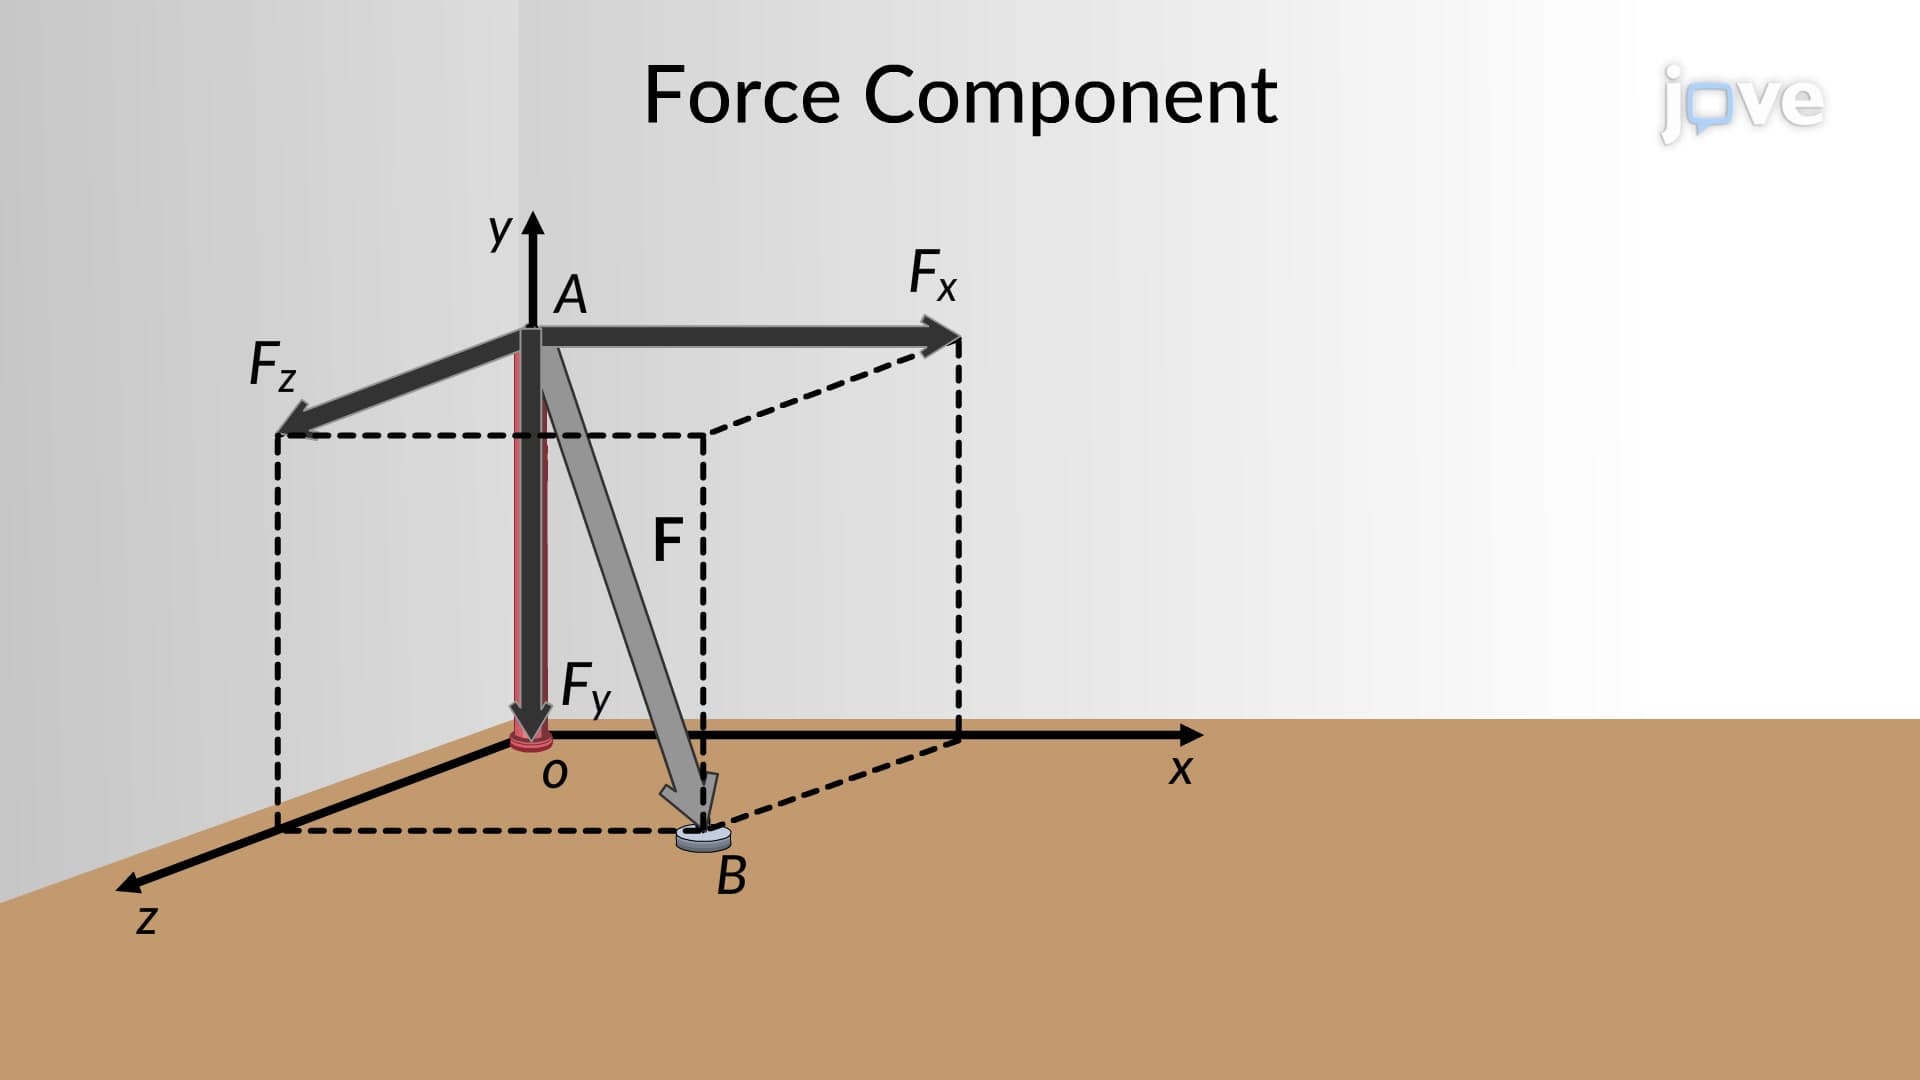
Principle of Moments: Problem Solving
One such scenario involves a pole placed in a three-dimensional system with a cable attached. When a tension is applied to the cable, the moment about the z-axis passing through...
 01:19
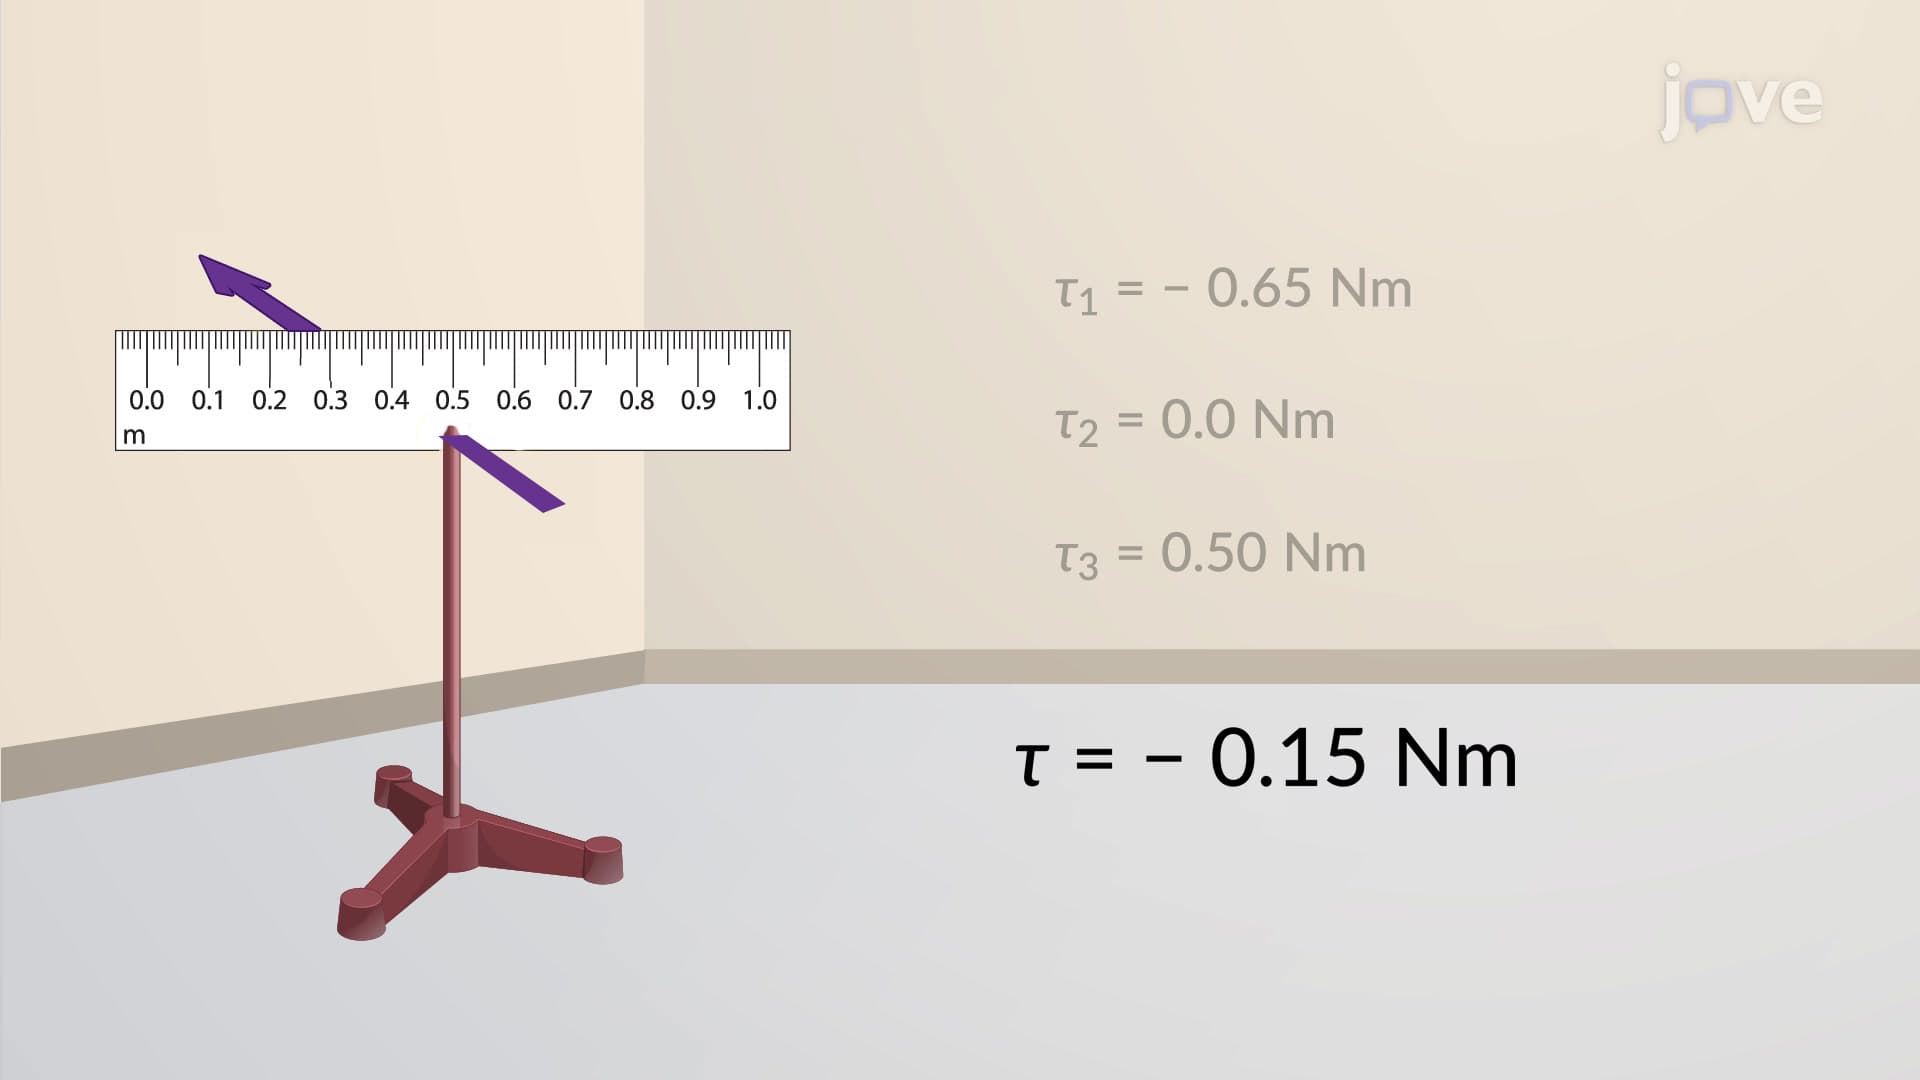
Net Torque Calculations
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Three-Dimensional Force System