Related Experiment Video
Updated: Jan 2, 2026
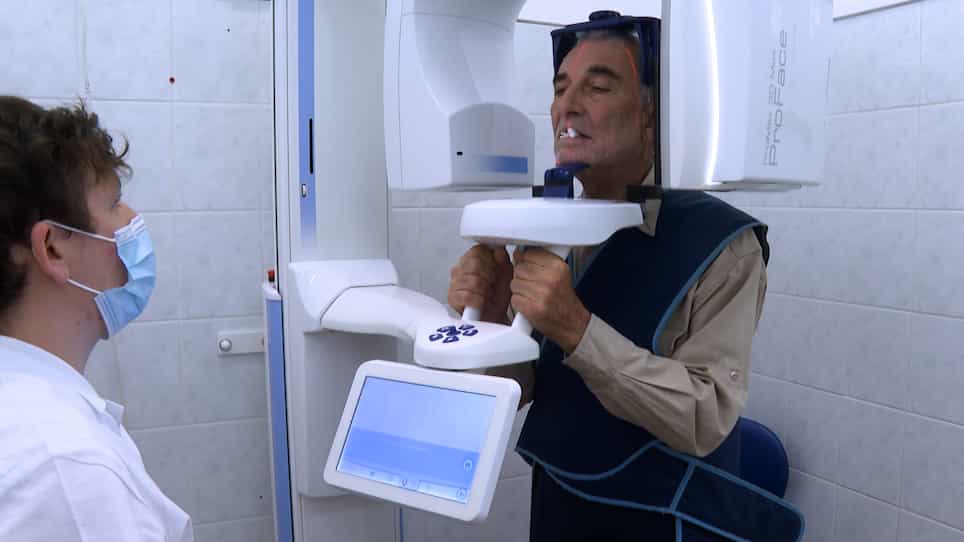

Dynamic Navigation for Dental Implant Placement
Published on: September 13, 2022
Accuracy of dental implant placement via dynamic navigation or the freehand method: A split-mouth randomized
Ceyda Aktolun Aydemir1, Volkan Arısan1
1Department of Oral Implantology, Faculty of Dentistry, Istanbul University, Istanbul, Turkey.

Objectives:
The aim of this split-mouth randomized controlled clinical trial was to compare the deviations of planned and placed implants placed by the assistance of a micron tracker-based dynamic navigation device or freehand methods.
Material And Methods:
A thermoplastic fiducial marker was adapted on the anterior teeth, and cone-beam computerized tomography was used for imaging. A minimum of one implant was planned for each side of the posterior maxilla, and the dynamic navigation device or freehand method was randomly used for surgical insertion. Deviations were measured by matching the planning data with a final CBCT image. Linear deviations (mm) between the planned and placed implants were the primary outcome. The results were analysed by generalized linear mixed models (p < .05). (NCT03471208).
Results:
A total of 92 implants were placed to 32 volunteers, and 86 implants were included in the final analysis. For the linear deviations, mean of differences (Δ) was 0.72mm (Standard deviation (SD): 0.26); (95% Confidence interval (CI): 0.39-1.02) in the shoulder of the implants (p < .001) and 0.69mm (SD: 0.36); (95% CI: 0.19-1.19) in the tip of the implants (p < .001). For the angular deviations, Δ was 5.33° (SD: 1.63); (95% CI: 7.17-3.48); (p < .001).
Conclusions:
The navigation technique can be used to transfer virtual implant planning to the patient's jaw with increased accuracy.
More Related Videos
 05:54
Real-Time Dynamic Navigation System for the Precise Quad-Zygomatic Implant Placement in a Patient with a Severely Atrophic Maxilla
Published on: October 18, 2021
 07:03
Dynamic Navigation in Endodontics: Guided Access Cavity Preparation by Means of a Miniaturized Navigation System
Published on: May 5, 2022