Robust control of a silicone soft robot using neural networks
Related Experiment Video
Updated: Jan 1, 2026
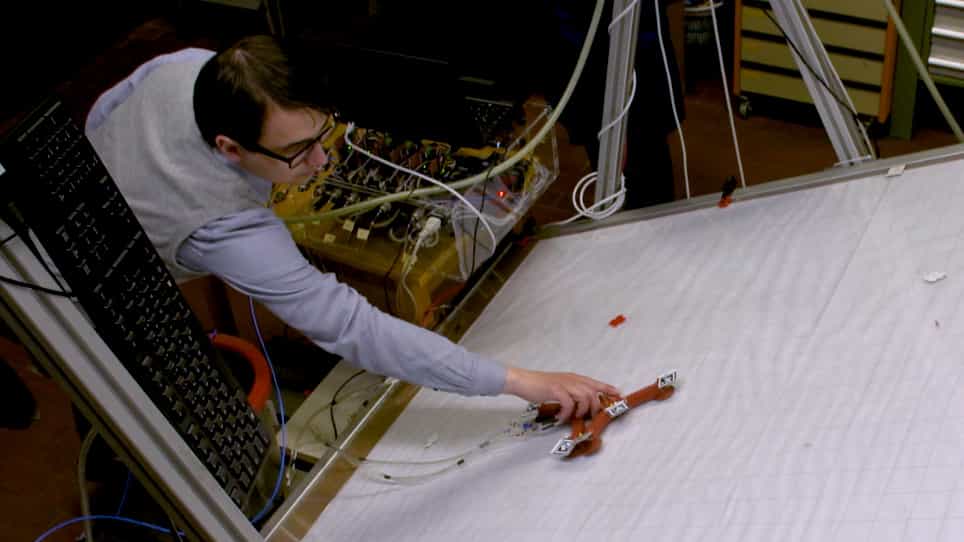
Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Gang Zheng1, Yuan Zhou2, Mingda Ju3
1School of Mathematics and Big Data, Foshan University, Foshan 528000, China; Inria Lille, 40 Avenue Halley, 59650, Villeneuve d'Ascq, France.

Abstract:
This paper deals with the robust controller design problem to regulate the position of a soft robot with elastic behavior, driven by 4 cable actuators. In this work, we first used an artificial neural network to approximate the relation between these actuators and the controlled position of the soft robot, based on which two types of robust controllers (type of integral and sliding mode) are proposed. The effectiveness and the robustness of the proposed controllers have been analyzed both for the constant and the time-varying disturbances. The performances (precision, convergence speed and robustness) of the proposed method have been validated via different experimental tests.
Related Concept Videos
 01:37
Neural Regulation
 01:18
Neural Control of Respiration
Respiratory Centers in the Brainstem
Two primary areas comprise the respiratory center: the medullary respiratory center in the medulla oblongata and the pontine respiratory group in the pons. The...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:25
Neural Circuits
Neuronal pools are collections of nerve cells with similar functions and interact through chemical and electrical signals. These pools include both interneurons (the central neural circuit nodes that...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...