Related Experiment Video
Updated: Dec 31, 2025
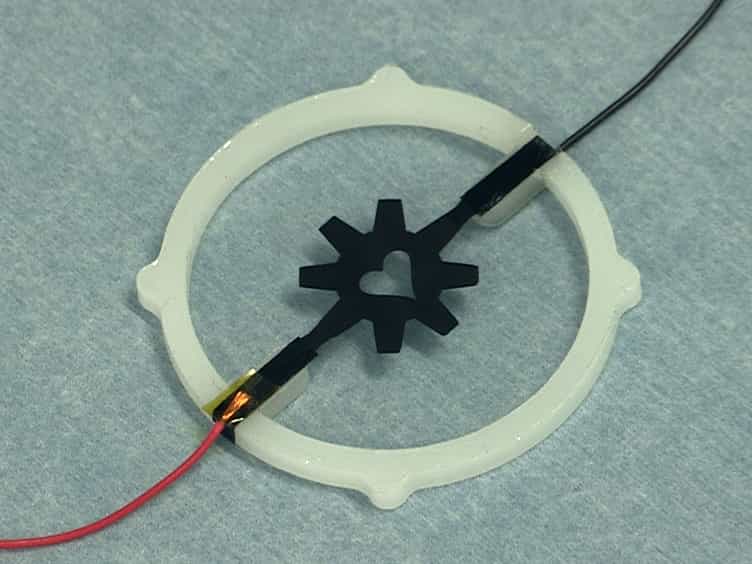

Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
A Wearable Soft Haptic Communicator Based on Dielectric Elastomer Actuators
Huichan Zhao1,2,3, Aftab M Hussain1,4, Ali Israr5
1School of Engineering and Applied Sciences, Harvard University, Cambridge, Massachusetts.

Abstract:
Dielectric elastomer actuators exhibit an unusual combination of large displacements, moderate bandwidth, low power consumption, and mechanical impedance comparable with human skin, making them attractive for haptic devices. In this article, we propose a wearable haptic communication device based on a two-by-two array of dielectric elastomer linear actuators. We briefly describe the architecture of the actuators and their mechanical and electrical integration into a wearable armband. We then characterize the actuators' force, displacement, and thermal properties in a bench-top configuration. We also report on the power and drive circuit design. Finally, we perform a set of preliminary perception evaluations on participants using our haptic device, including detection threshold tests and identification tests for locations and directions on the forearm. Human testing with individual actuators demonstrates that the broadband actuation can be easily perceived on the forearm, providing the basis for both the development of a wearable actuator array and its use in more extensive perception evaluation as described herein.
Related Concept Videos
 01:14
Design Example: Resistive Touchscreen
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...
 01:18
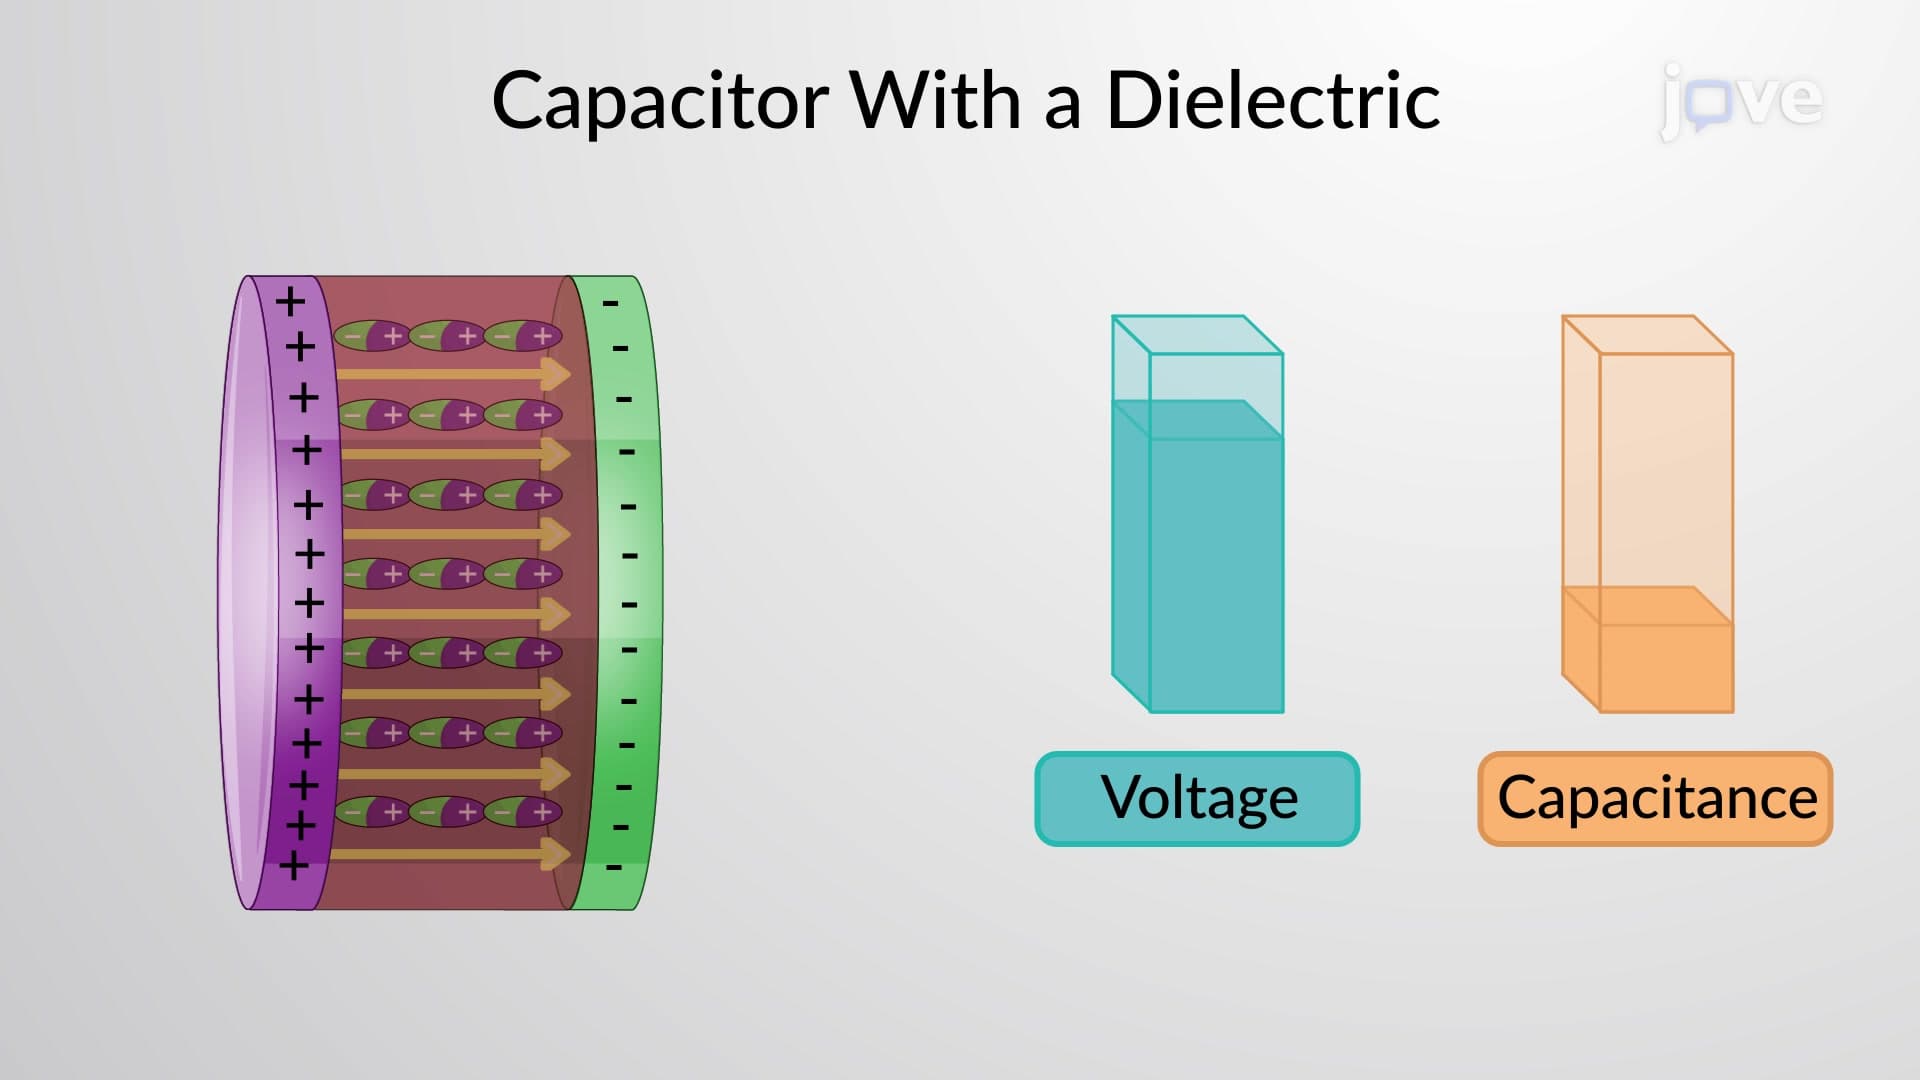
Capacitor With A Dielectric
Dielectrics are non-conducting materials with no free or loosely bound electrons. When a dielectric is...