Related Experiment Video
Updated: Dec 29, 2025

Cone Beam Intraoperative Computed Tomography-based Image Guidance for Minimally Invasive Transforaminal Interbody Fusion
Published on: August 6, 2019
Robot-Assisted versus Freehand Instrumentation in Short-Segment Lumbar Fusion: Experience with Real-Time Image-Guided
Bowen Jiang1, Zach Pennington1, Tej Azad1
1Department of Neurosurgery, Johns Hopkins School of Medicine, Baltimore, Maryland, USA.

Objective:
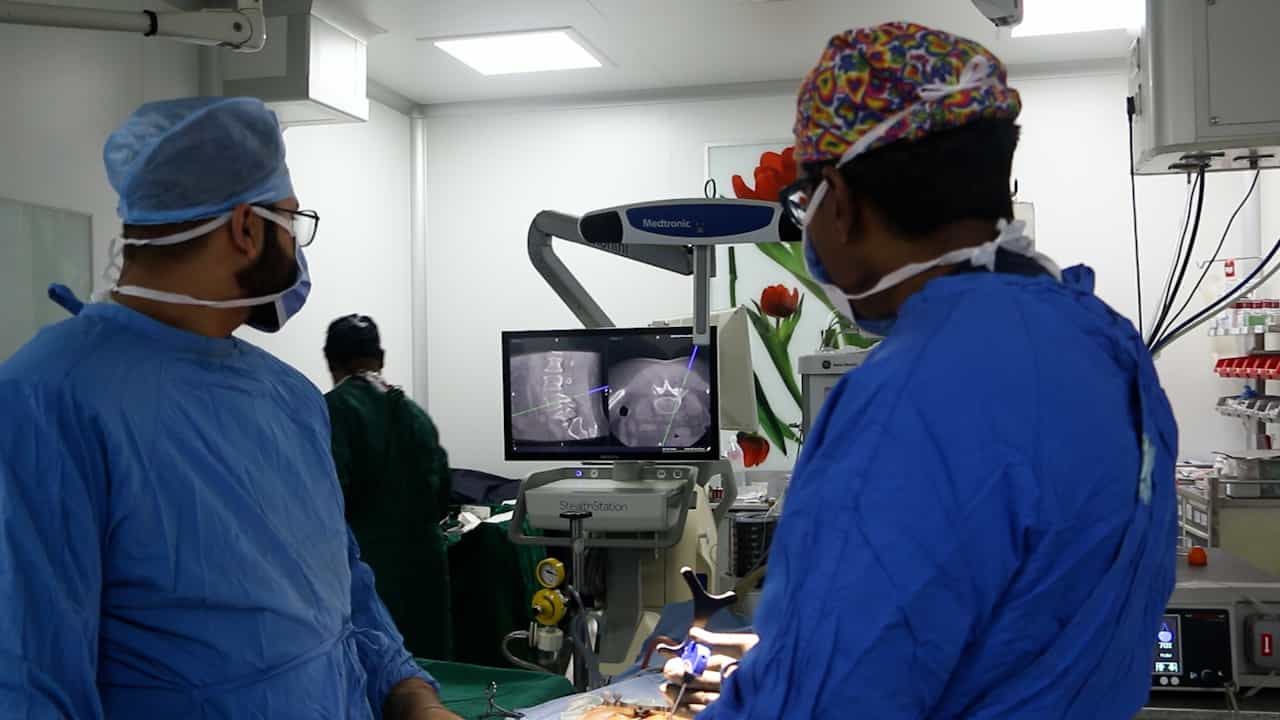
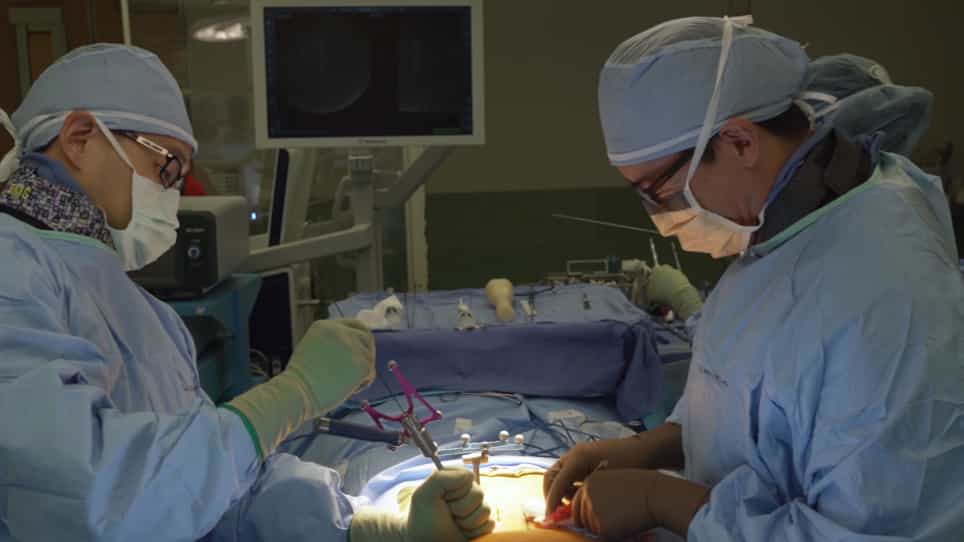
Increasing patient demand for minimally invasive surgery and increased payer emphasis on quality-based payment schema have created a need for technologies that provide consistent, high-quality outcomes for patients undergoing spine surgery. Robotic assistance is one such technology. We report our early experience with a novel real-time, image-guided robot system for use in short-segment lumbar fusion in patients diagnosed with degenerative disease.
Methods:
A consecutive series of patients undergoing robot-assisted 1-level or 2-level lumbar fusion procedures were compared with matched controls who underwent freehand surgery. Screw accuracy, intraoperative outcomes, and 30-day outcomes were compared.
Results:
We identified 56 patients who underwent 1-level or 2-level lumbar fusion during the study period: 28 who underwent robot-assisted procedures and 28 matched controls who underwent freehand instrumentation placement. No significant differences were found between the robot-assisted surgery cohort and the freehand surgery cohort with respect to matched variables. Patients who underwent robot-assisted surgery had less intraoperative blood loss (266.1 ± 236.8 mL vs. 598.8 ± 360.2 mL; P < 0.001) and shorter hospitalizations (3.5 ± 1.8 days vs. 4.5 ± 2.0 days; P = 0.01). No differences were noted in complication rates, 30-day outcomes, or screw accuracy. Profiling of our initial series showed an average reduction in operation duration of 4.6 minutes with each additional case.
Conclusions:
Patients undergoing robot-assisted fusion experienced less intraoperative blood loss and shorter hospitalizations. The results of this initial experience suggest that an image-guided robotic system may provide similar short-term outcomes compared with freehand instrumentation placement.