Related Experiment Video
Updated: Dec 29, 2025
Fabrication of Soft Pneumatic Network Actuators with Oblique Chambers
Published on: August 17, 2018
Rolling Locomotion of Cable-Driven Soft Spherical Tensegrity Robots
Kyunam Kim1, Adrian K Agogino2, Alice M Agogino3
1Department of Aerospace, California Institute of Technology, Pasadena, California.

Abstract:
Soft spherical tensegrity robots are novel steerable mobile robotic platforms that are compliant, lightweight, and robust. The geometry of these robots is suitable for rolling locomotion, and they achieve this motion by properly deforming their structures using carefully chosen actuation strategies. The objective of this work is to consolidate and add to our research to date on methods for realizing rolling locomotion of spherical tensegrity robots. To predict the deformation of tensegrity structures when their member forces are varied, we introduce a modified version of the dynamic relaxation technique and apply it to our tensegrity robots. In addition, we present two techniques to find desirable deformations and actuation strategies that would result in robust rolling locomotion of the robots. The first one relies on the greedy search that can quickly find solutions, and the second one uses a multigeneration Monte Carlo method that can find suboptimal solutions with a higher quality. The methods are illustrated and validated both in simulation and with our hardware robots, which show that our methods are viable means of realizing robust and steerable rolling locomotion of spherical tensegrity robots.


Related Concept Videos
 01:24
Cable Subjected to a Distributed Load
 01:13
Cable Subjected to Its Own Weight
A generalized loading function is employed to analyze a cable subjected to its own weight. This function considers the force acting along the cable's arc length rather than its projected length, providing a more accurate...
 01:09
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:15
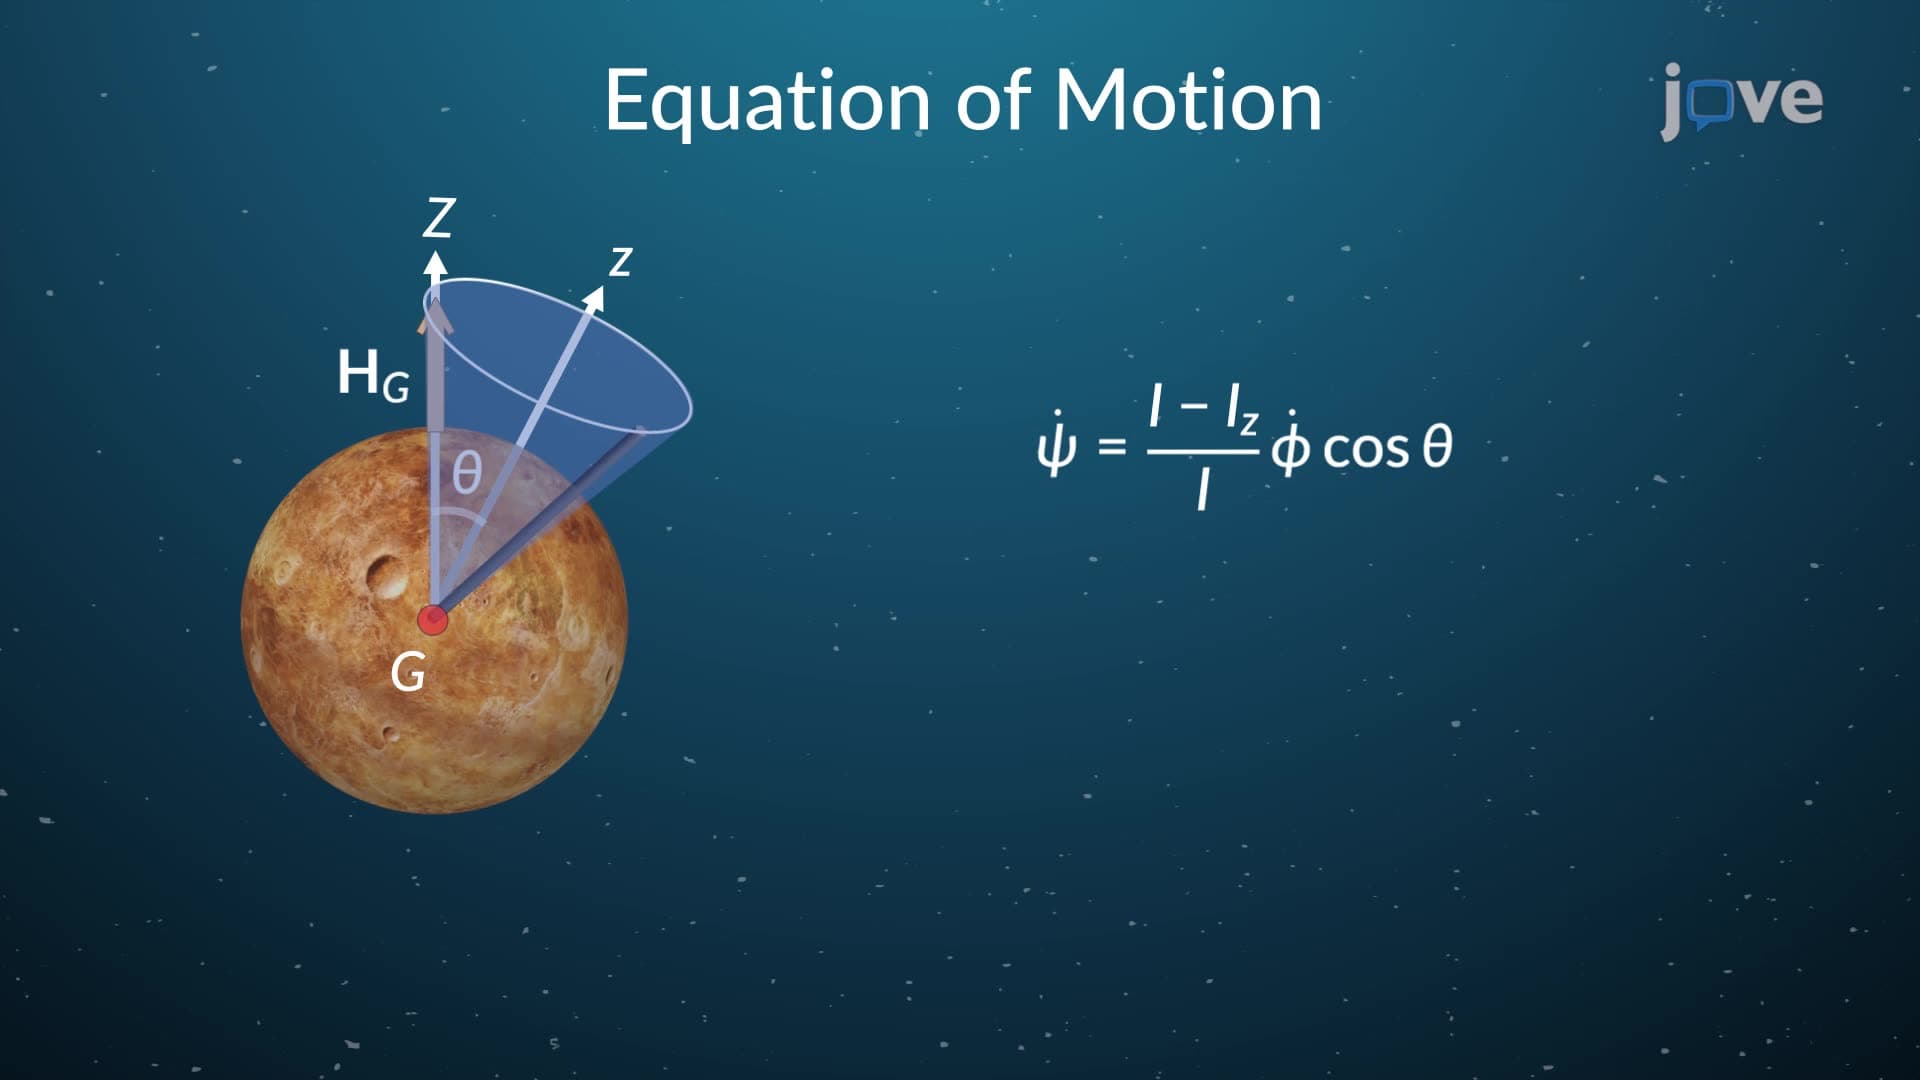
Torque Free Motion
 01:20
Plastic Deformation in Circular Shafts
 01:28
Cable Subjected to Concentrated Loads