Related Experiment Video
Updated: Dec 28, 2025

Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
Existence and stability of limit cycles in the model of a planar passive biped walking down a slope
1Department of Mathematical Sciences, The University of Texas at Dallas, 800 West Campbell Road, Richardson, TX 75080, USA.

Abstract:
We consider the simplest model of a passive biped walking down a slope given by the equations of switched coupled pendula (McGeer T. 1990 Passive dynamic walking. Int. J. Robot. Res. 9, 62-82. (doi:10.1177/027836499000900206)). Following the fundamental work by Garcia (Garcia et al. 1998 J. Biomech. Eng. 120, 281. (doi:10.1115/1.2798313)), we view the slope of the ground as a small parameter γ ≥ 0. When γ = 0, the system can be solved in closed form and the existence of a family of cycles (i.e. potential walking cycles) can be computed in closed form. As observed in Garcia et al. (Garcia et al. 1998 J. Biomech. Eng. 120, 281. (doi:10.1115/1.2798313)), the family of cycles disappears when γ increases and only isolated asymptotically stable cycles (walking cycles) persist. However, no mathematically complete proofs of the existence and stability of walking cycles have been reported in the literature to date. The present paper proves the existence and stability of a walking cycle (long-period gait cycle, as termed by McGeer) by using the methods of perturbation theory for maps. In particular, we derive a perturbation theorem for the occurrence of stable fixed points from 1-parameter families in two-dimensional maps that can be of independent interest in applied sciences.


Related Concept Videos
 01:10
Energy Diagrams - II
The point in the energy diagram at which the system’s potential energy is the lowest is known as the local minima. The system tends to stay in this position indefinitely unless acted upon by a net force. The slope of the potential energy diagram at the local minima is zero, indicating that zero net force is acting on the system. The...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:28
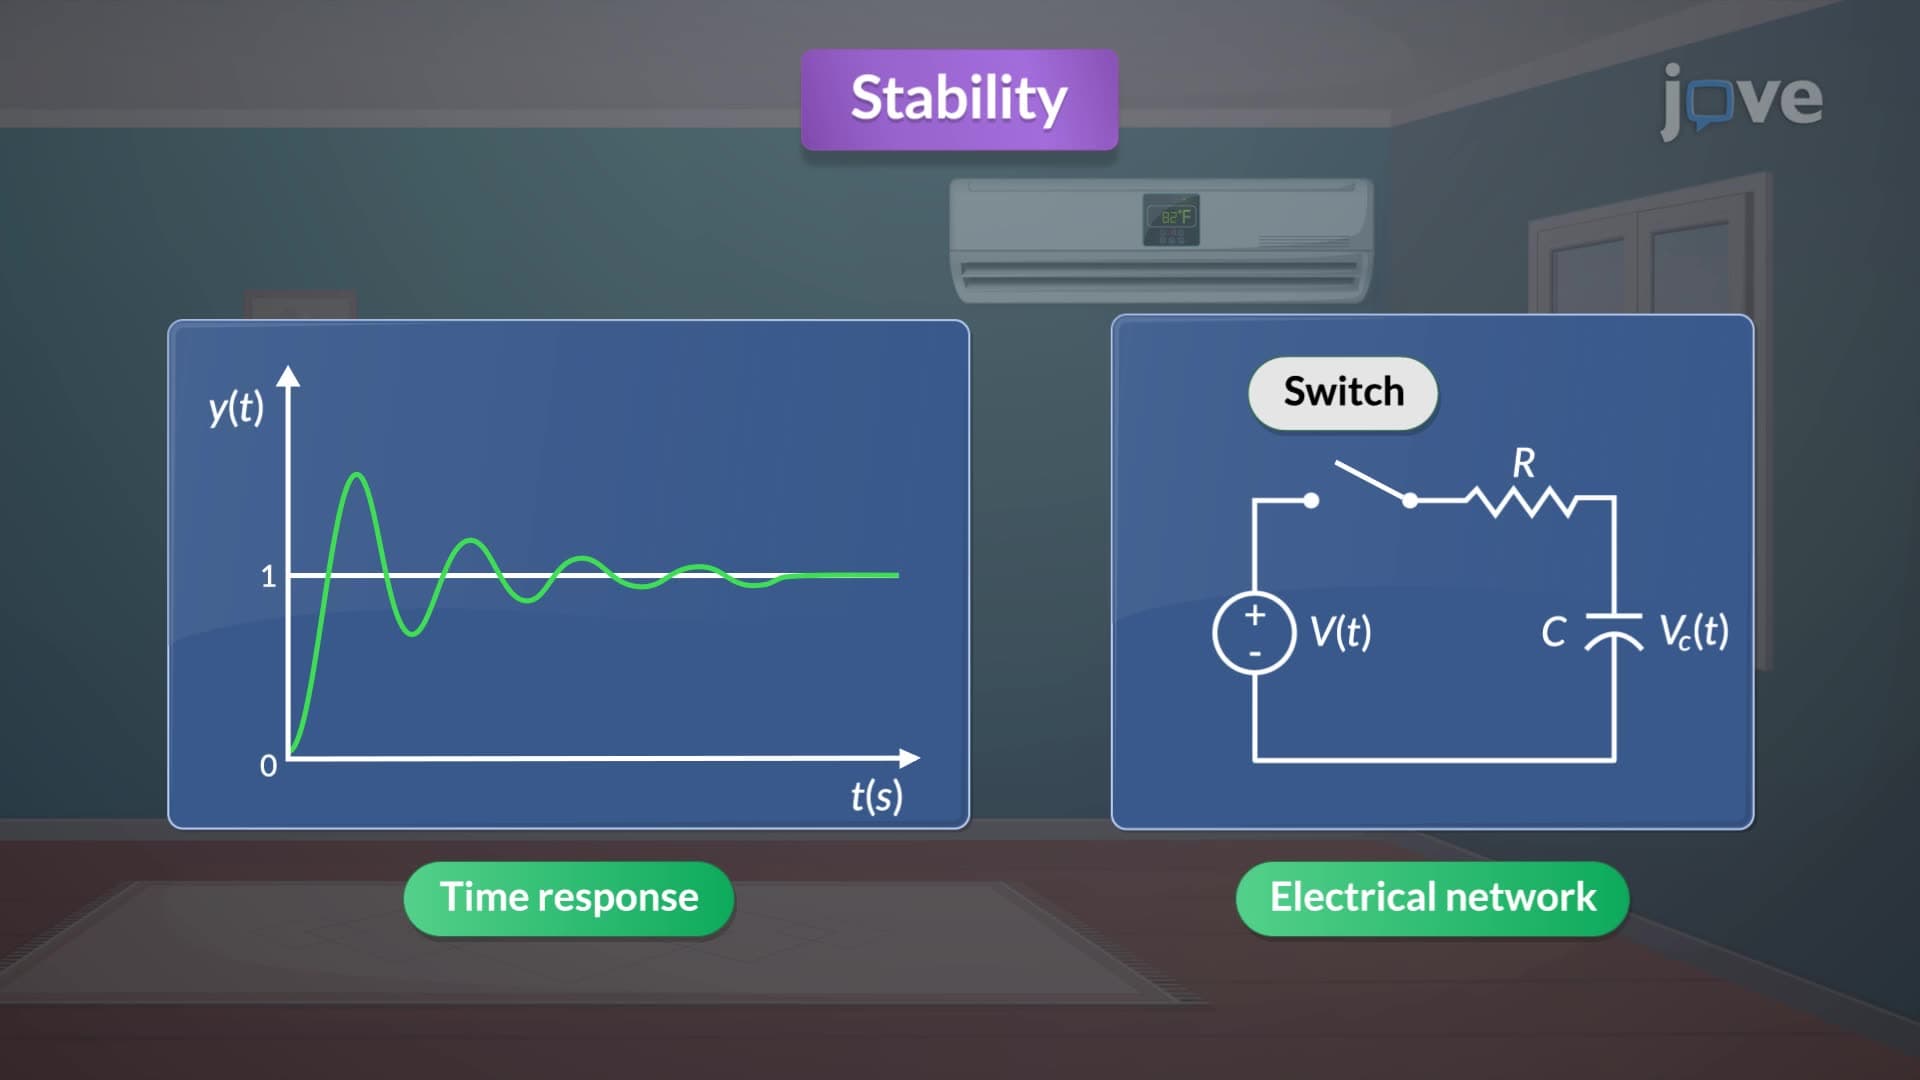
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:19
Limits with Oscillating Discontinuities
 01:13
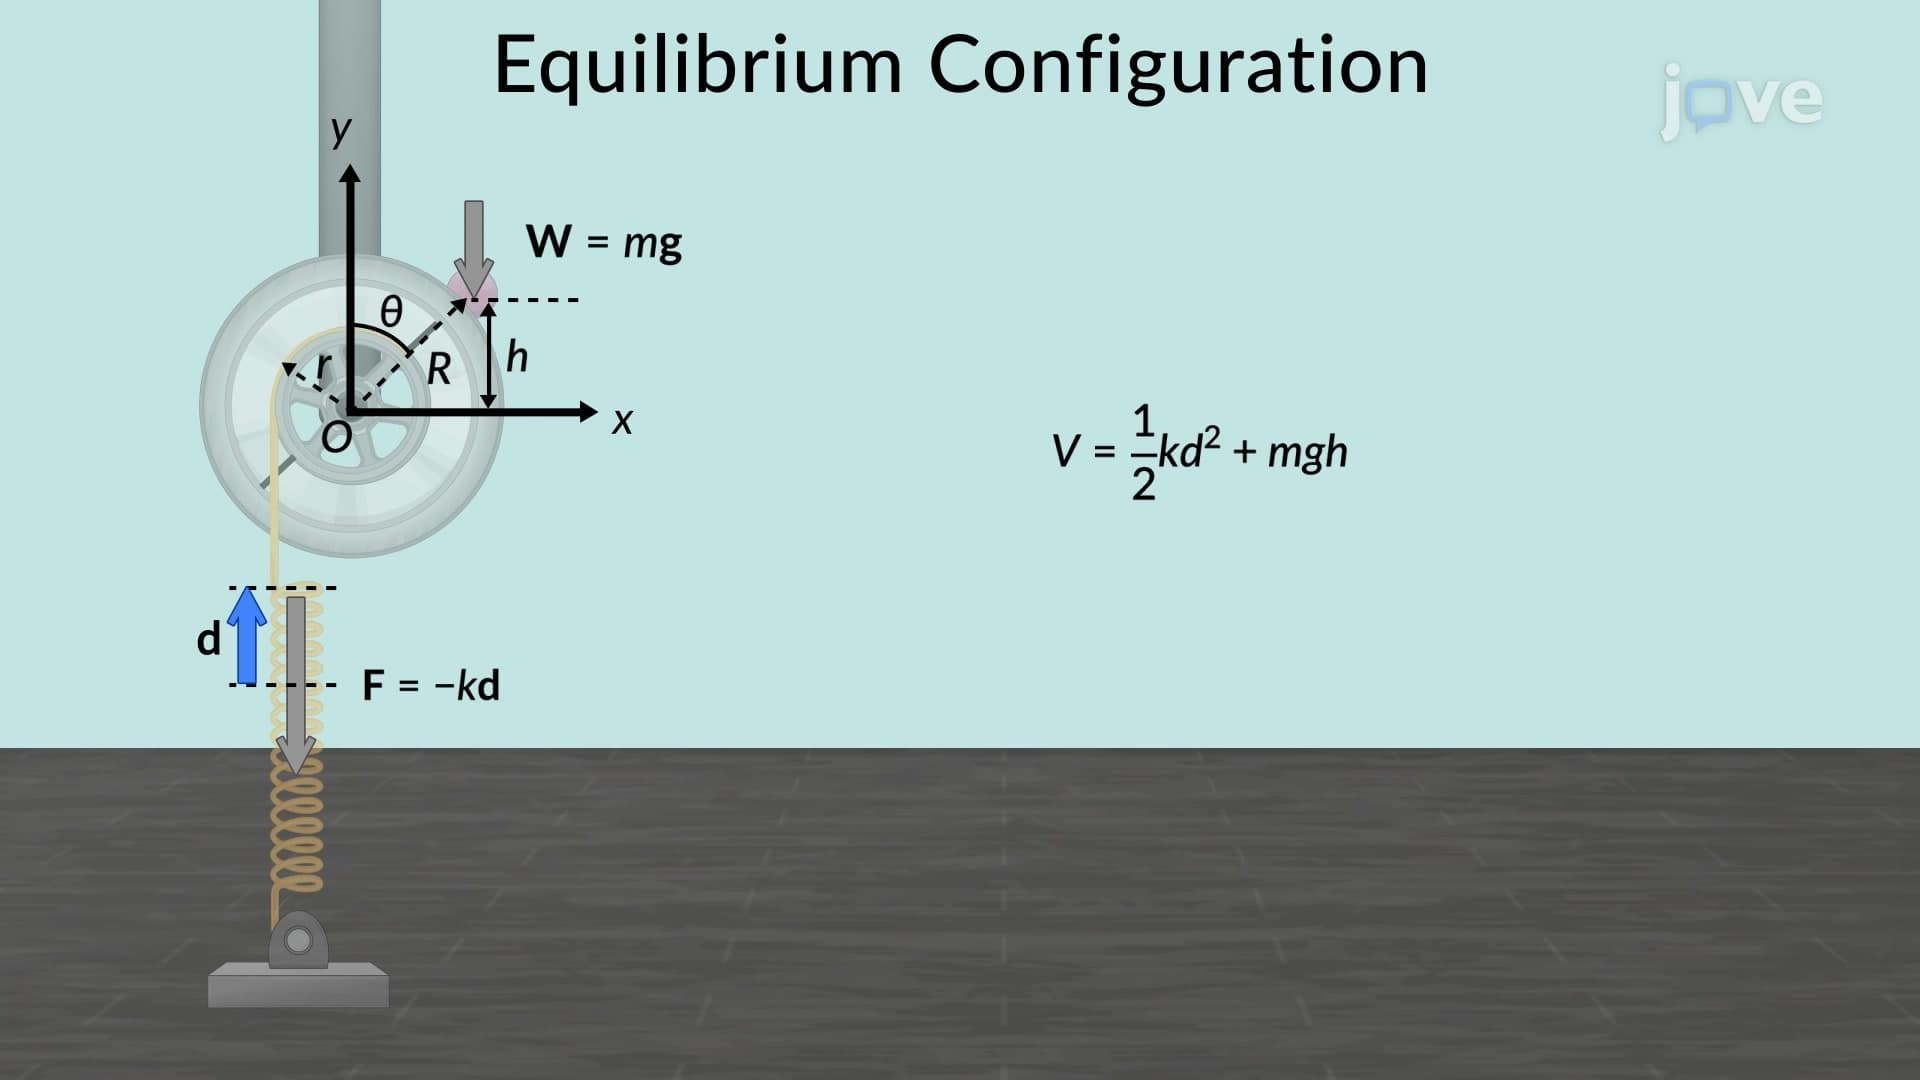
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:24
Types of Limits II