Related Experiment Video
Updated: Dec 27, 2025

Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Multivariable non-minimum state space model predictive control based on disturbance observer
Han Song1, Huiyuan Shi2, Chengli Su1
1School of Information and Control Engineering, Liaoning Shihua University, China.

Abstract:
In order to suppress the influence of lumped system disturbance, such as external disturbance and internal disturbance caused by model mismatch and coupling between variables, more effectively, a multivariable non-minimum state space predictive control method based on disturbance observer (MNMSSPC-D) is proposed in this paper. Most of the existing methods based on the feedback control and feedforward compensation cannot guarantee optimal output. Unlike the existing methods, the proposed method extends the estimated disturbance and output variables into the state variables, forming a multivariable non-minimum state space (MNMSS) prediction model, and then uses the rolling optimization principle in predictive control to design the controller based on the formed prediction model. The main advantages of the proposed method are that the state can be guaranteed to be available to the MNMSS model and the optimal control performance and anti-disturbance ability of system can be obtained by the designed controller. The proposed MNMSSPC-D method is verified by the simulation with a heavy oil fractionator.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:21
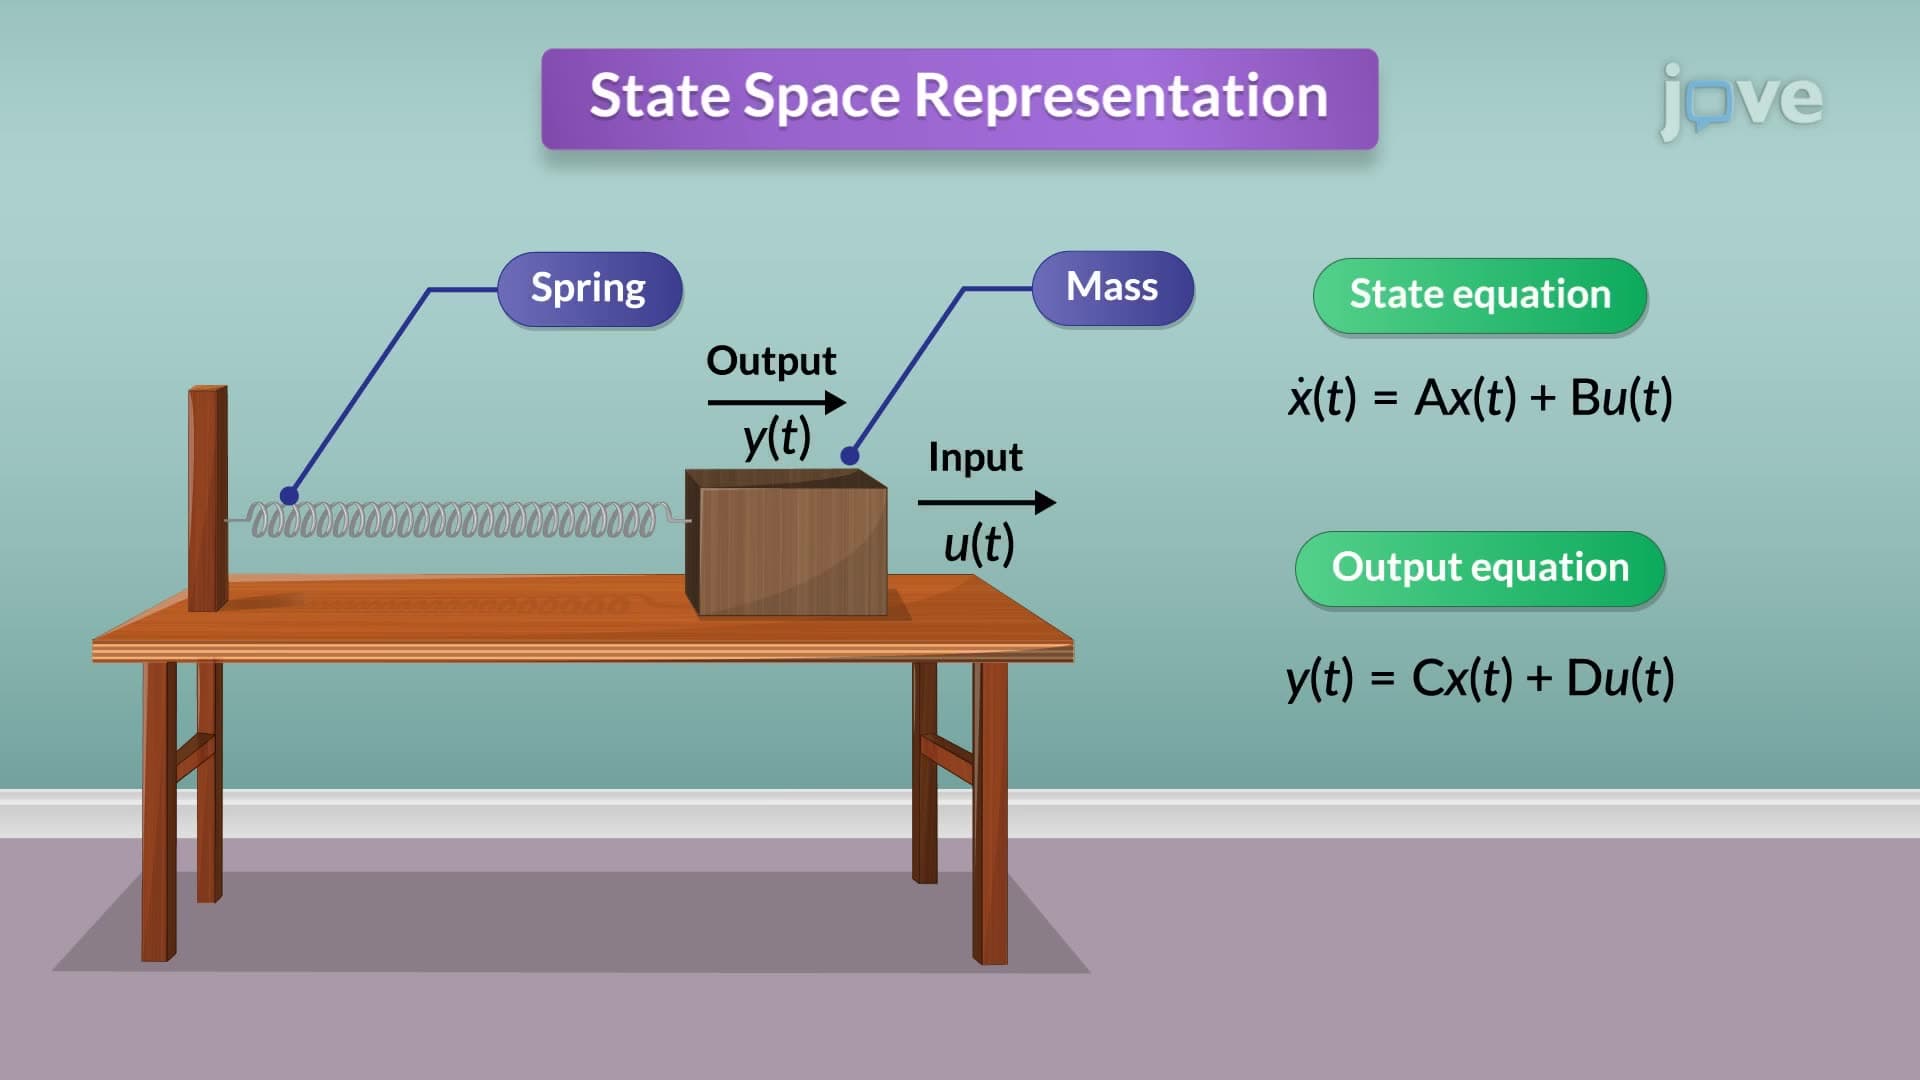
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:23
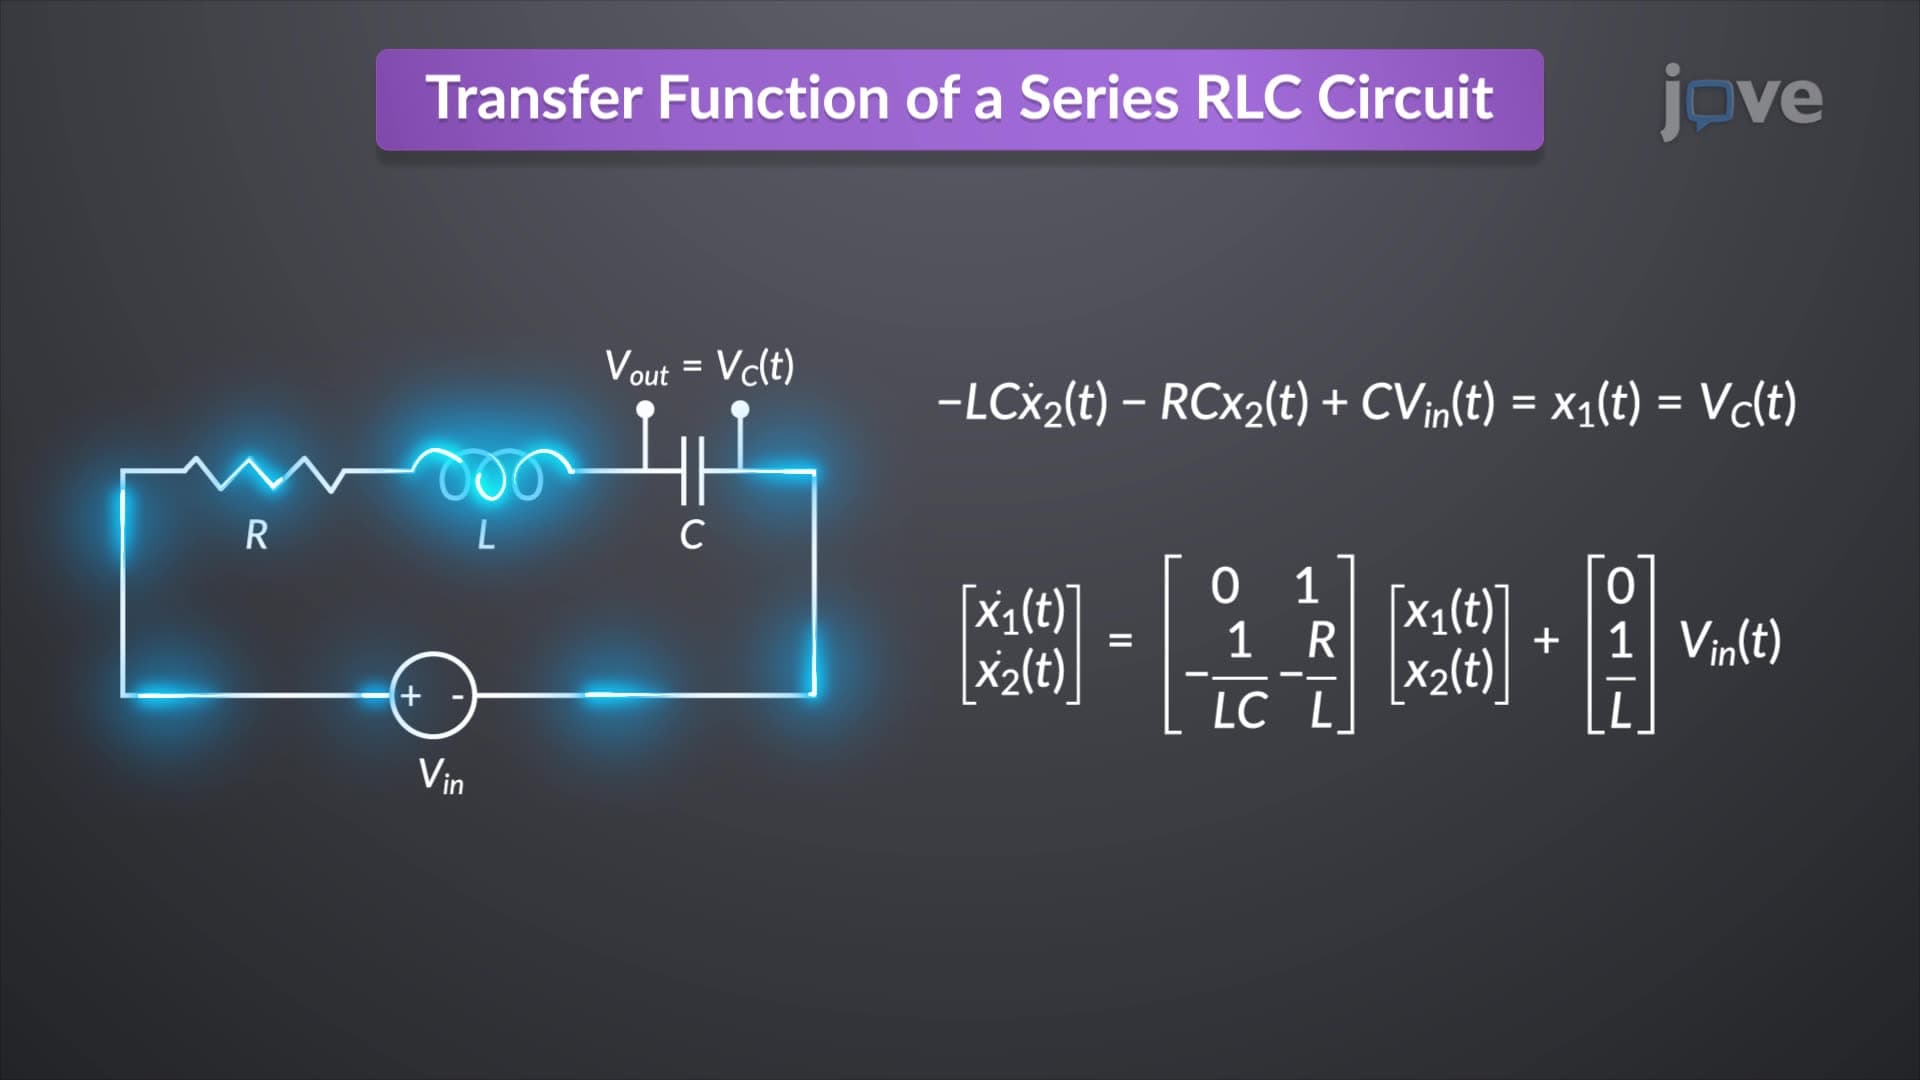
Transfer Function to State Space
In an RLC...