Related Experiment Video
Updated: Oct 12, 2026


Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
A two-stage learning framework for piecewise affine system identification
Mohammad Lotfi1, Mohammad Bagher Menhaj1, Mehdi Karrari1
1Department of Electrical Engineering, Amirkabir University of Technology (Tehran Polytechnic), Tehran, Iran.

Abstract:
This paper proposes a fully data-driven and end-to-end adaptive framework for the complete black-box identification of piecewise affine ARX (PWARX) systems, in which model structure discovery, submodel parameter estimation, recursive parameter fine-tuning, and explicit polyhedral partition identification are integrated into a unified two-stage learning architecture. In Stage 1, an unsupervised process determines the number and order of submodels, computes consistent initial submodel parameter estimates, and constructs a compact labeled training set. In Stage 2, a self-tuning semi-supervised support vector machine (STS3VM) iteratively learns the submodel classifiers, while adaptive-forgetting recursive least squares fine-tunes the submodel parameters. The learned decision rule is then converted into explicit polyhedral partitions, with stage-wise convergence guarantees. Extensive simulations demonstrate high accuracy, reproducibility, robustness under diverse noise conditions, and scalability.

Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:20
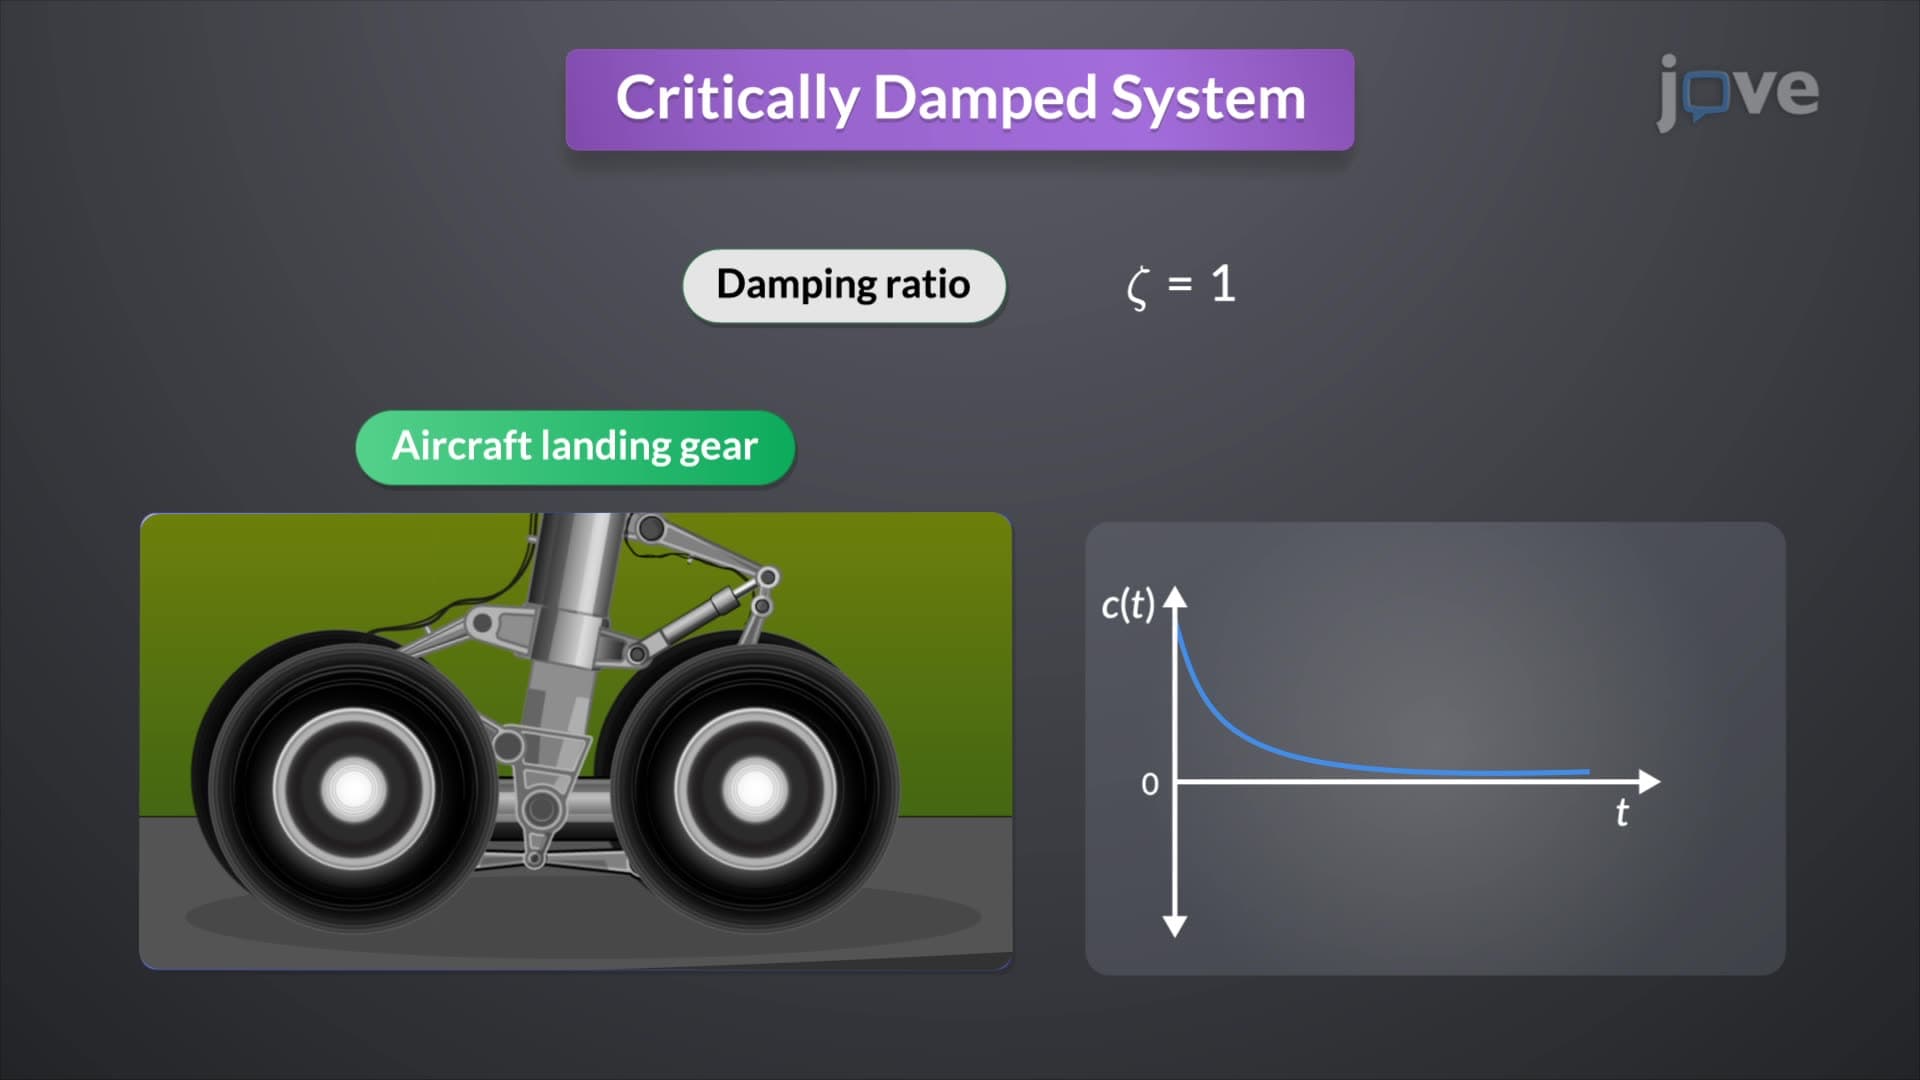
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:18
Second Order systems II
If ζ...