Related Experiment Video
Updated: Dec 26, 2025


Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
VersaVIS-An Open Versatile Multi-Camera Visual-Inertial Sensor Suite
Florian Tschopp1, Michael Riner1, Marius Fehr1,2
1Autonomous Systems Lab, ETH Zurich, 8092 Zurich, Switzerland.

Abstract:
Robust and accurate pose estimation is crucial for many applications in mobile robotics. Extending visual Simultaneous Localization and Mapping (SLAM) with other modalities such as an inertial measurement unit (IMU) can boost robustness and accuracy. However, for a tight sensor fusion, accurate time synchronization of the sensors is often crucial. Changing exposure times, internal sensor filtering, multiple clock sources and unpredictable delays from operation system scheduling and data transfer can make sensor synchronization challenging. In this paper, we present VersaVIS, an Open Versatile Multi-Camera Visual-Inertial Sensor Suite aimed to be an efficient research platform for easy deployment, integration and extension for many mobile robotic applications. VersaVIS provides a complete, open-source hardware, firmware and software bundle to perform time synchronization of multiple cameras with an IMU featuring exposure compensation, host clock translation and independent and stereo camera triggering. The sensor suite supports a wide range of cameras and IMUs to match the requirements of the application. The synchronization accuracy of the framework is evaluated on multiple experiments achieving timing accuracy of less than 1 ms . Furthermore, the applicability and versatility of the sensor suite is demonstrated in multiple applications including visual-inertial SLAM, multi-camera applications, multi-modal mapping, reconstruction and object based mapping.
Related Concept Videos
 01:02
Gyroscope
 01:24
Gyroscope: Precession
 01:25
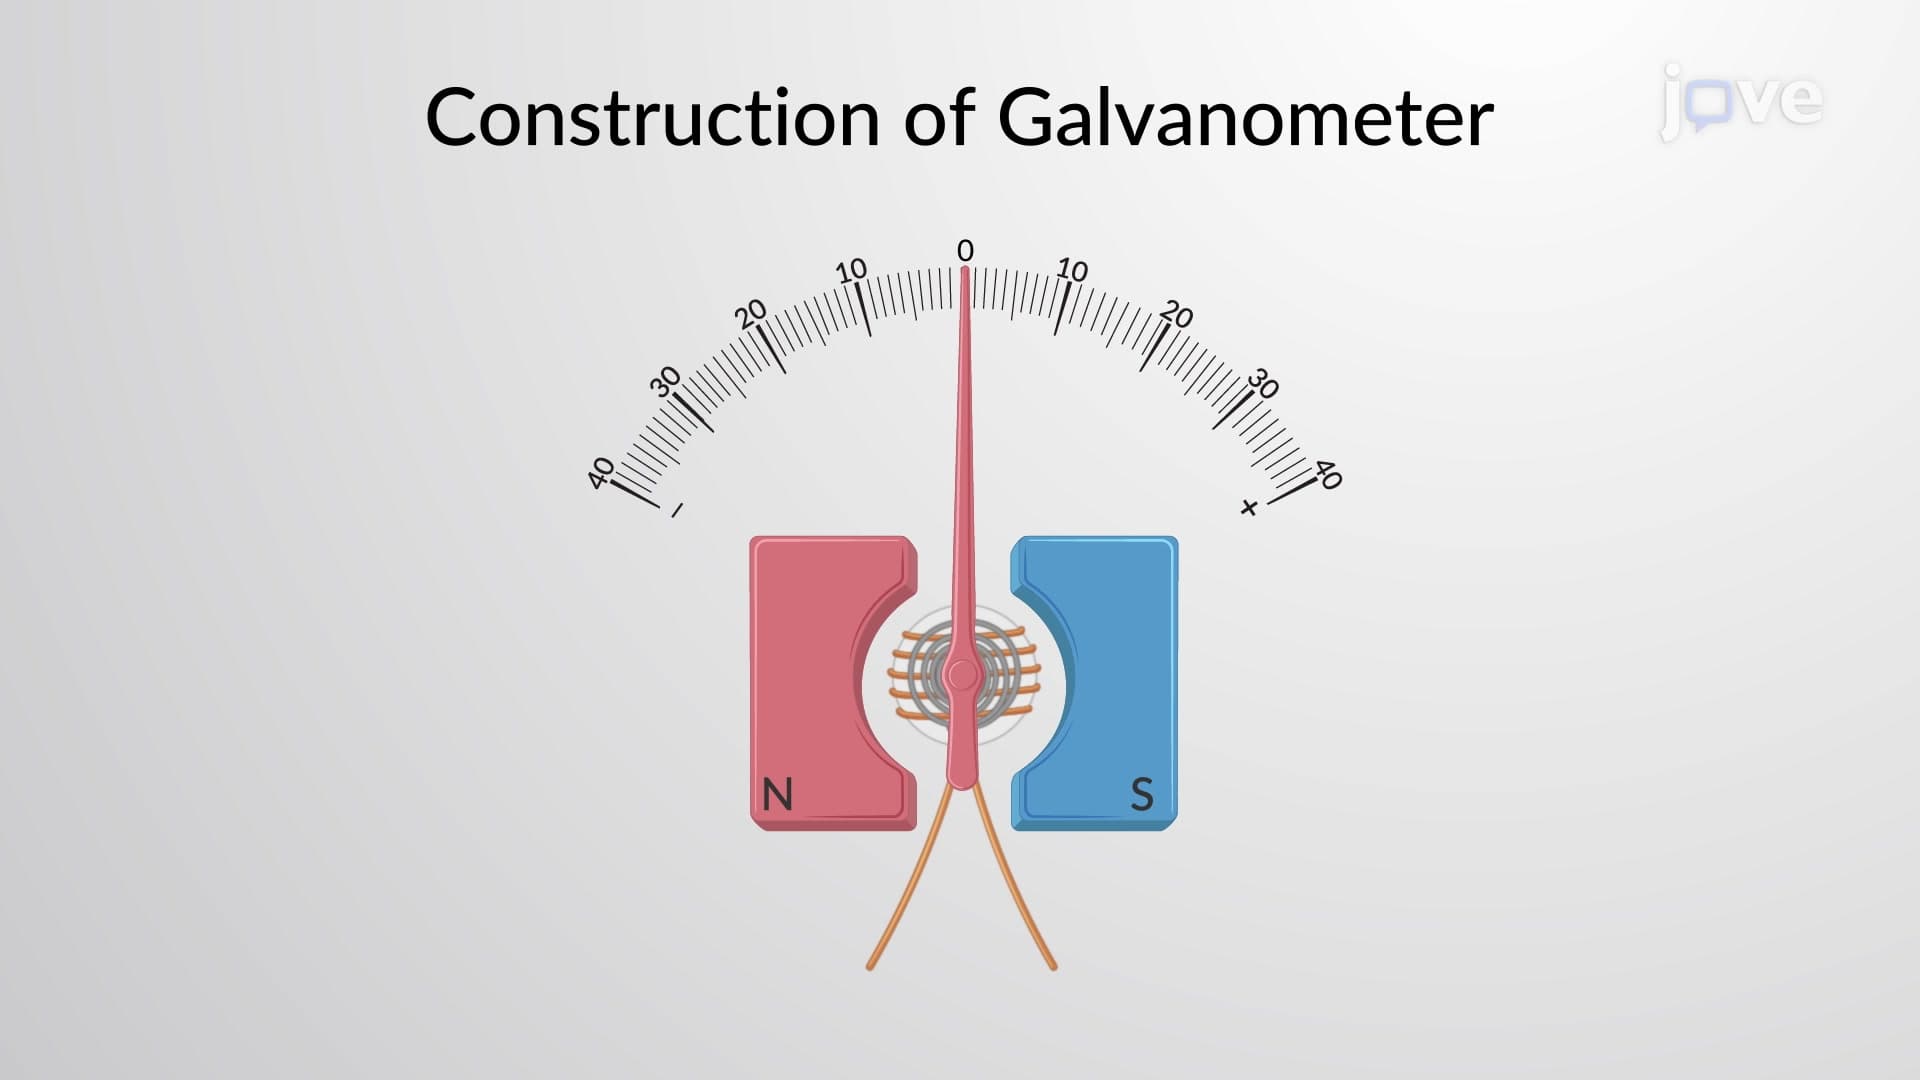
Galvanometer
The galvanometer consists of two concave-shaped permanent magnets, providing a uniform radial magnetic field in the annular region. In the center, a pivoted coil of fine copper wire is placed in the uniform...
 01:03
Inertial Frames of Reference
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 02:16
Light Acquisition