Generalized Convolutional Sparse Coding with Unknown Noise
Related Experiment Video
Updated: Dec 25, 2025
Lensless Fluorescent Microscopy on a Chip
Published on: August 17, 2011

Abstract:
Convolutional sparse coding (CSC) can learn representative shift-invariant patterns from multiple kinds of data. However, existing CSC methods can only model noises from Gaussian distribution, which is restrictive and unrealistic. In this paper, we propose a generalized CSC model capable of dealing with complicated unknown noise. The noise is now modeled by Gaussian mixture model, which can approximate any continuous probability density function. We use the expectation-maximization algorithm to solve the problem and design an efficient method for the weighted CSC problem in maximization step. The crux is to speed up the convolution in the frequency domain while keeping the other computations involving weight matrix in the spatial domain. Besides, we simultaneously update the dictionary and codes by nonconvex accelerated proximal gradient algorithm without bringing in extra alternating loops. The resultant method, called generalized convolutional sparse coding (GCSC), obtains the same space complexity and a smaller running time compared with existing CSC methods. Extensive experiments on synthetic and real-world noisy data sets validate that GCSC can model noise effectively and obtain high-quality filters and representations.
Related Concept Videos
 01:24
Convolution: Math, Graphics, and Discrete Signals
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
 00:59
Propagation of Uncertainty from Random Error
 01:09
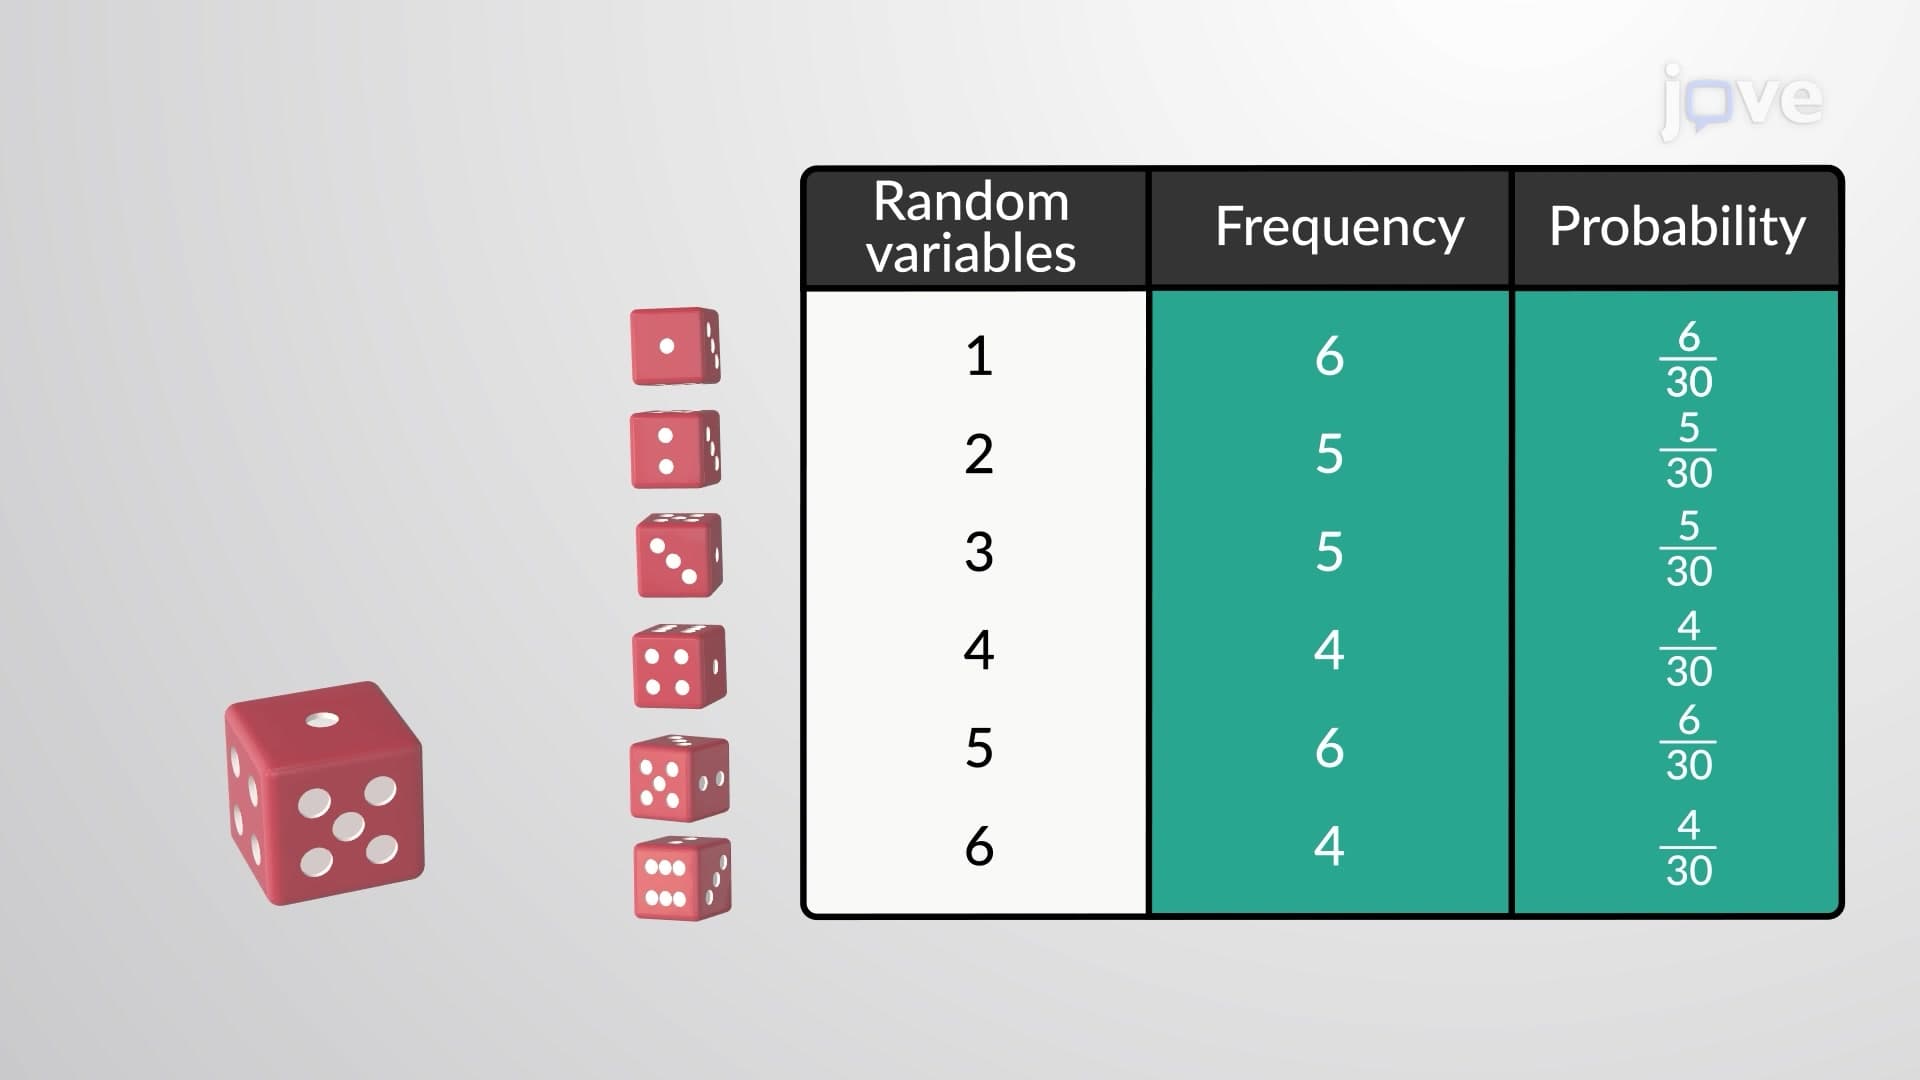
Random Variables
Uppercase letters such as X or Y denote a random variable. Lowercase letters like x or y denote the value of a random variable. If X is a random variable, then X is written in words, and x is given as a number.
For example, let X = the...
 01:20
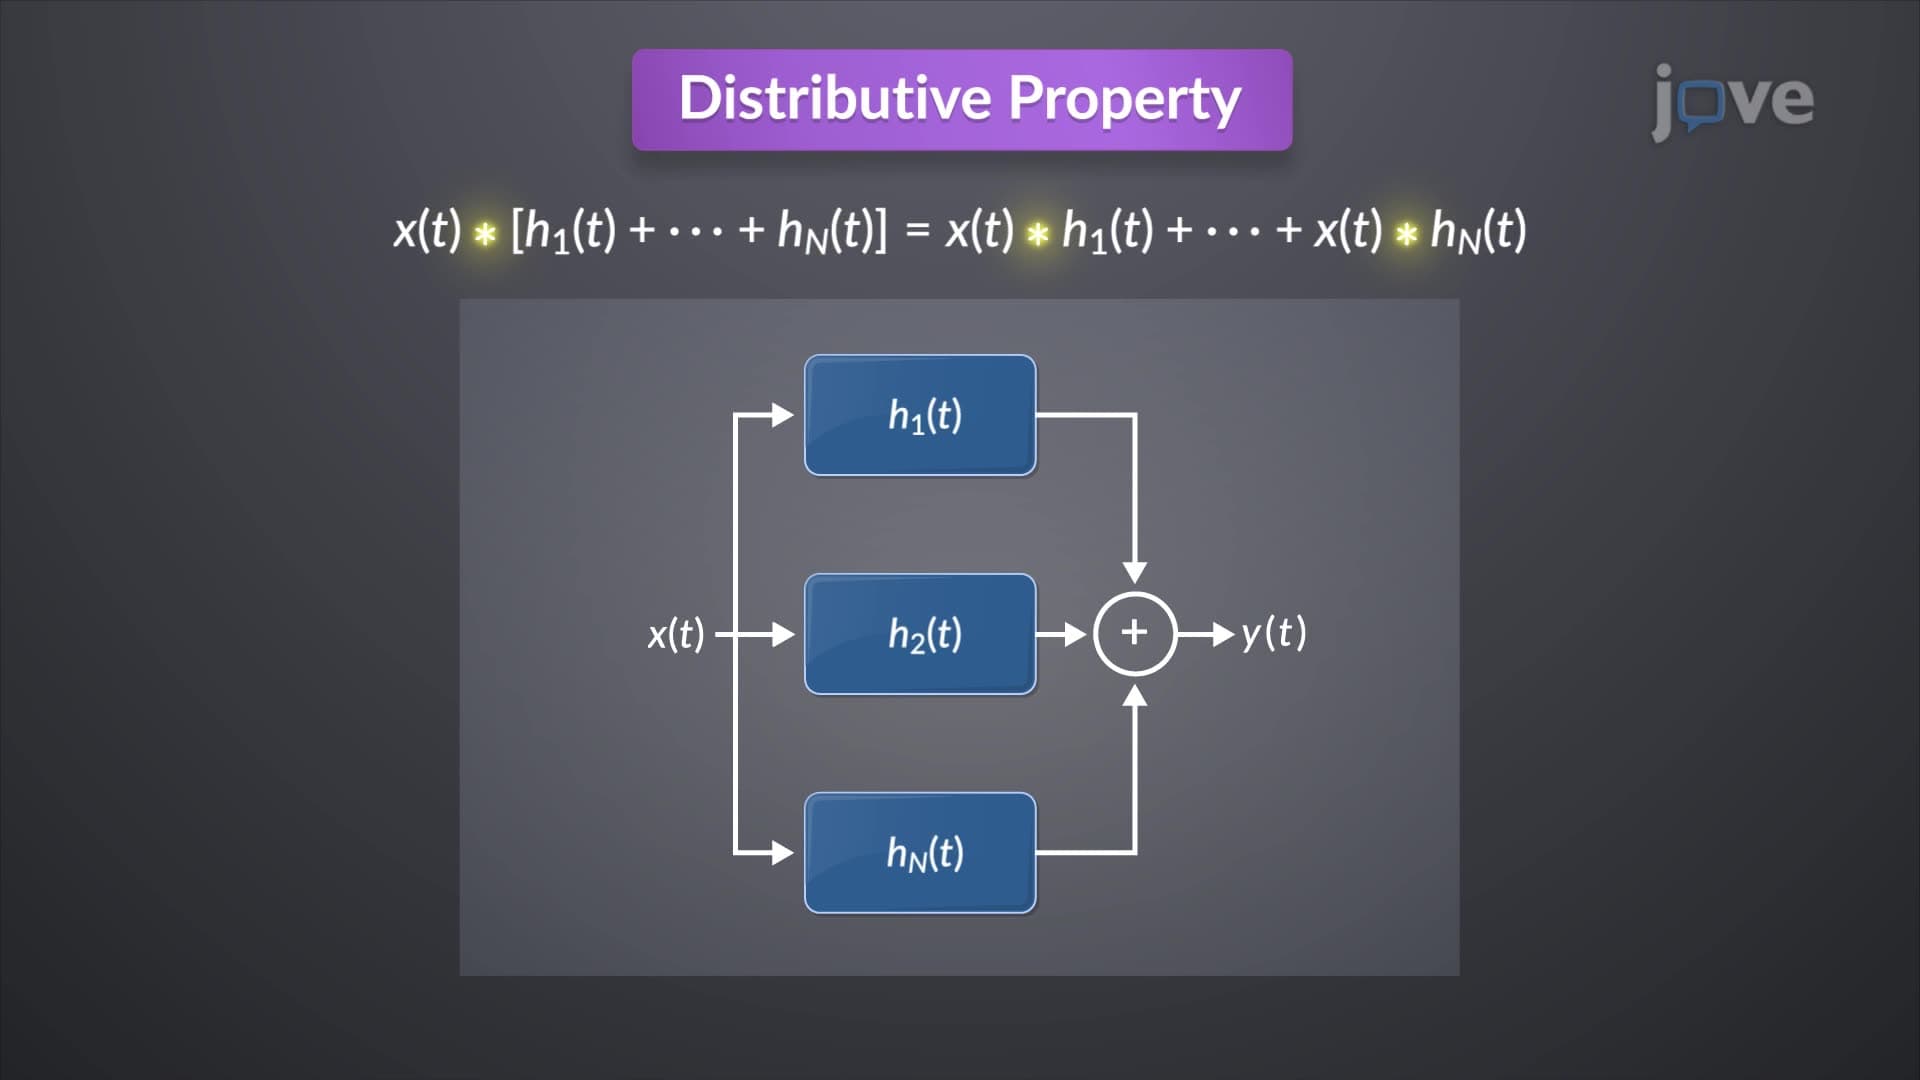
Convolution Properties I
The commutative property reveals that the input and the impulse response of an LTI (Linear Time-Invariant) system can be interchanged without affecting the output:
 01:11
Residuals and Least-Squares Property
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:22
Estimating Population Mean with Unknown Standard Deviation
William S. Gosset (1876–1937) of the...