Related Experiment Video
Updated: Dec 25, 2025
Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Multi-legged steering and slipping with low DoF hexapod robots
1Department of Mechanical Engineering, University of Michigan, Ann Arbor, MI 48105, United States of America.

Abstract:
Thanks to their sprawled posture and multi-legged support, stability is not as hard to achieve for hexapedal robots as it is for bipeds and quadrupeds. A key engineering challenge with hexapods has been to produce insect-like agility and maneuverability, of which steering is an essential part. However, the mechanisms of multi-legged steering are not always clear, especially for robots with underactuated legs. Here we propose a formal definition of steering, and show why steering is difficult for robots with 6 or more underactuated legs. We show that for many of these robots, steering is impossible without slipping, and present experimental results which demonstrate the importance of allowing for slipping to occur intentionally when optimizing steering ability. Our results suggest that a non-holonomic multi-legged slipping model might be more appropriate than dynamic models for representing such robots, and that conventional non-slip contact models might miss significant parts of the performance envelope.


Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
Rolling Resistance: Problem Solving
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:14
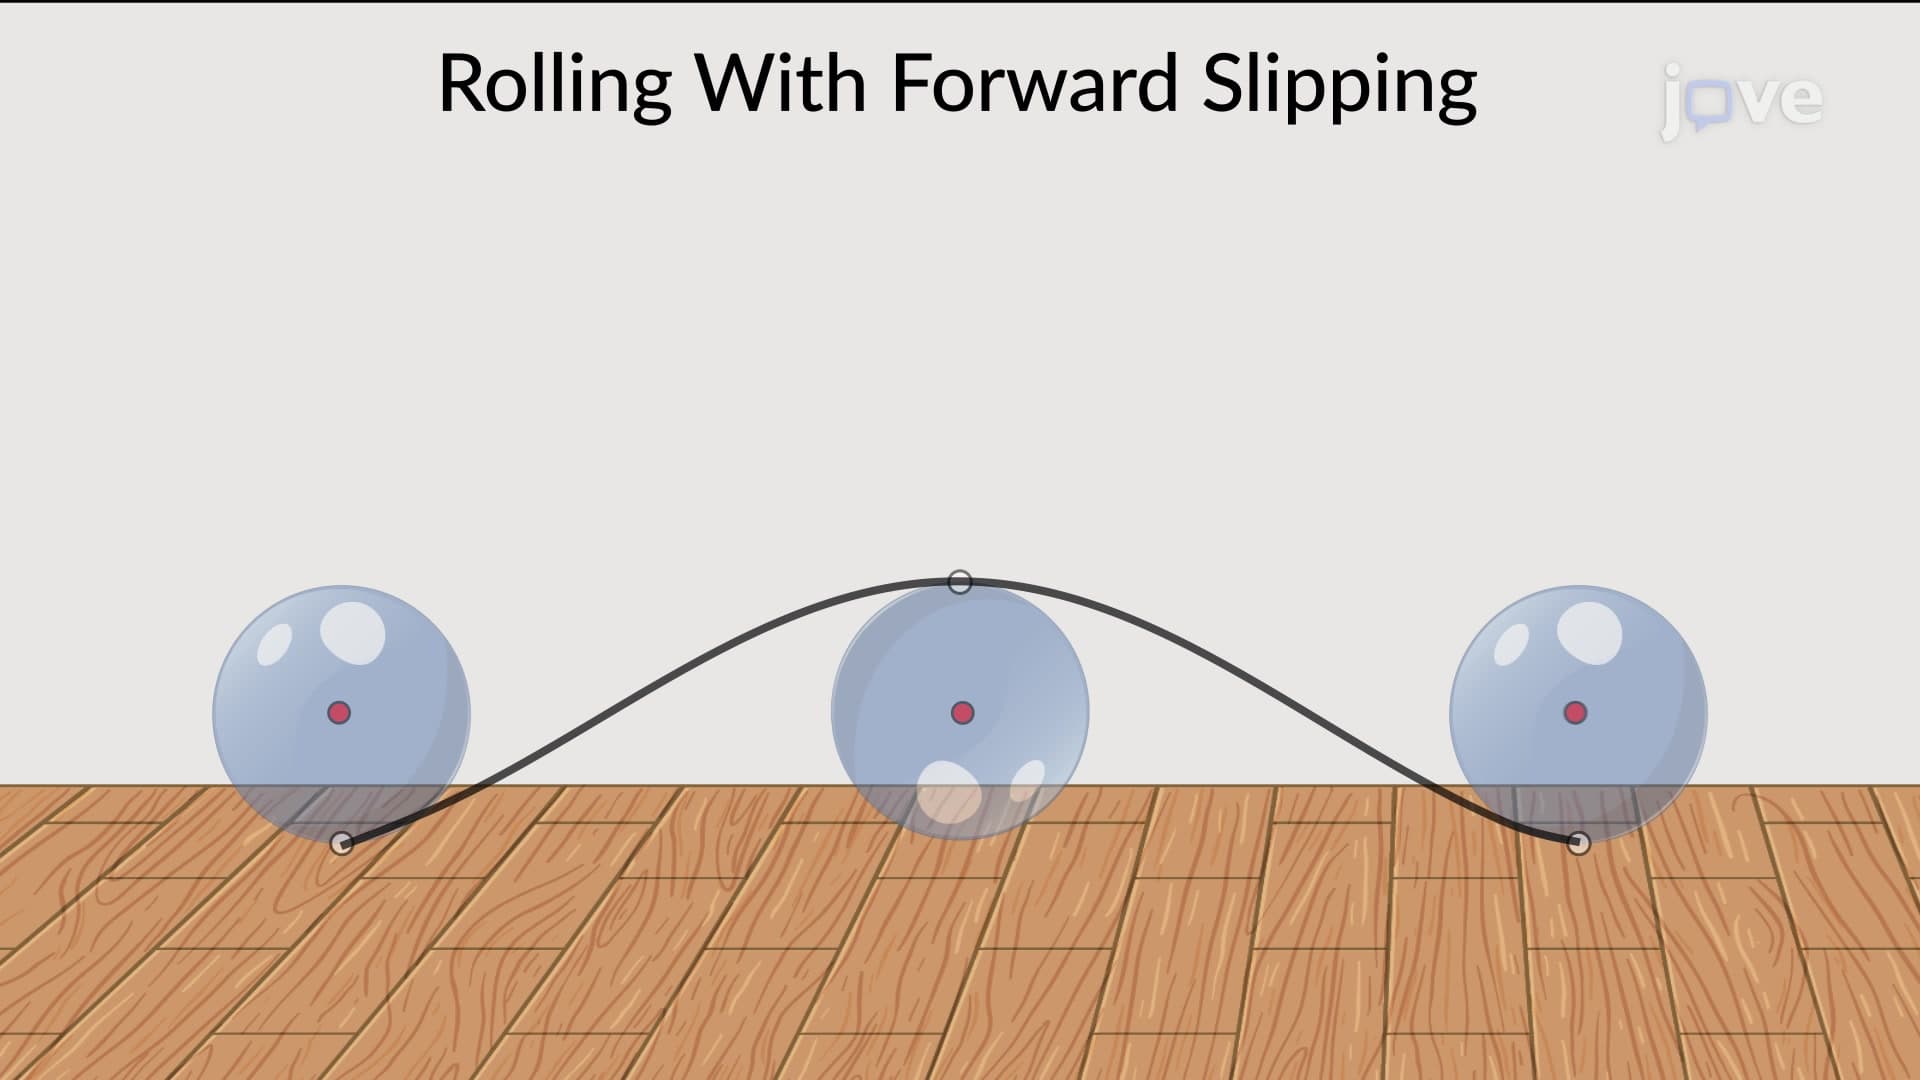
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:09
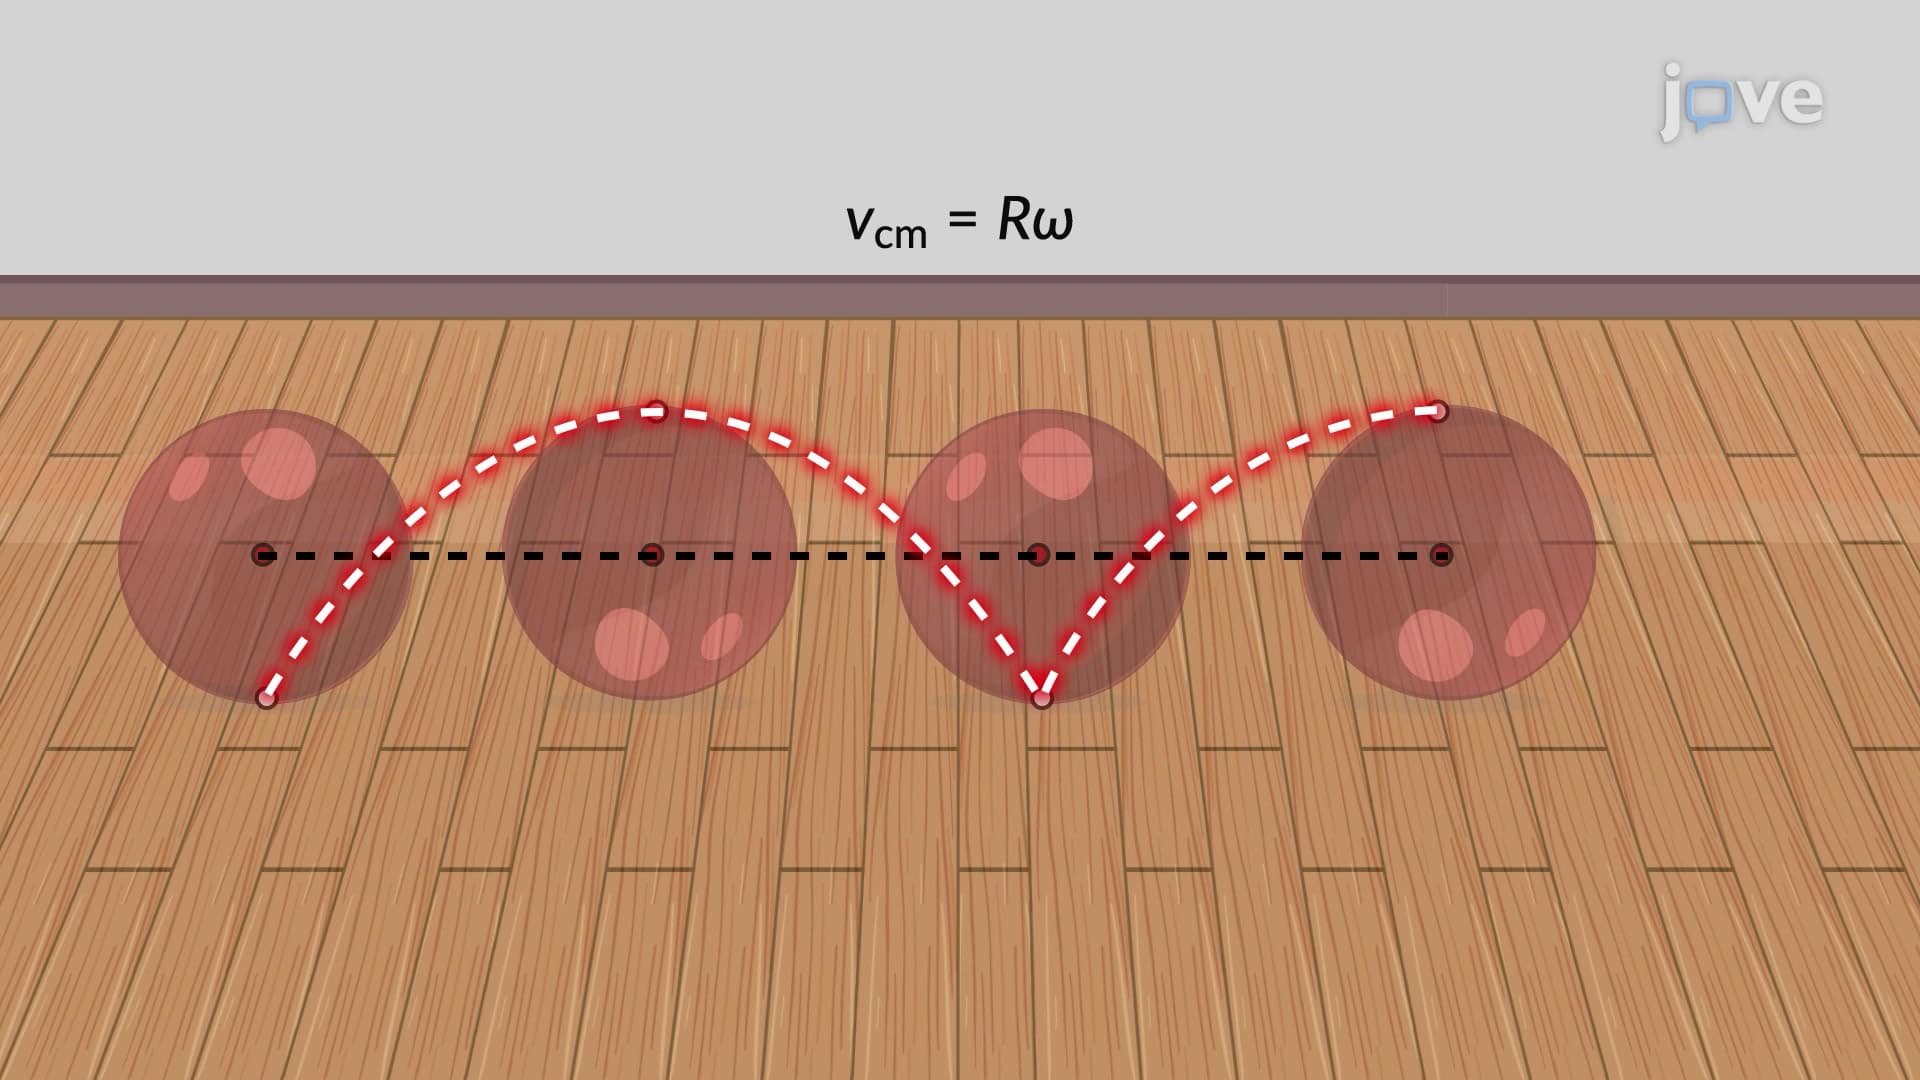
Rolling Without Slipping
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...