

Asynchronous Adaptive Fault-Tolerant Sliding-Mode Control for T-S Fuzzy Singular Markovian Jump Systems With

Abstract:
In this article, the problem of asynchronous sliding-mode control (SMC) for a class of nonlinear singular Markovian jump systems (SMJSs) with actuator faults and uncertain transition rates (TRs) is investigated. Based on Takagi-Sugeno (T-S) fuzzy models, the nonlinear SMJSs are transformed to a set of local linear SMJSs connected by the so-called IF-THEN rules. The hidden Markov model is employed to demonstrate the nonsynchronization phenomenon of the jump mode between the plant and the designed controller. In combination with SMC and adaptive control techniques, a new asynchronous adaptive SMC scheme is developed, which has the ability to completely compensate for the effects of actuator faults and parameter uncertainties. Sufficient conditions for the stochastic asymptotic admissability of the closed-loop T-S fuzzy SMJSs are derived, and the design scheme for controller gain matrices is presented. The reachability of the sliding surface can be guaranteed by the designed control law. Finally, two examples are provided to illustrate the effectiveness of the proposed new design techniques.
More Related Videos

Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
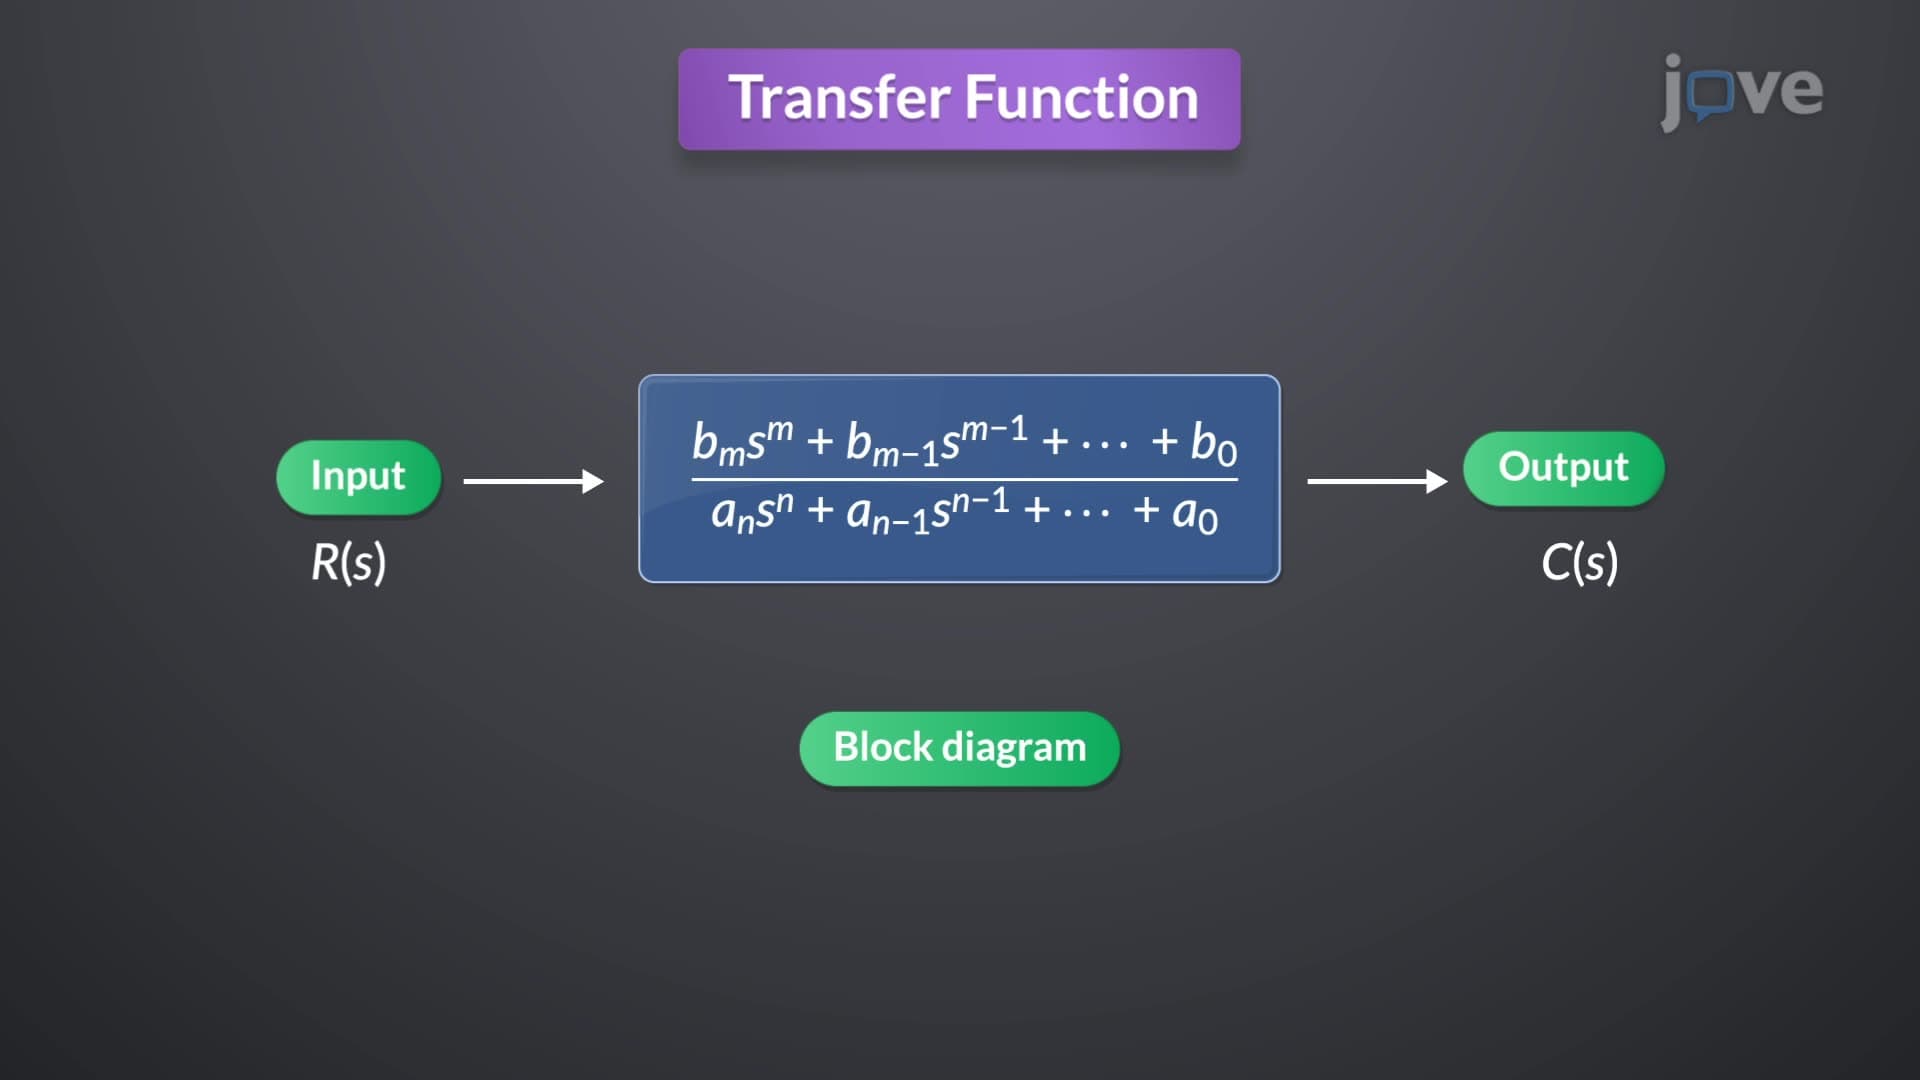
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
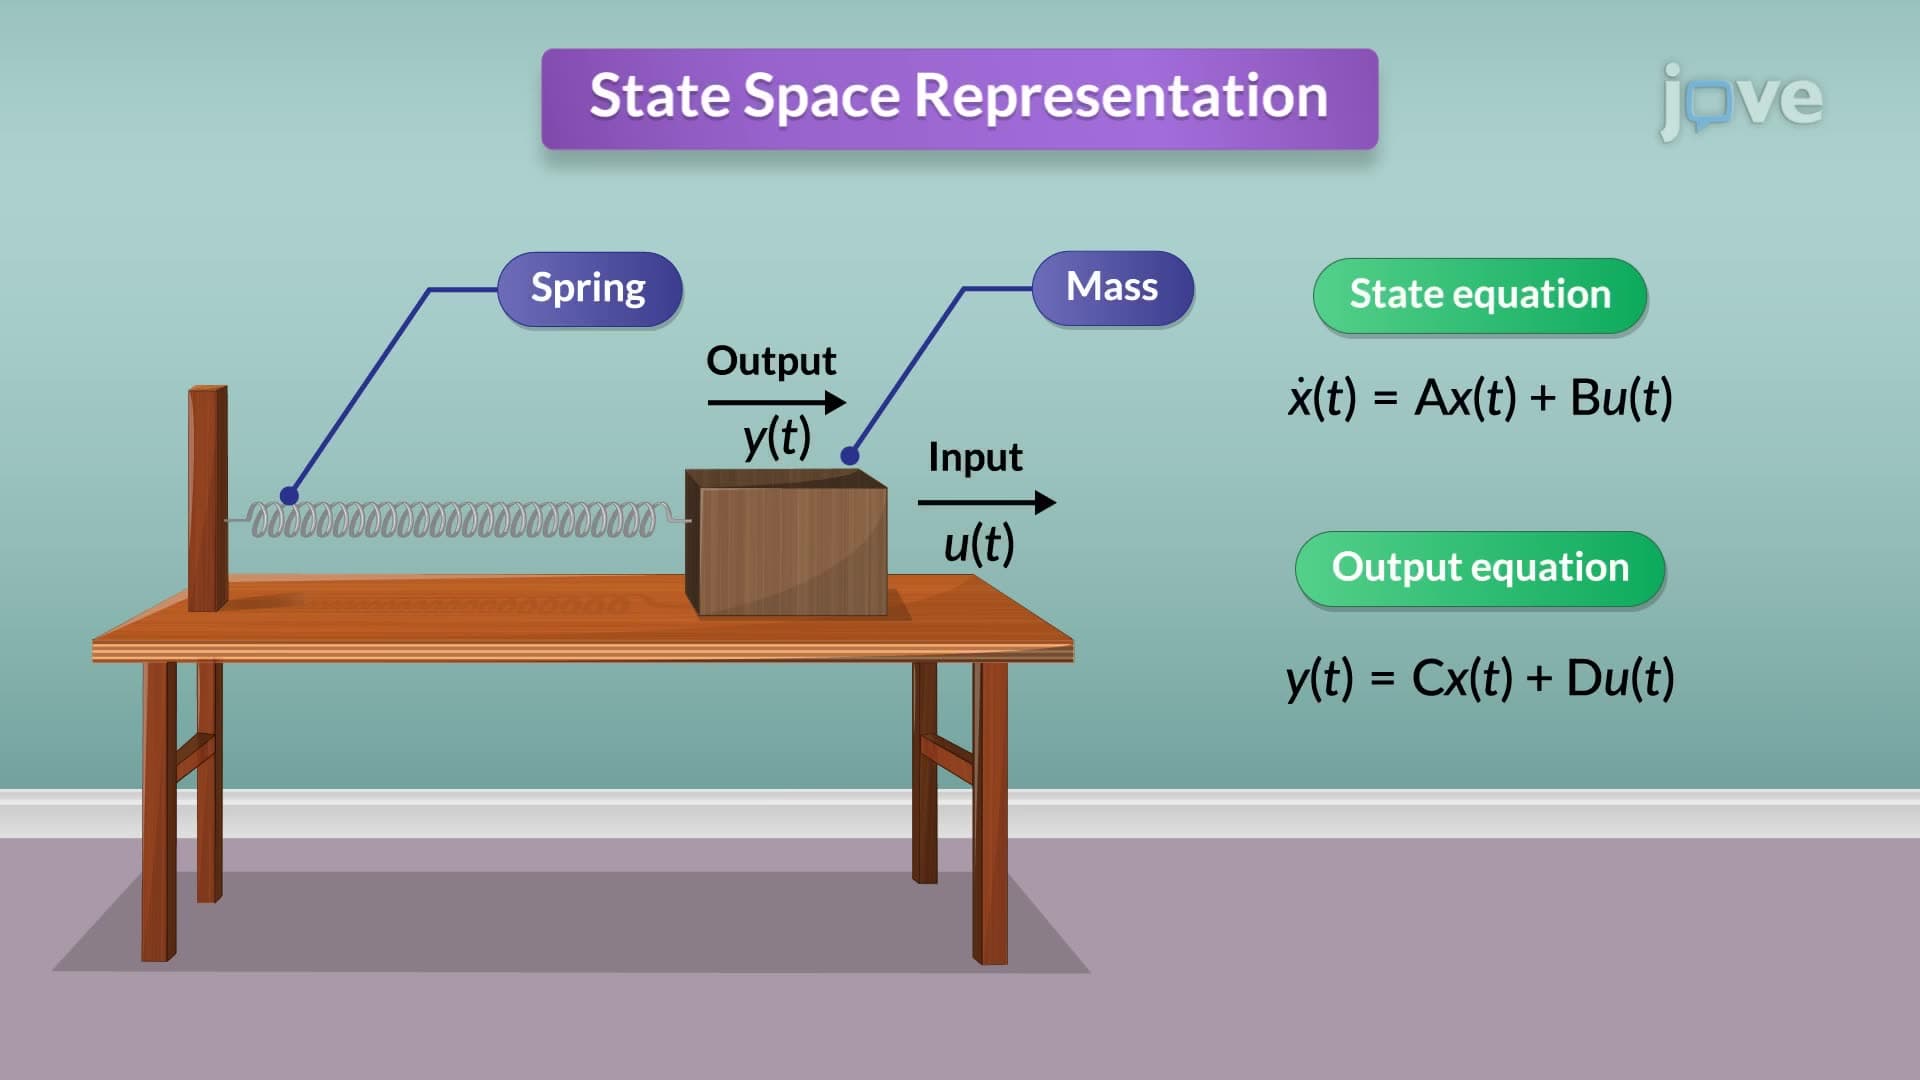
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:23
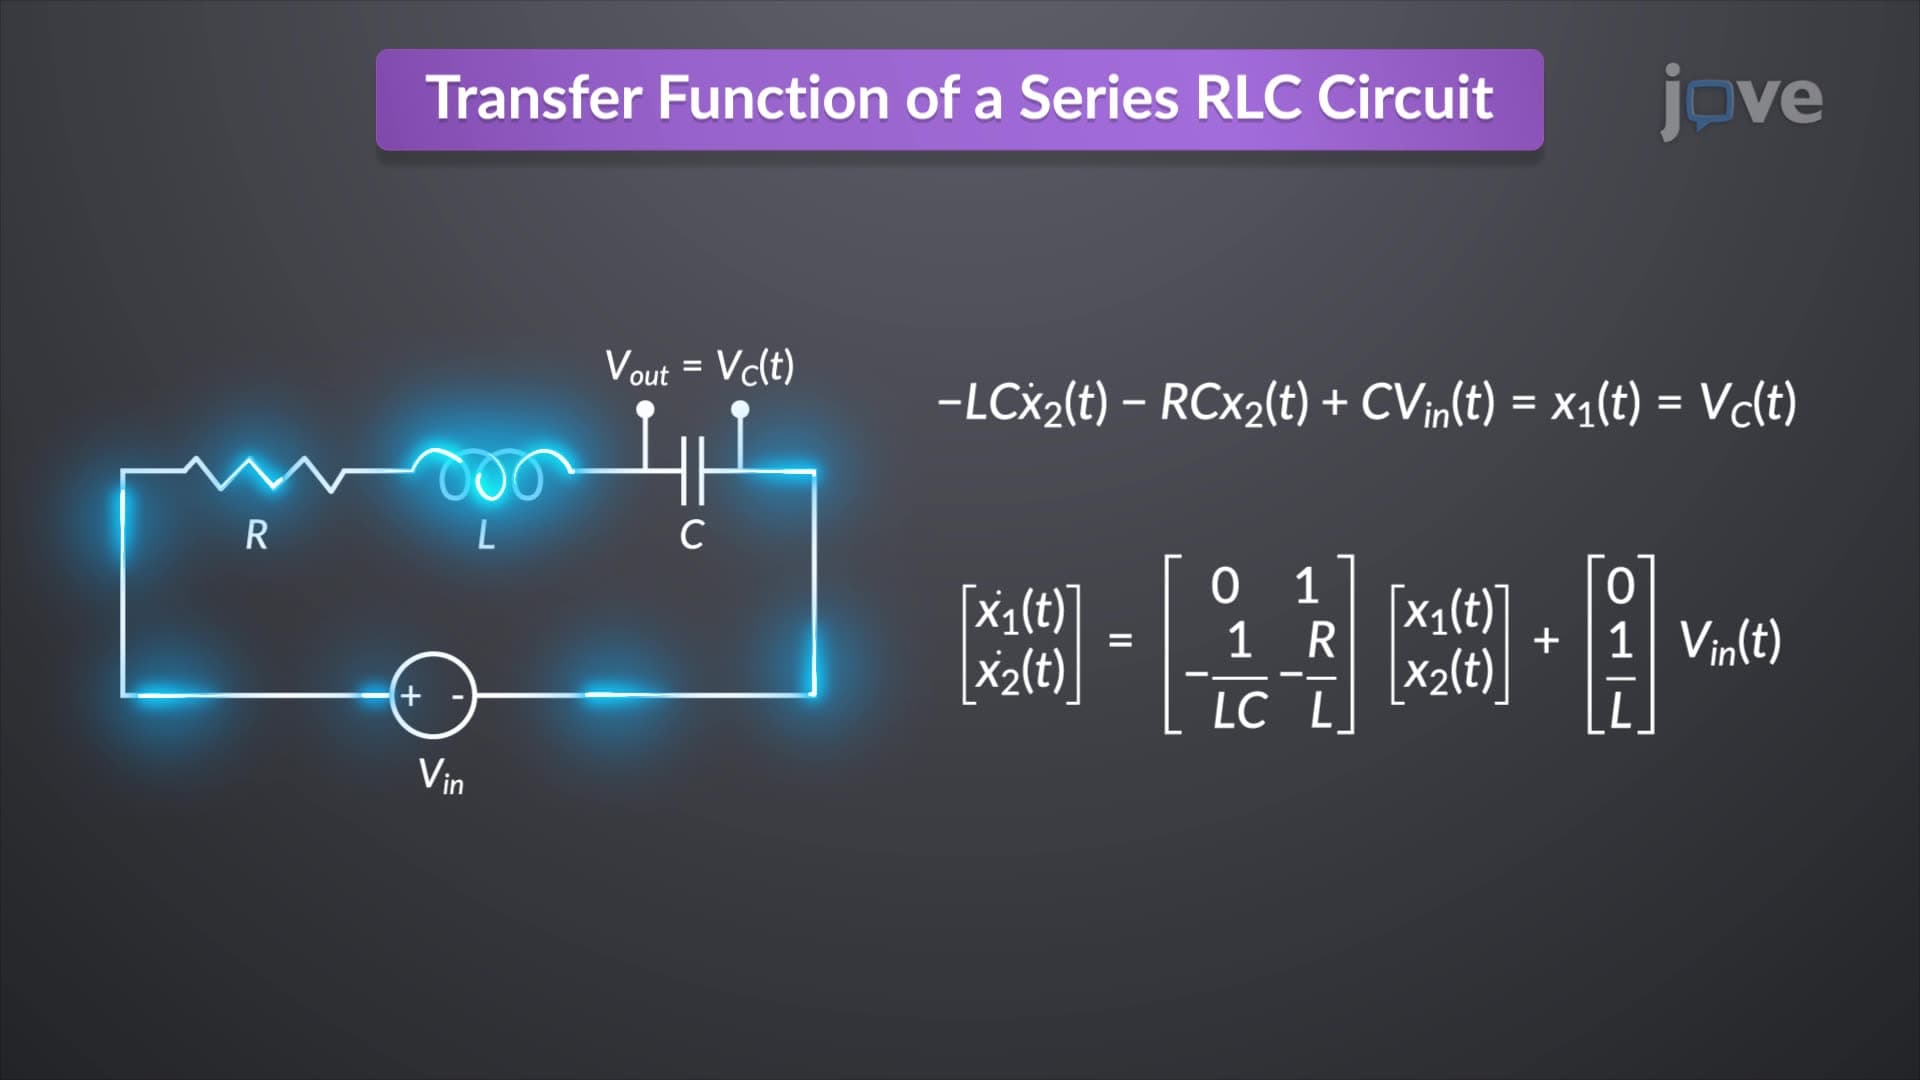
Transfer Function to State Space
In an RLC...