Related Experiment Video
Updated: Dec 21, 2025

Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
Mind your step: learning to walk in complex environments
Rachel Mowbray1, Dorothy Cowie2
1Department of Psychology, University of Durham, Durham, DH1 3LE, UK. rachel.mowbray@durham.ac.uk.

Abstract:
In everyday contexts, children must respond to both self-related constraints (their own skills and abilities) and environmental constraints (external obstacles and goals). How do young children simultaneously accommodate these to support skilled and flexible behaviour? We used walking in a complex environment as a testbed for two hypotheses. Hypothesis 1: children will accommodate the self-related constraint of high foot placement variability via dynamic scaling. Hypothesis 2: children will plan ahead, even in complex environments. In our task, 3- to 5-year-olds and adults walked over obstacle sequences of varying complexity. We measured foot placement around the first obstacle in the sequence. Hypothesis 1 was partially supported. In simple, single obstacle environments, children engaged in dynamic scaling like adults. Those with more variable foot placement left greater margins of error between the feet and the obstacle. However, in complex, multiple obstacle settings, children employed large, un-tailored margins of error. This parallels other multisensory tasks in which children do not rely on the relative variability of sensory inputs. Hypothesis 2 was supported. Like adults, children planned ahead for environmental constraints. Children adjusted foot placement around the first obstacle depending on the upcoming obstacle sequence. In doing so, they demonstrate surprisingly sophisticated planning. We, therefore, show that in the motor domain, even very young children simultaneously control both self-related and environmental constraints. This allows flexible, safe and efficient behaviour.
Related Concept Videos
 01:12
Observational Learning
 01:17
Rolling Resistance: Problem Solving
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:22
Purposive Learning
 01:16
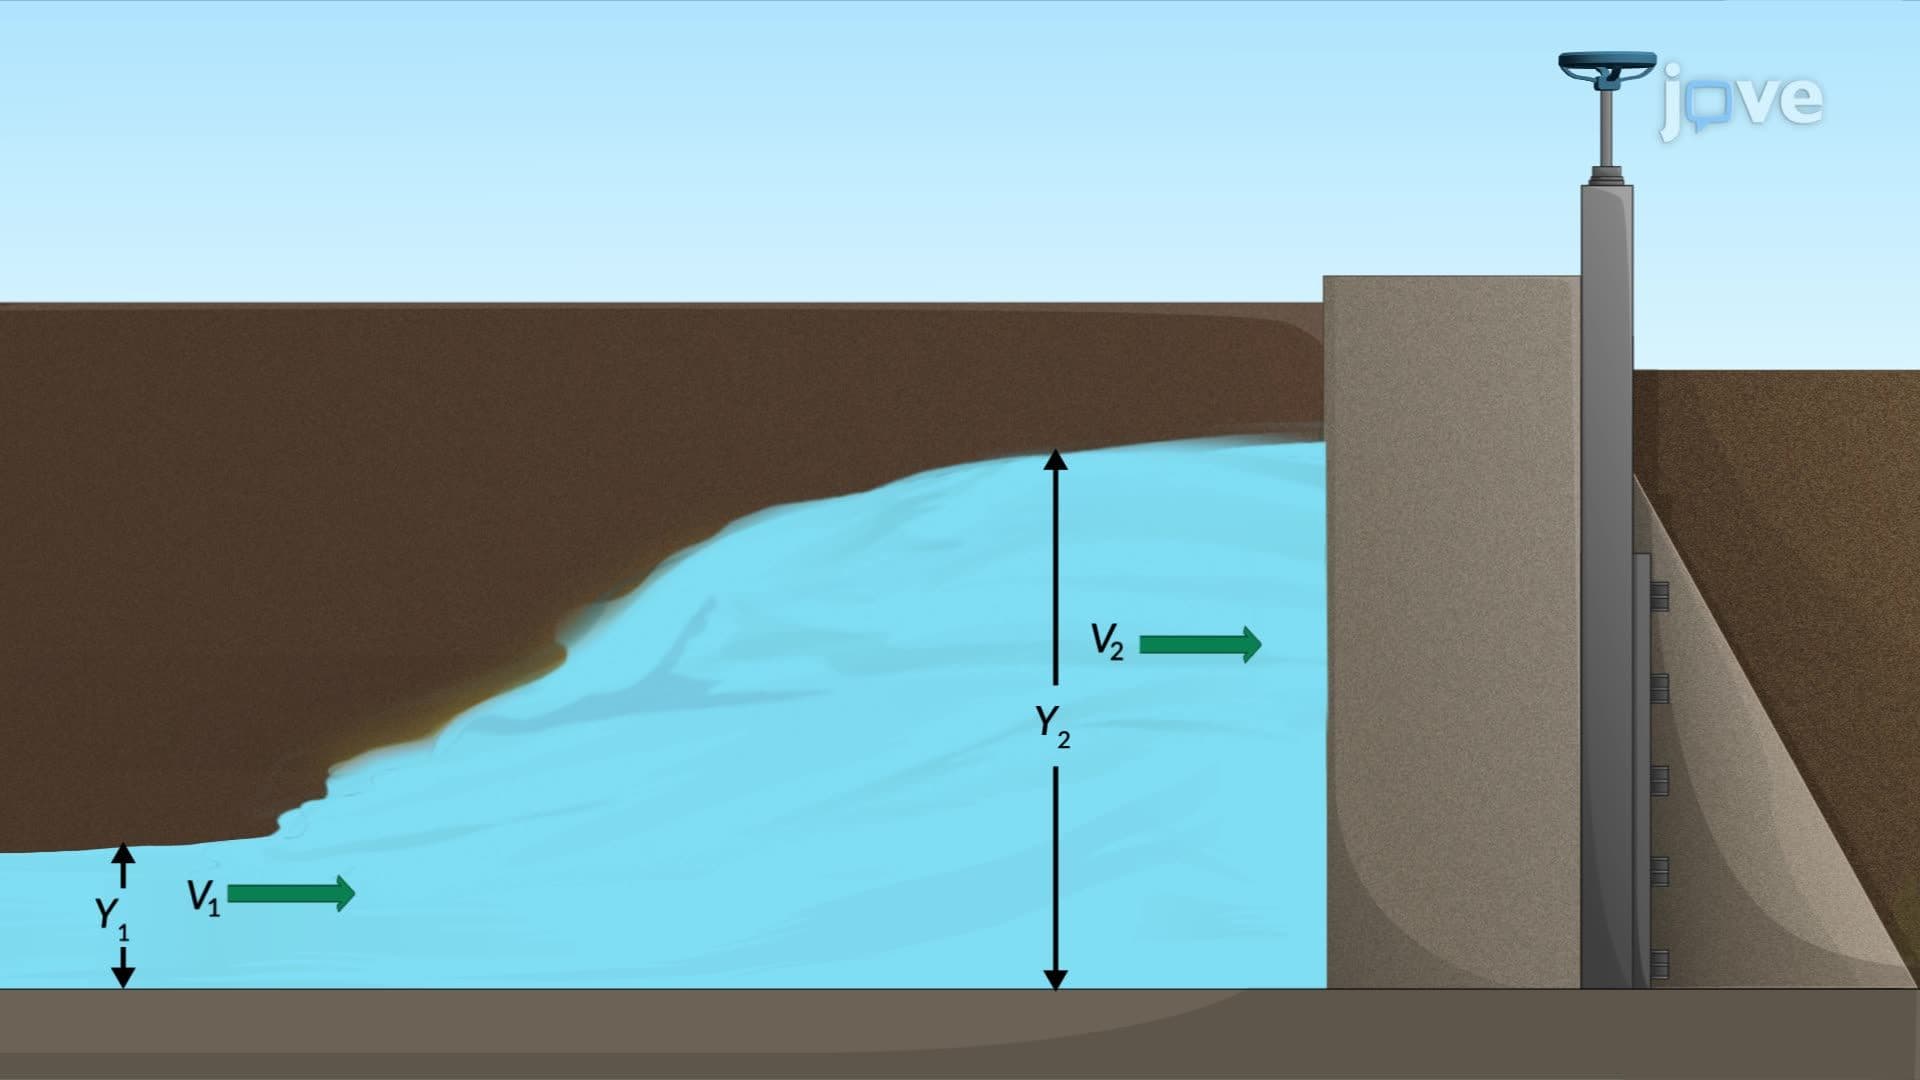
Hydraulic Jump: Problem Solving
 01:18
Introduction to Learning
In contrast to learned behaviors, unlearned behaviors such as crying, sexual...