Related Experiment Video
Updated: Dec 20, 2025
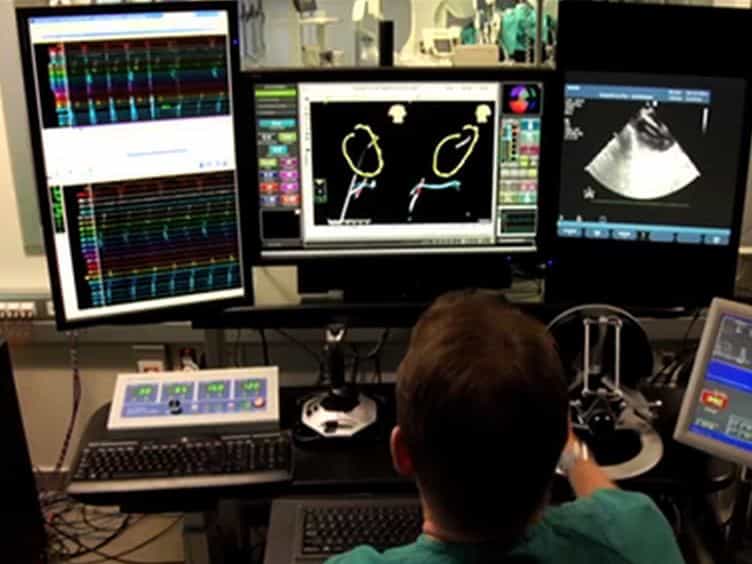

Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
A generalized predictive control for remote cardiovascular surgical systems
Zhi Hu1, Junfeng Zhang2, Le Xie3
1Laboratory of Intelligent Control and Robotics, Shanghai University of Engineering Science, Shanghai, China; School of Instrument Science and Engineering, Southeast University, Nanjing, China.

Abstract:
Robot-assisted cardiovascular surgery is used to avoid surgeon suffering from X-ray radiation and relieve fatigue caused by long-time standing wearing protective clothing. Its remote surgery can alleviate the lack of experienced doctors in remote areas. Due to the existence of time-delay phenomena, flexible deformation and nonlinearity of interventional instruments, it is difficult to ensure system transparency. This paper analyzes the evaluation index of system transparency. A generalized predictive control (GPC) is developed to suppress the effect of time-varying delay and parameter identification error. Moreover, a terminal sliding mode controller (SMC) is designed to improve the robustness of the system under consideration. Simulation results are provided to show that the proposed control strategy can improve transparency of the remote vascular interventional surgery system.
More Related Videos


Related Concept Videos
 01:10
Control Systems
At the heart...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:30
Pulse rhythm
Conversely, an irregular pulse pattern is termed dysrhythmia, stemming from disruptions in cardiac...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...