Related Experiment Video
Updated: Dec 18, 2025
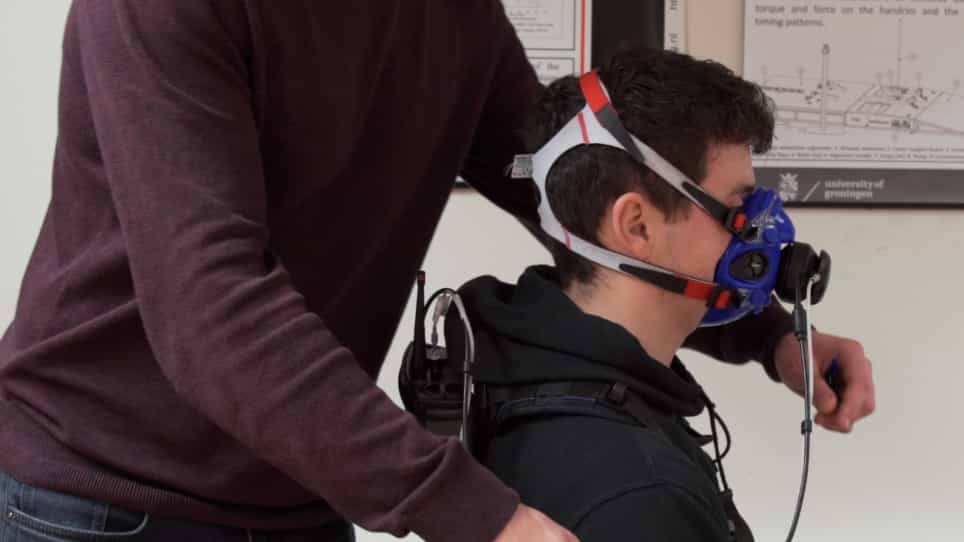

Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
Modeling manual wheelchair propulsion cost during straight and curvilinear trajectories
Jacob Misch1,2, Morris Huang1,3, Stephen Sprigle1,2,4
1Rehabilitation Engineering and Applied Research Laboratory, Georgia Institute of Technology, Atlanta, Georgia, United States of America.

Abstract:
Minimizing the effort to propel a manual wheelchair is important to all users in order to optimize the efficiency of maneuvering throughout the day. Assessing the propulsion cost of wheelchairs as a mechanical system is a key aspect of understanding the influences of wheelchair design and configuration. The objective of this study was to model the relationships between inertial and energy-loss parameters to the mechanical propulsion cost across different wheelchair configurations during straight and curvilinear trajectories. Inertial parameters of an occupied wheelchair and energy loss parameters of drive wheels and casters were entered into regression models representing three different maneuvers. A wheelchair-propelling robot was used to measure propulsion cost. General linear models showed strong relationships (R2 > 0.84) between the system-level costs of propulsion and the selected predictor variables representing sources of energy loss and inertial influences. System energy loss parameters were significant predictors in all three maneuvers. Yaw inertia was also a significant predictor during zero-radius turns. The results indicate that simple energy loss measurements can predict system-level performance, and inertial influences are mostly overshadowed by the increased resistive losses caused by added mass, though weight distribution can mitigate some of this added cost.
More Related Videos
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
 08:08
Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Related Concept Videos
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:17
Rolling Resistance: Problem Solving
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:24
Normal and Tangetial Components: Problem Solving
 01:23
Quadratic Models
 01:17
Dynamics Of Circular Motion: Applications