Related Experiment Video
Updated: Dec 18, 2025
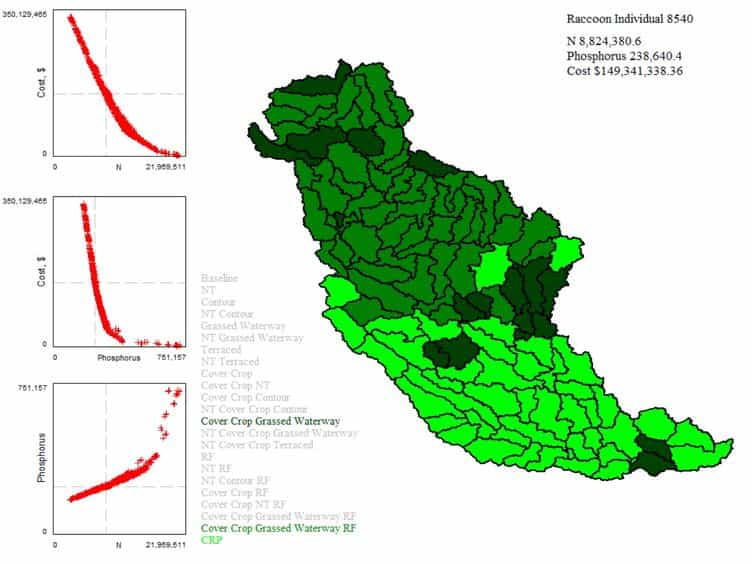
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
A Cooperative Evolutionary Framework Based on an Improved Version of Directed Weight Vectors for Constrained

Abstract:
When solving constrained multiobjective optimization problems (CMOPs), the most commonly used way of measuring constraint violation is to calculate the sum of all constraint violations of a solution as its distance to feasibility. However, this kind of constraint violation measure may not reflect the distance of an infeasible solution from feasibility for some problems, for example, when an infeasible solution closer to a feasible region does not have a smaller constraint violation than the one farther away from a feasible region. Unfortunately, no set of artificial benchmark problems focusing on this area exists. To remedy this issue, a set of CMOPs with deceptive constraints is introduced in this article. It is the first attempt to consider CMOPs with deceptive constraints (DCMOPs). Based on our previous work, which designed a set of directed weight vectors to solve CMOPs, this article proposes a cooperative framework with an improved version of directed weight vectors to solve DCMOPs. Specifically, the cooperative framework consists of two switchable phases. The first phase uses two subpopulations-one to explore feasible regions and the other to explore the entire space. The two subpopulations provide useful information about the optimal direction of objective improvement to each other. The second phase aims mainly at finding Pareto-optimal solutions. Then an infeasibility utilization strategy is used to improve the objective function values. The two phases are switchable based on the information found to date at any time in the evolutionary process. The experimental results show that this method significantly outperforms the algorithms with which it is compared on most of the DCMOPs, in terms of reliability and stability in finding a set of well-distributed optimal solutions.
More Related Videos

Related Concept Videos
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 00:48
Optimal Foraging
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Application of Nonlinear Inequalities
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:21
Heuristics
People often rely on heuristics when faced with an overload of information, limited time, low importance of the decision, limited information, or when a heuristic readily comes to mind. For...