Related Experiment Video
Updated: Dec 17, 2025
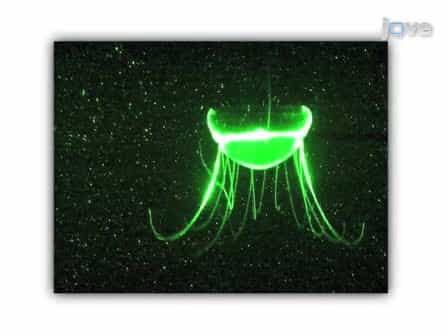

Quantitatively Measuring In situ Flows using a Self-Contained Underwater Velocimetry Apparatus SCUVA
Published on: October 31, 2011
Scanning-Chain Formation Control for Multiple Unmanned Surface Vessels to Pass Through Water Channels

Abstract:
For scenarios to pass through narrow and irregular channels, we develop a pragmatic distributed flexible formation protocol for multiple unmanned surface vessel systems (Multi-USVs). Therein, for path tracking with two leaders USVs, we propose a model predictive trajectory tracking scheme. Specifically, we design a scanning-formation controller with a trajectory state estimator for the followers to follow the leaders in order to efficiently fulfill the passing-through mission. Asymptotic stability conditions are derived to guarantee the feasibility of the developed multi-USV controller. Finally, both numerical simulations and experiments are conducted to show the effectiveness of the proposed multi-USV control strategies.
Related Concept Videos
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:27
Uniform Depth Channel Flow
 02:28
Leaky Scanning
 01:24
Rapidly Varying Flow