Related Experiment Video
Updated: Dec 16, 2025


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Predicting reactive stepping in response to perturbations by using a classification approach
Amber R Emmens1, Edwin H F van Asseldonk2, Vera Prinsen2
1Department of Biomechanical Engineering, University of Twente, Drienerlolaan 5, Enschede, 7522 NB, the Netherlands. a.r.emmens@utwente.nl.

Background:
People use various strategies to maintain balance, such as taking a reactive step or rotating the upper body. To gain insight in human balance control, it is useful to know what makes people switch from one strategy to another. In previous studies the transition from a non-stepping balance response to reactive stepping was often described by an (extended) inverted pendulum model using a limited number of features. The goal of this study is to predict whether people will take a reactive step to recover from a push and to investigate what features are most relevant for that prediction by using a data-driven approach.
Methods:
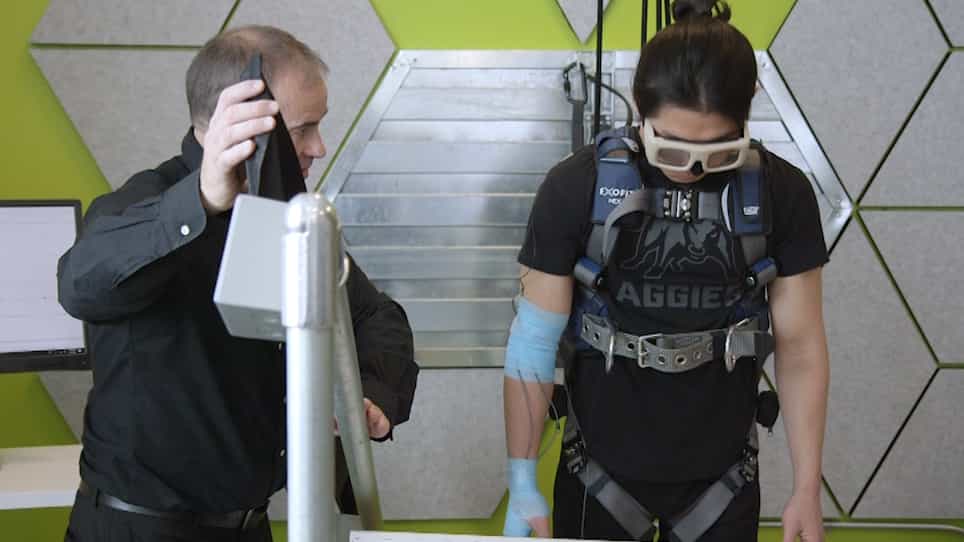
Ten subjects participated in an experiment in which they received forward pushes to which they had to respond naturally with or without stepping. The collected kinematic and center of pressure data were used to train several classification algorithms to predict reactive stepping. The classification algorithms that performed best were used to determine the most important features through recursive feature elimination.
Results:
The neural networks performed better than the other classification algorithms. The prediction accuracy depended on the length of the observation time window: the longer the allowed time between the push and the prediction, the higher the accuracy. Using a neural network with one hidden layer and eight neurons, and a feature set consisting of various kinematic and center of pressure related features, an accuracy of 0.91 was obtained for predictions made up until the moment of step leg unloading, in combination with a sensitivity of 0.79 and a specificity 0.97. The most important features were the acceleration and velocity of the center of mass, and the position of the cervical joint center.
Conclusion:
Using our classification-based method the occurrence of reactive stepping could be predicted with a high accuracy, higher than previous methods for predicting natural reactive stepping. The feature set used for that prediction was different from the ones reported in other step prediction studies. Given the high step prediction performance, our method has the potential to be used for triggering reactive stepping in balance controllers of bipedal robots (e.g. exoskeletons).
Related Concept Videos
 01:24
Transient and Steady-state Response
These test signals are integral in designing control systems to exhibit two key performance aspects: transient response and steady-state...
 01:18
Second Order systems II
 01:18
Steps in Outbreak Investigation
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:01
Classification of Titrimetric Analysis Based on Reaction Types
Titrations between an acid and a base lead to neutralization reactions that form...
 02:24
Predicting Reaction Outcomes