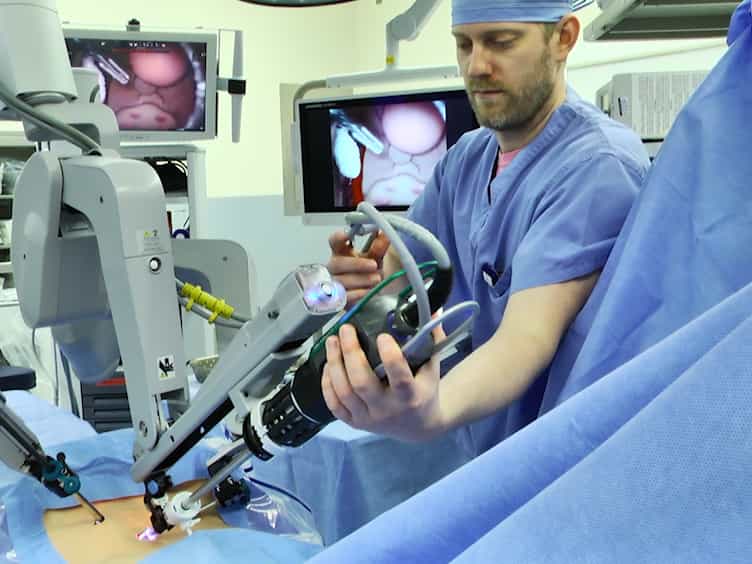
A methodology for Dynamic Human Reliability Analysis in Robotic Surgery
Related Experiment Video
Updated: Dec 14, 2025
A Teleoperated Robotic System-Assisted Percutaneous Transiliac-Transsacral Screw Fixation Technique
Published on: January 6, 2023
Rossella Onofrio1, Paolo Trucco1
1Department of Management, Economics and Industrial Engineering - Politecnico di Milano, Via Lambruschini, 4/b - 20156, Milan, Italy.

Abstract:
Surgery has changed significantly in recent years due to the introduction of advanced technologies, resulting in increased system complexity at the technical, human and organisational levels, which may lead to higher variability of patient outcome due to new error pathways. Current approaches towards a safer surgery are largely based on ex-post analysis of events and process monitoring (e.g. root cause analysis, safety checklists, safety audits). However, adopting a proactive approach enables the prior identification of critical factors and the design of safer sociotechnical systems, thanks to a multi-level (or mesoergnomics) perspective. In this paper, a methodology for performing mesoergonomics analysis of surgical procedures is proposed. It is a methodology for Dynamic Human Reliability Analysis in Robotic Surgery based on a modified version of human error assessment and reduction technique (HEART) integrated with a method for incorporating uncertainties related to the influence of personal and organisational factors on the execution of a surgical procedure. The pilot application involves a robot-assisted radical prostatectomy procedure, and the results reveal that team-related factors have the greatest impact on patient outcome variability.