A Rapid and Adaptive Alignment under Mooring Condition Using Adaptive EKF and CNN-Based Learning

Jong Nam Lim1, Chan Gook Park1
1Department of Aerospace Engineering, Seoul National University, Seoul 08826, Korea.

Abstract:
Alignment of the inertial navigation system (INS) in the mooring environment should take into account the movements of the waves or wind. The alignment of the INS is performed through an extended Kalman filter (EKF) using zero velocity as a measurement. However, in the mooring condition, this is not perfect stationary, thus the measurement error covariance matrix should be adjusted. In addition, if the measurement error covariance matrix is fixed to one value, the alignment time may take longer or the performance may be reduced depending on the change in mooring conditions. To solve this problem, we propose an alignment method using adaptive Kalman filter and convolution neural network (CNN)-based learning. The proposed method was verified for the superiority of alignment time and accuracy through Monte Carlo simulation in a mooring environment.
More Related Videos
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:11
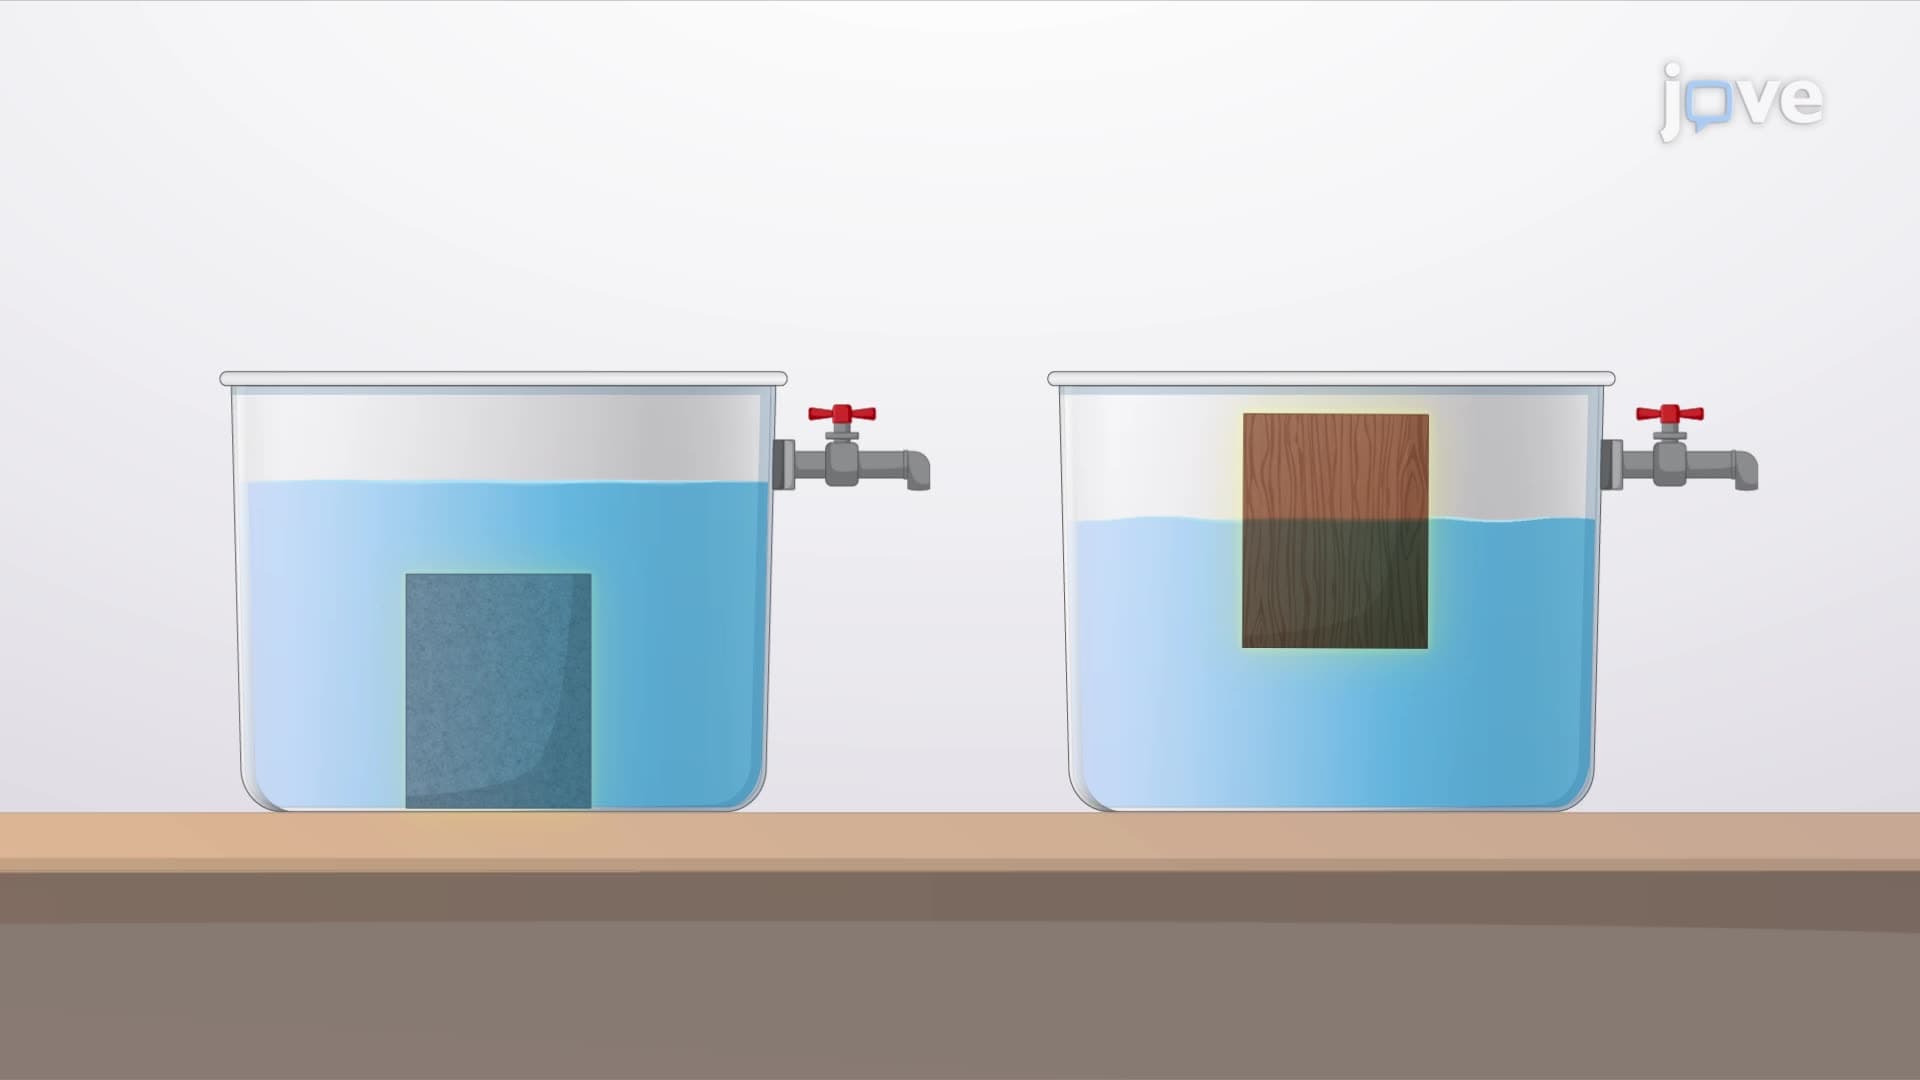
Buoyancy and Stability for Submerged and Floating Bodies
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:10
Relative Motion Analysis - Acceleration