An Origami Continuum Robot Capable of Precise Motion Through Torsionally Stiff Body and Smooth Inverse Kinematics
Related Experiment Video
Updated: Dec 13, 2025
Folding and Characterization of a Bio-responsive Robot from DNA Origami
Published on: December 3, 2015
Junius Santoso1, Cagdas D Onal1,2
1Robotics Engineering Program, Worcester Polytechnic Institute, Worcester, Massachusetts, USA.

Abstract:
Continuum robot arms, with their hyper-redundant continuously deformable bodies, show great promise in applications deemed impossible for traditional rigid robot arms with discrete links and joints, such as navigating tight corners without getting stuck. However, existing continuum robots suffer from excessive twisting when subjected to offset loading, even resulting from their own body weight, which reduces their dexterity and precision. In this work, we present a continuum manipulator that is capable of providing passive torsional stiffness through an origami-inspired modular design, remedying the non-controllable twist typically present in continuum robots. Our proposed origami continuum module is ∼73 times stronger in torsion compared with similar-size continuum modules made out of silicone rubber, while being 50% lighter, and capable of 125% change in length. Building on these physical capabilities, we present an optimization-based method to solve for the inverse kinematics of our multi-segment origami continuum manipulator that ensures smooth motion to follow desired end-effector paths, minimizing vibrations of the long and slender body. Further, taking advantage of the length-change capabilities of our origami manipulator, we devise and evaluate grow-to-shape algorithms to plan for full-body robot insertion motions that follow tortuous paths. Lastly, we showcase various applications of our proposed continuum robot for pick-and-place, inspection/exploration, and robotic art. Our study presents a highly capable continuum robot for safe manipulation and structure inspection applications, with potential for real-world deployment.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:09
Torsional Pendulum
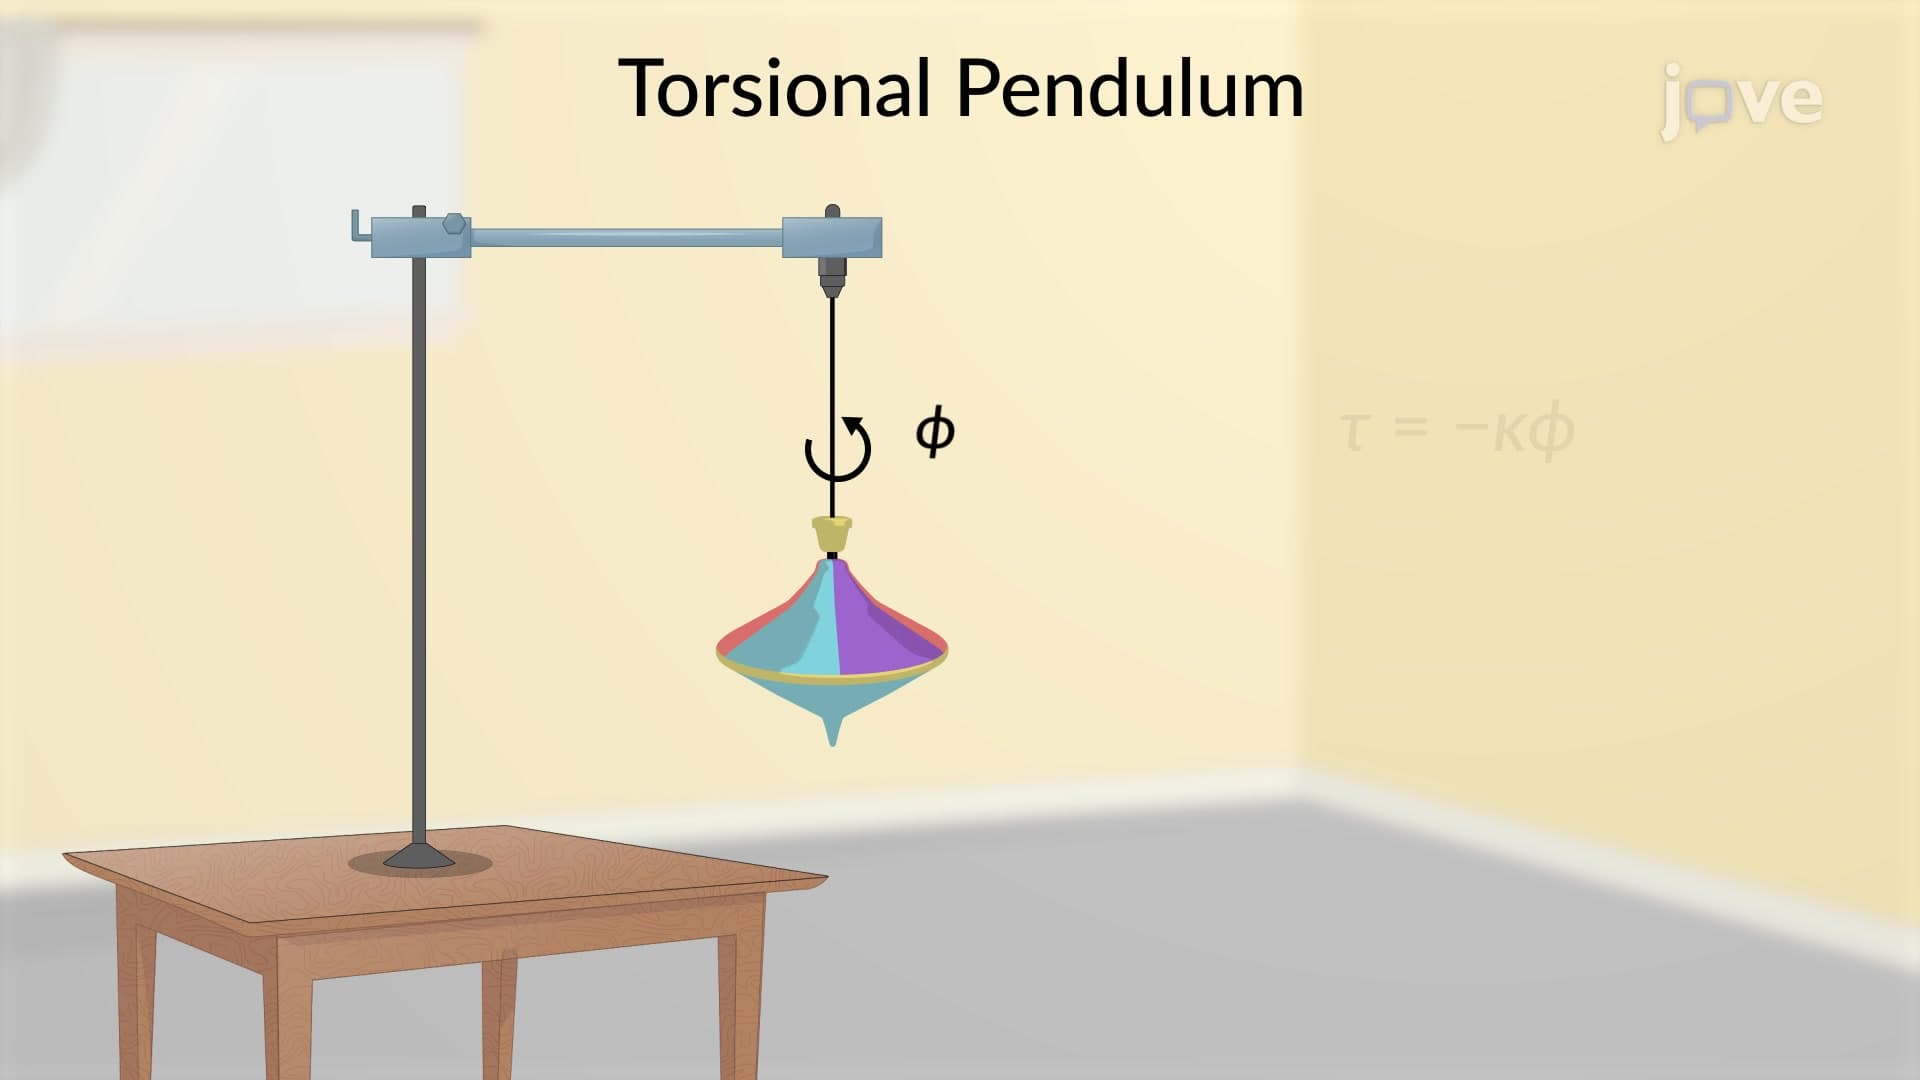
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:15
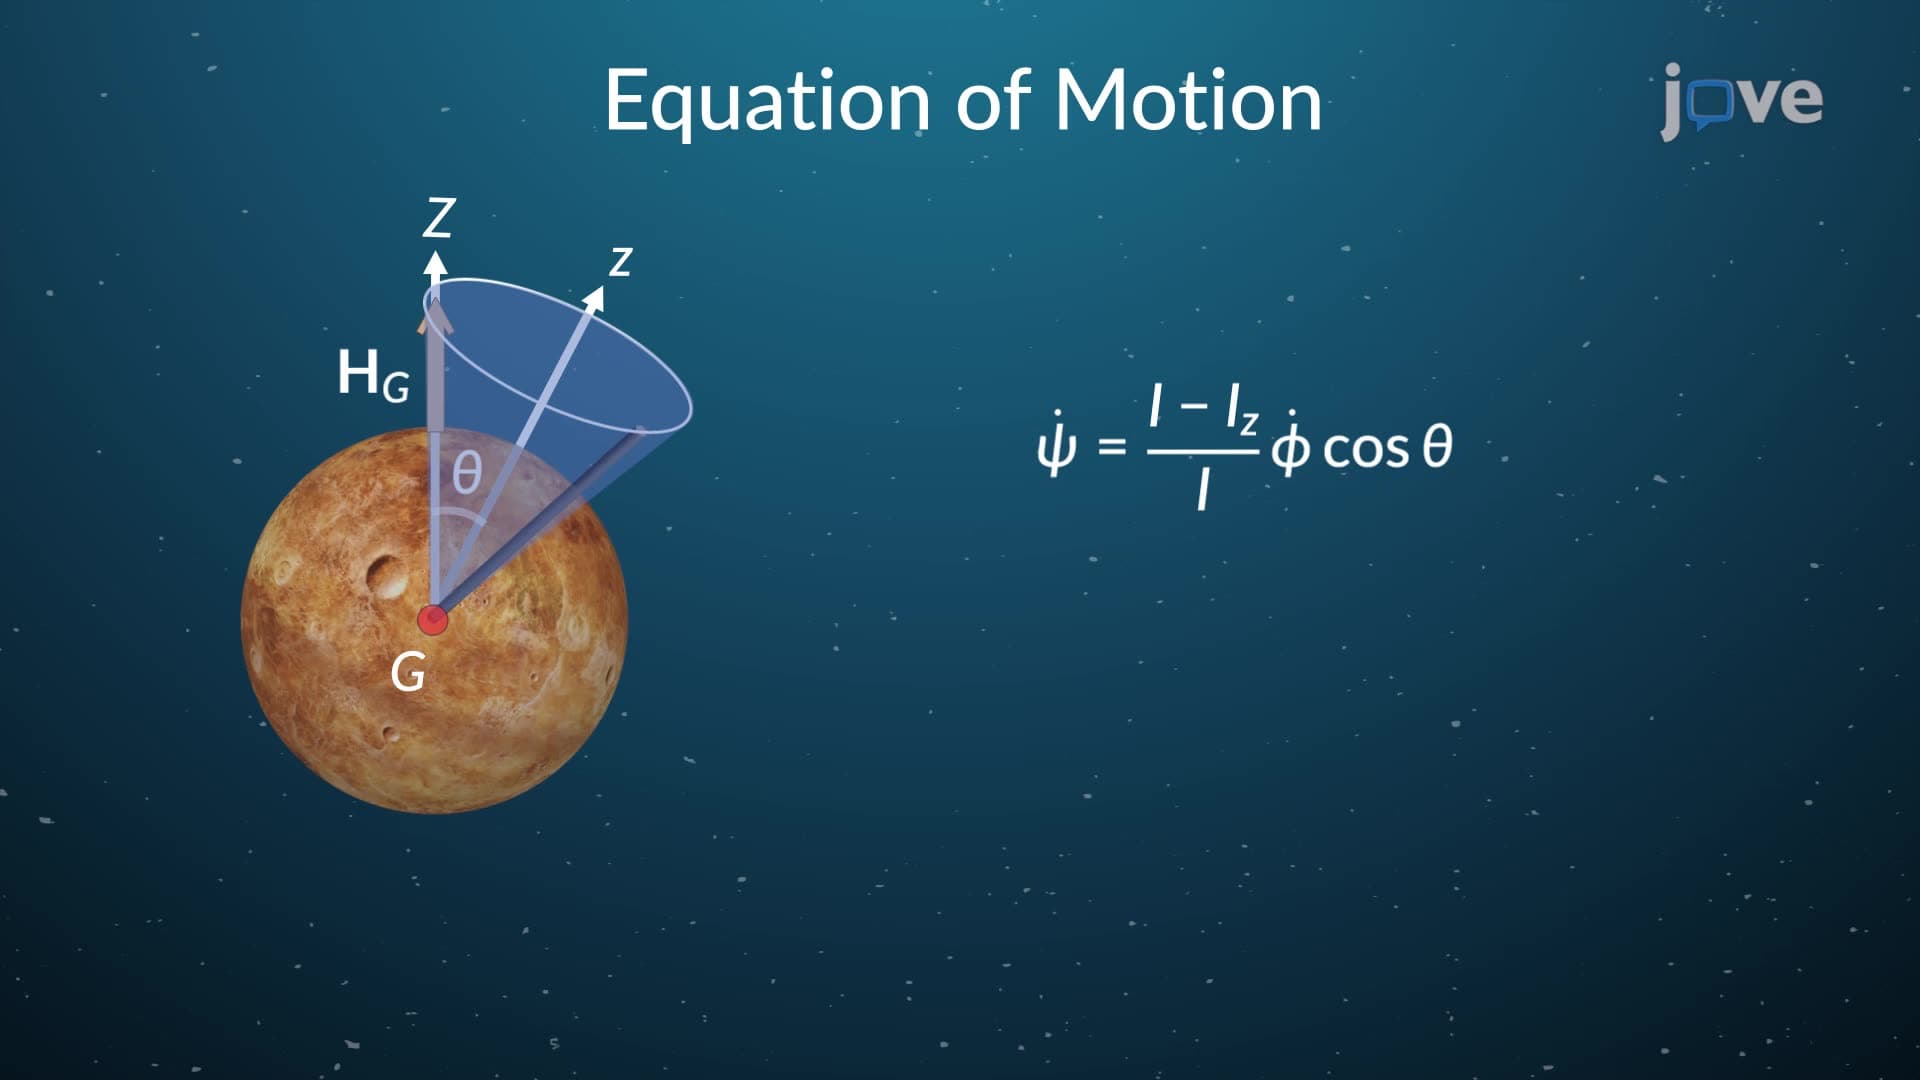
Torque Free Motion
 01:26
Rotational Motion about a Fixed Axis
 01:11
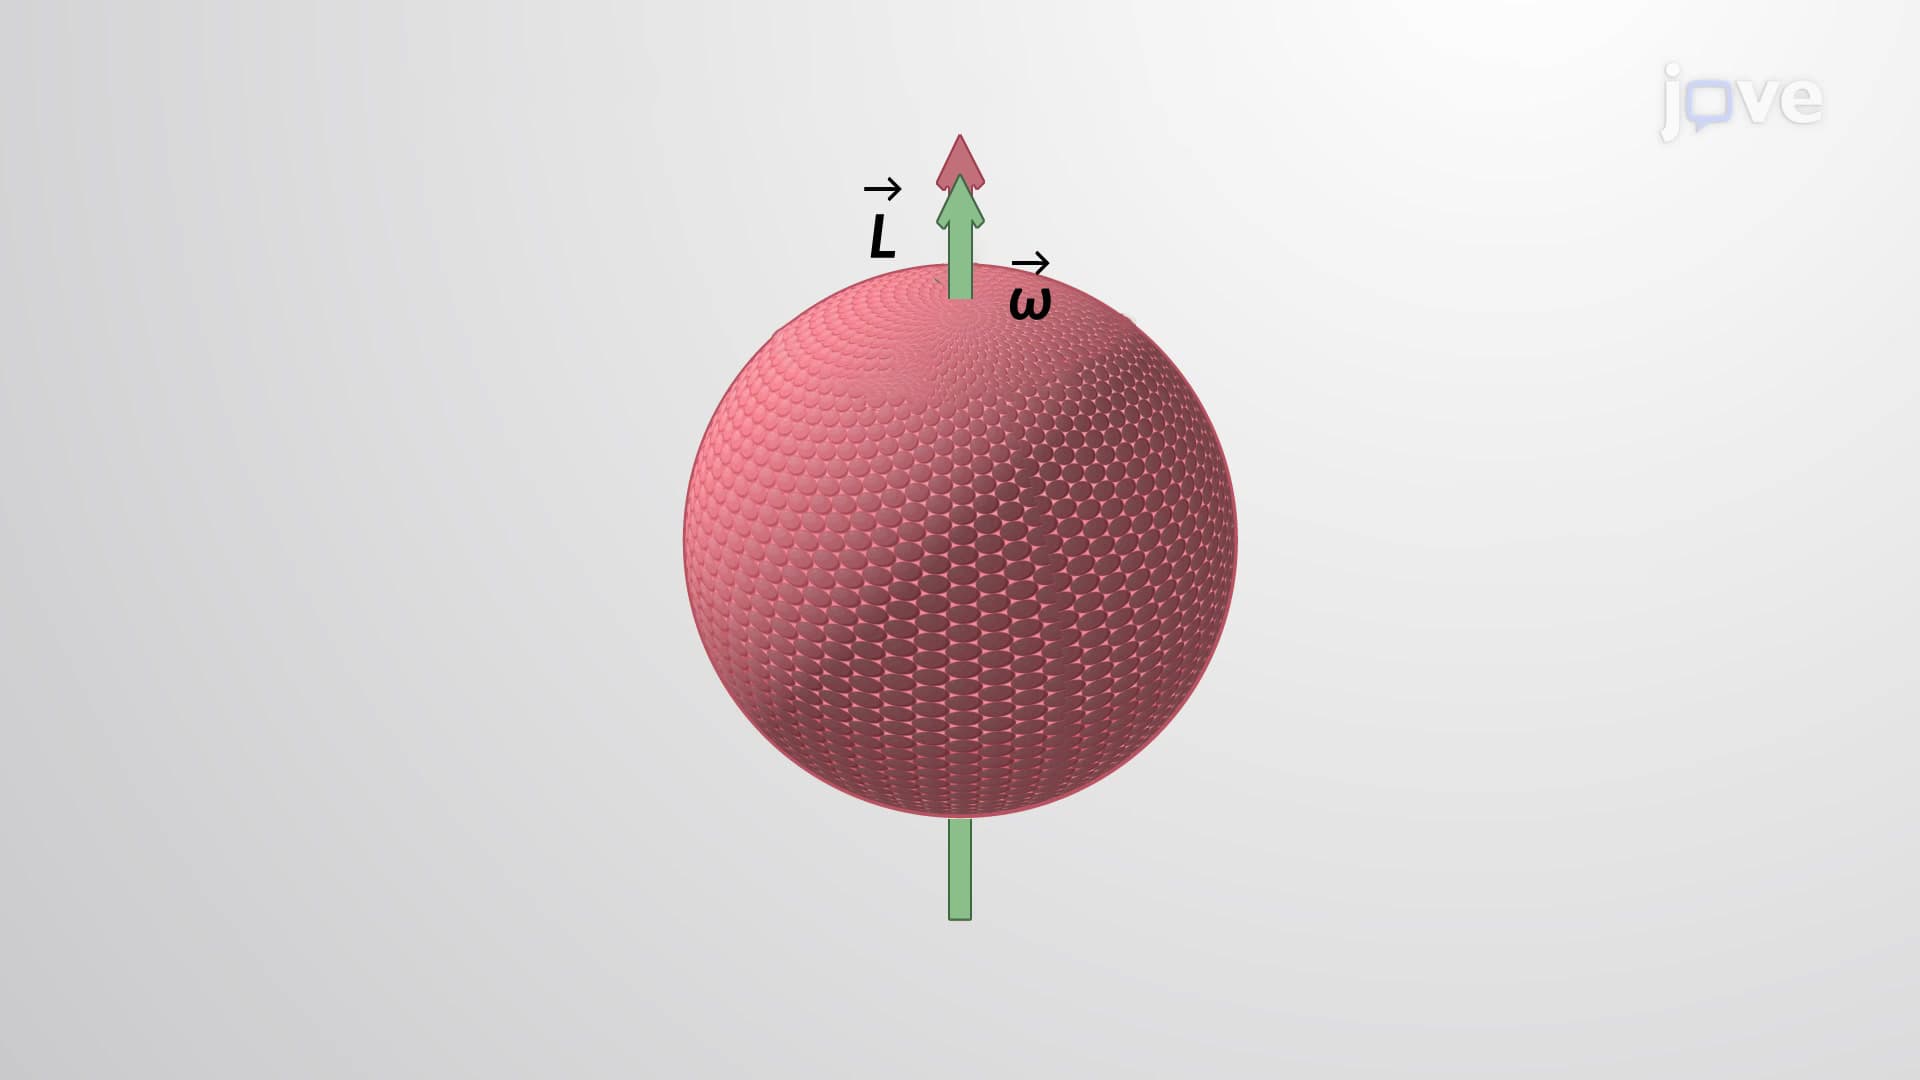
Angular Momentum: Rigid Body
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...