Related Experiment Video
Updated: Dec 10, 2025
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy iPALM
Published on: December 1, 2016
Deep Face Rectification for 360° Dual-Fisheye Cameras

Abstract:
Rectilinear face recognition models suffer from severe performance degradation when applied to fisheye images captured by 360° back-to-back dual fisheye cameras. We propose a novel face rectification method to combat the effect of fisheye image distortion on face recognition. The method consists of a classification network and a restoration network specifically designed to handle the non-linear property of fisheye projection. The classification network classifies an input fisheye image according to its distortion level. The restoration network takes a distorted image as input and restores the rectilinear geometric structure of the face. The performance of the proposed method is tested on an end-to-end face recognition system constructed by integrating the proposed rectification method with a conventional rectilinear face recognition system. The face verification accuracy of the integrated system is 99.18% when tested on images in the synthetic Labeled Faces in the Wild (LFW) dataset and 95.70% for images in a real image dataset, resulting in an average accuracy improvement of 6.57% over the conventional face recognition system. For face identification, the average improvement over the conventional face recognition system is 4.51%.
Related Concept Videos
 01:23
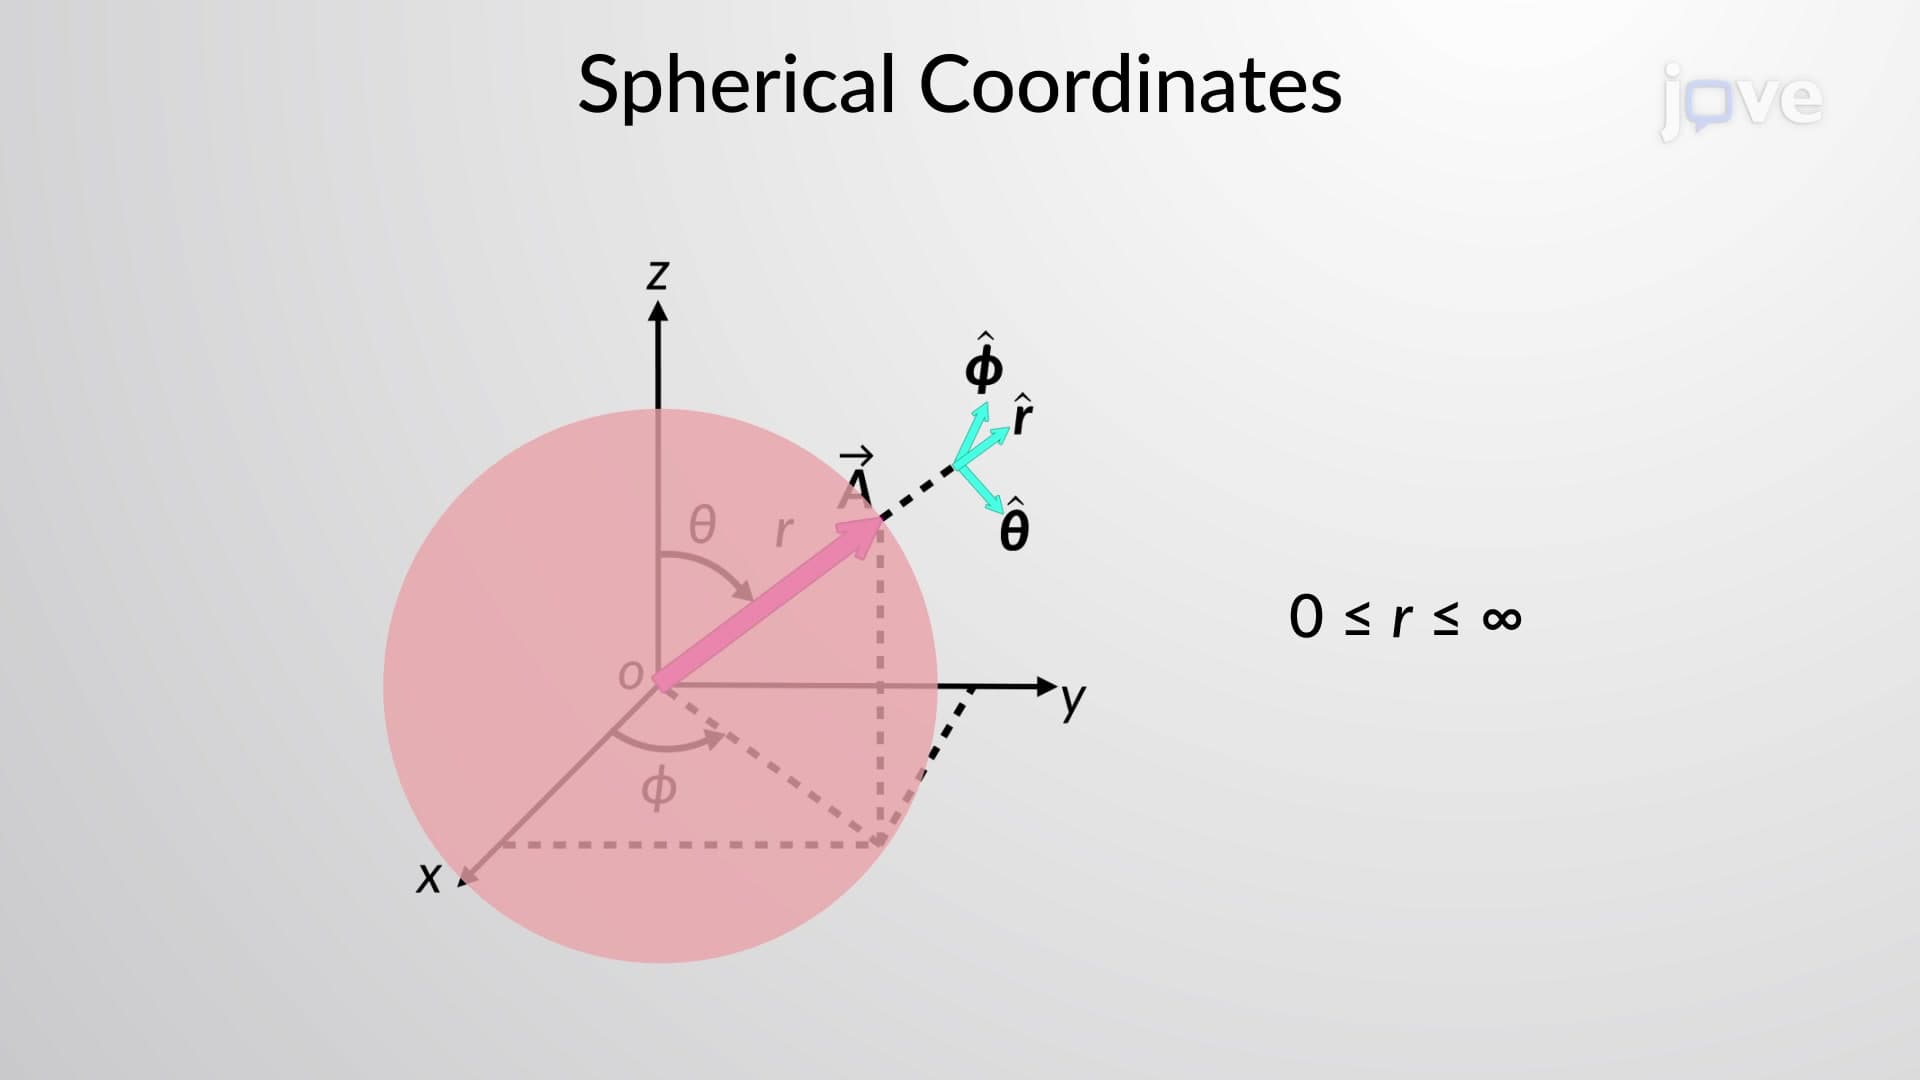
Spherical Coordinates
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:15
Distance Corrections
 01:15
Depth Perception and Spatial Vision
 01:20
Deconvolution
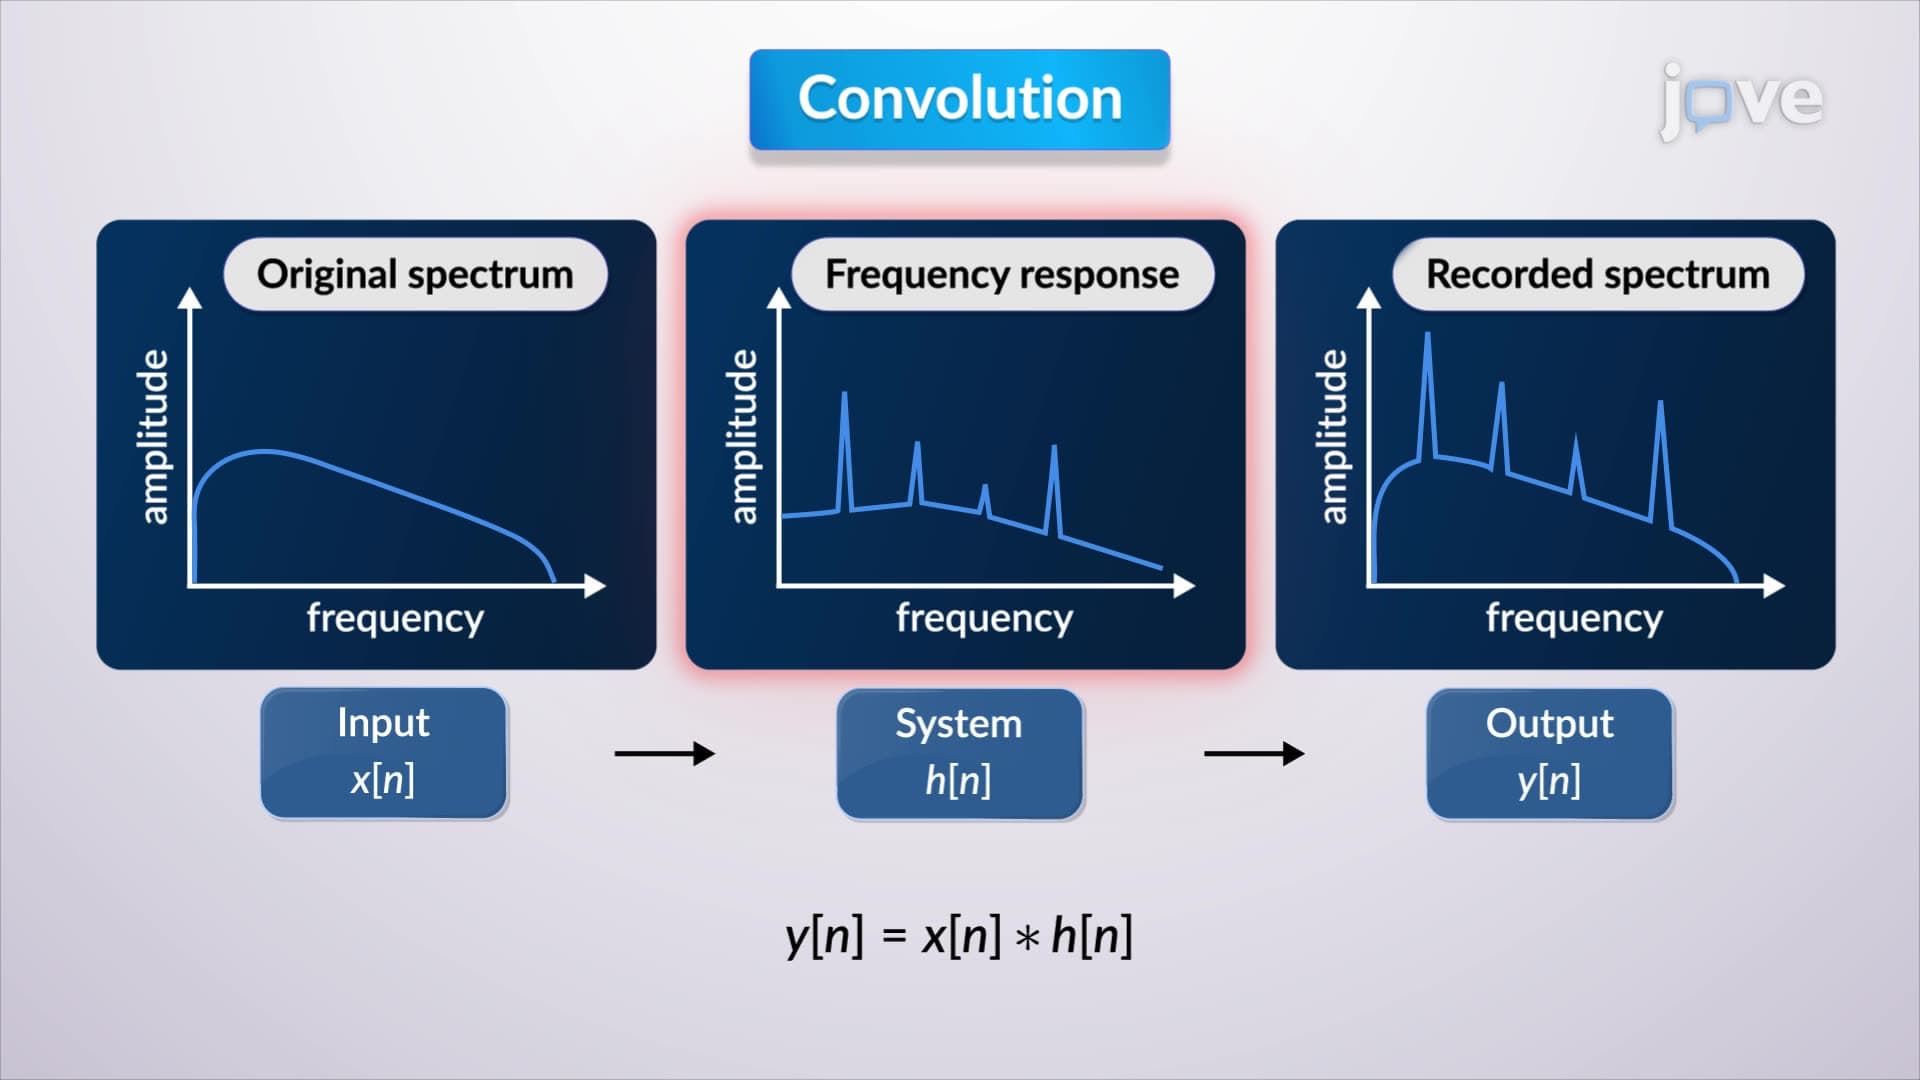
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...