Related Experiment Video
Updated: Dec 9, 2025
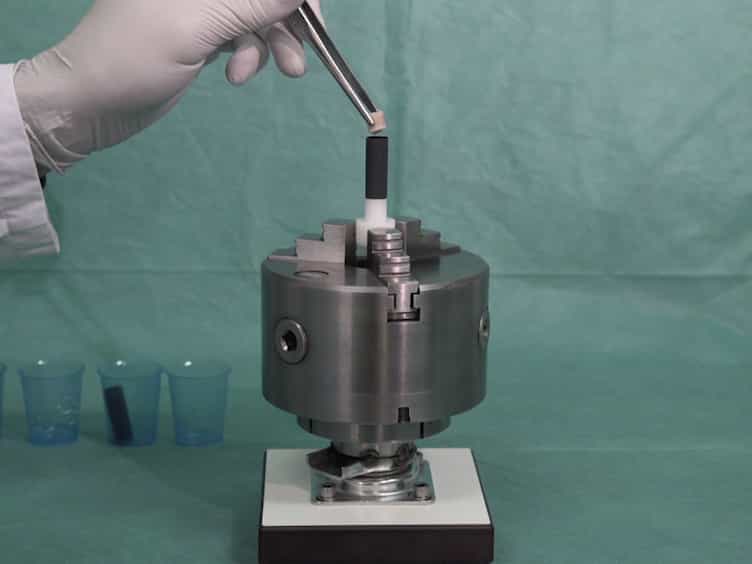

An Experimental and Finite Element Protocol to Investigate the Transport of Neutral and Charged Solutes across Articular Cartilage
Published on: April 23, 2017
Nonstandard finite difference method for solving complex-order fractional Burgers' equations
N H Sweilam1, S M Al-Mekhlafi2, D Baleanu3,4
1Department of Mathematics, Faculty of Science, Cairo University, Giza, Egypt.

Abstract:
The aim of this work is to present numerical treatments to a complex order fractional nonlinear one-dimensional problem of Burgers' equations. A new parameter is presented in order to be consistent with the physical model problem. This parameter characterizes the existence of fractional structures in the equations. A relation between the parameter and the time derivative complex order is derived. An unconditionally stable numerical scheme using a kind of weighted average nonstandard finite-difference discretization is presented. Stability analysis of this method is studied. Numerical simulations are given to confirm the reliability of the proposed method.
More Related Videos

Related Concept Videos
 01:28
Partial Fractions
 01:24
Difference Equation Solution using z-Transform
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:18
Second Order systems II
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:19
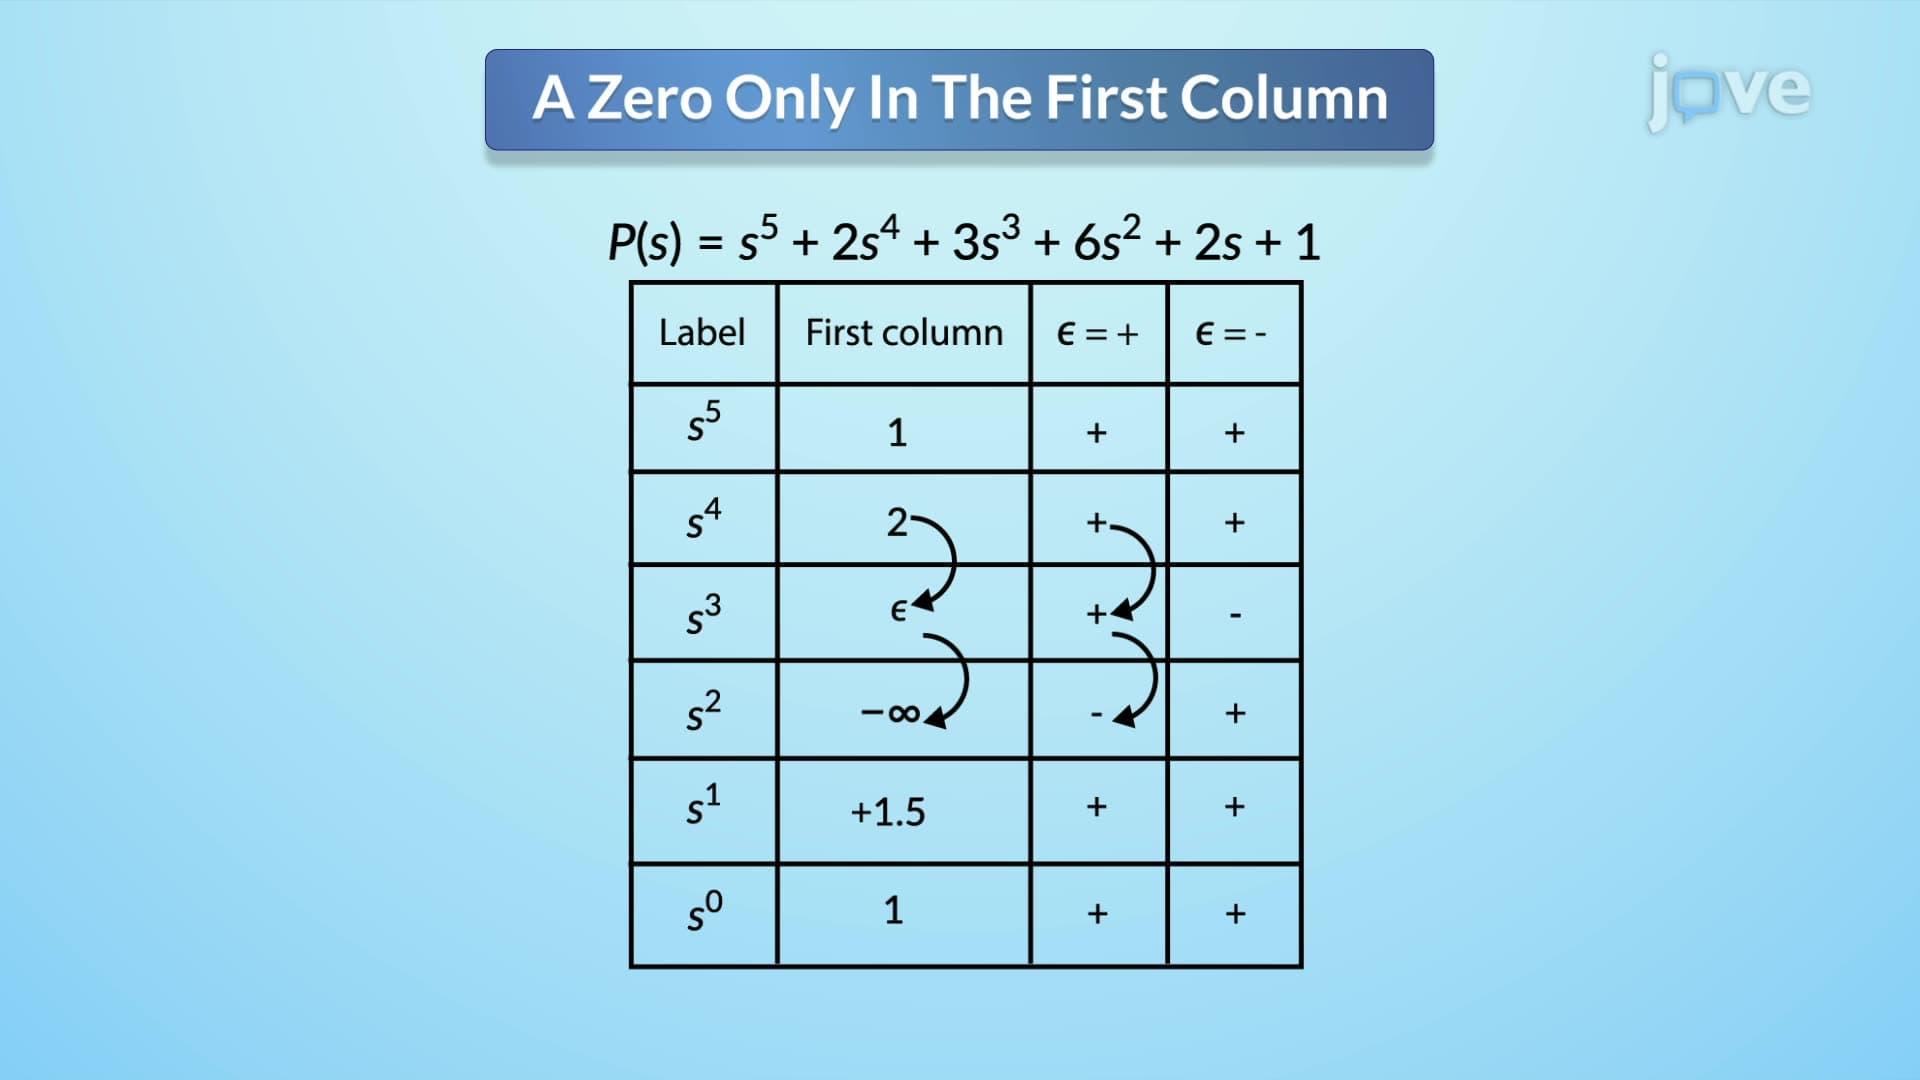
Routh-Hurwitz Criterion II
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...