Related Experiment Video
Updated: Dec 9, 2025


Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Event-based fractional order control
Isabela Birs1,2,3, Ioan Nascu1, Clara Ionescu2,3
1Technical University of Cluj-Napoca, Automation Department, Memorandumului 28, Cluj-Napoca, Romania.

Abstract:
The present study provides a generalization of event-based control to the field of fractional calculus, combining the benefits brought by the two approaches into an industrial-suitable control strategy. During recent years, control applications based on fractional order differintegral operators have gained more popularity due to their proven superior performance when compared to classical, integer order, control strategies. However, the current industrial setting is not yet prepared to fully adapt to complex fractional order control implementations that require hefty computational resources; needing highly-efficient methods with minimum control effort. The solution to this particular problem lies in combining benefits of event-based control such as resource optimization and bandwidth allocation with the superior performance of fractional order control. Theoretical and implementation aspects are developed in order to provide a generalization of event-based control into the fractional calculus field. Different numerical examples validate the proposed methodology, providing a useful tool, especially for industrial applications where the event-based control is most needed. Several event-based fractional order implementation possibilities are explored, the final result being an event-based fractional order control methodology.


Related Concept Videos
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:28
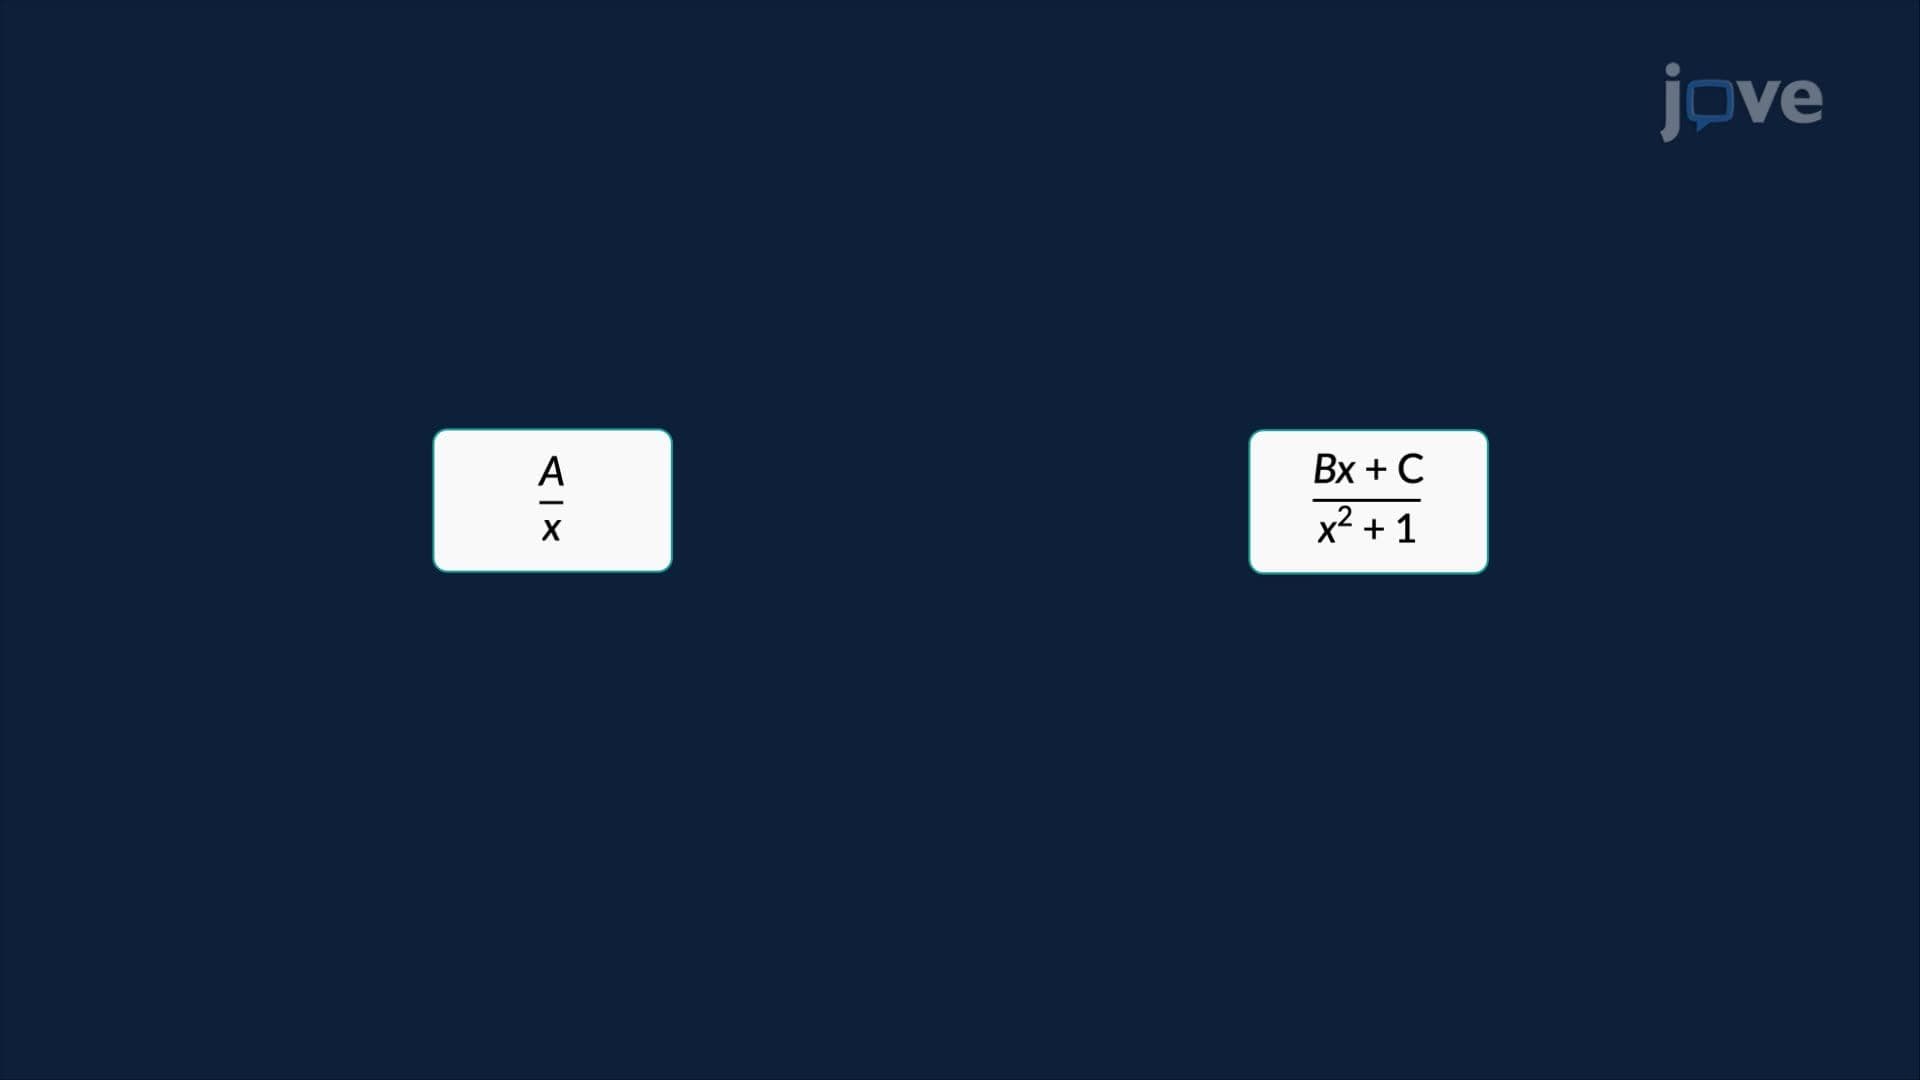
Partial Fractions
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
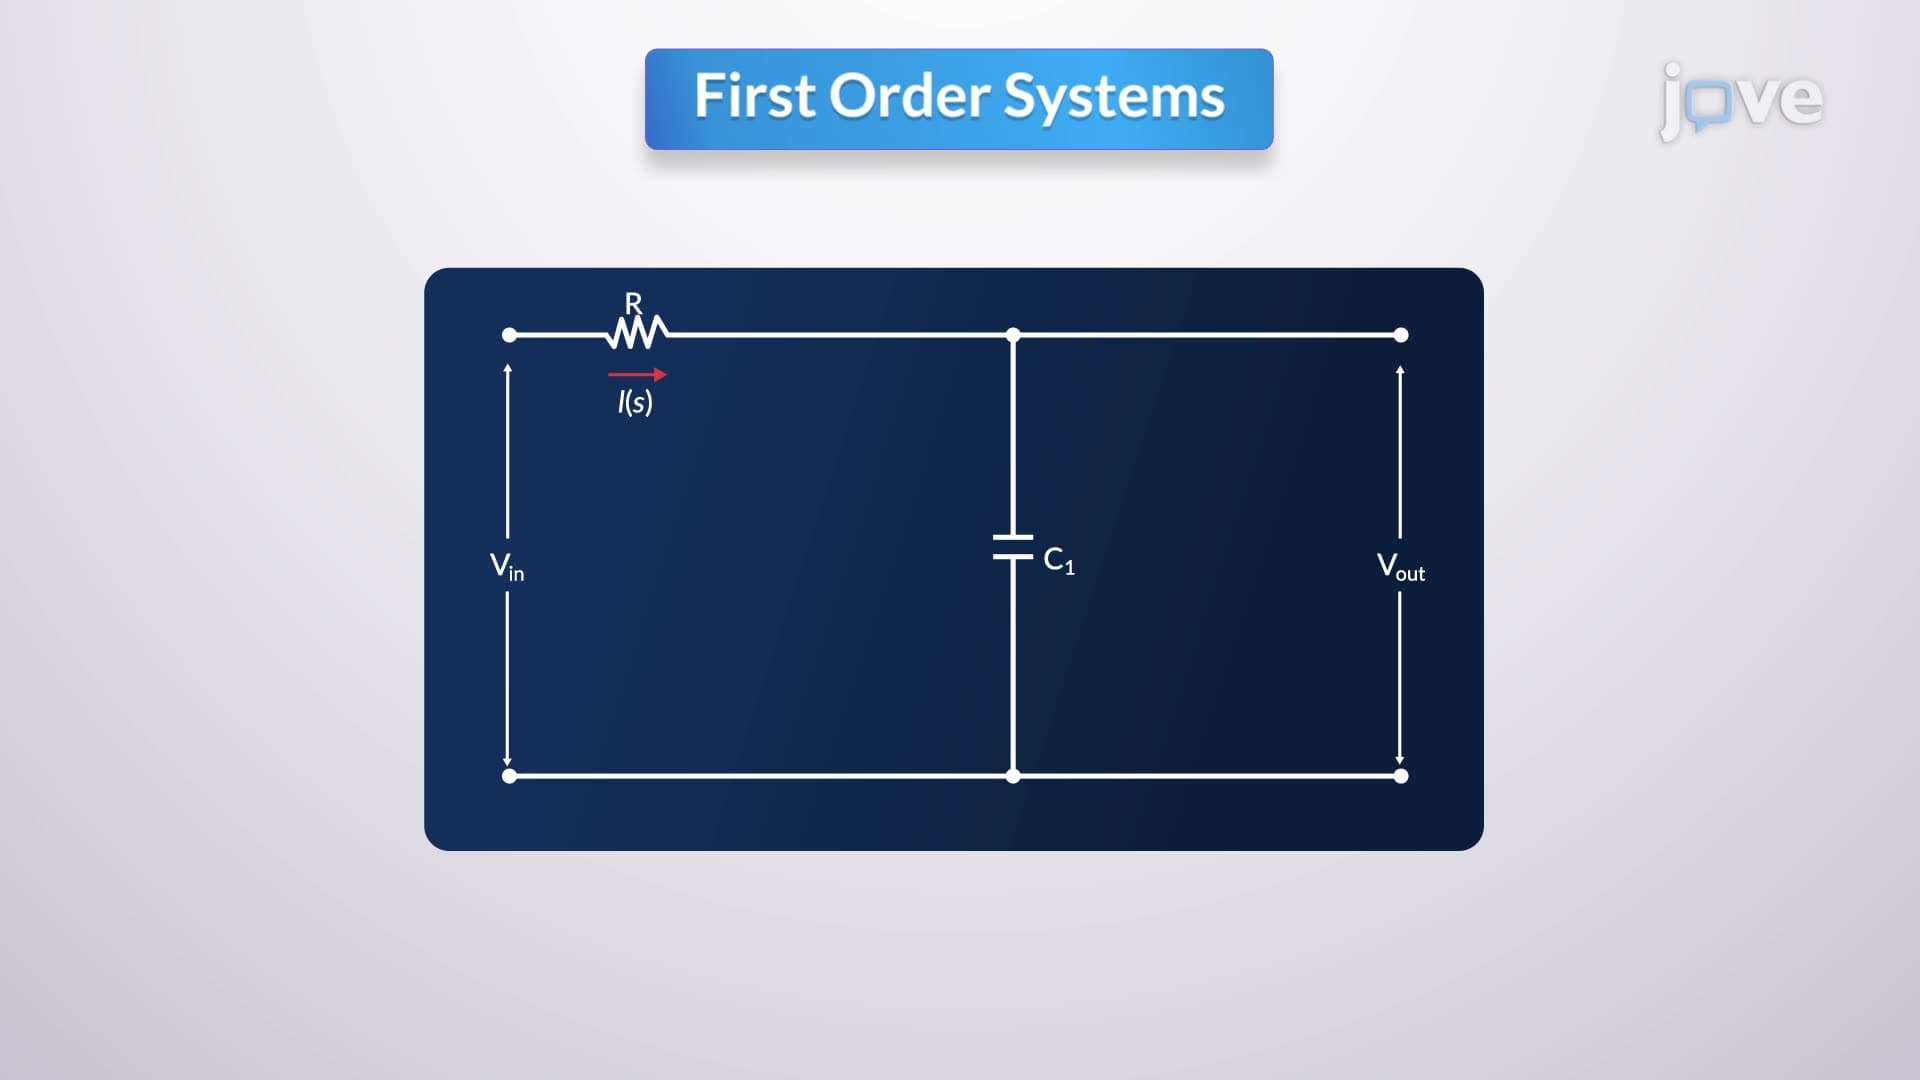
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...