Optimal averaging time for improving observer accuracy of stochastic dynamical systems

Pedro Balaguer1, Asier Ibeas2

  • 1Jaume I University, Castellón, Spain.

ISA Transactions
|September 19, 2020
PubMed

Related Concept Videos

Linear time-invariant Systems01:23

Linear time-invariant Systems

A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
730
Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
237
BIBO stability of continuous and discrete -time systems01:24

BIBO stability of continuous and discrete -time systems

System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
796
Second Order systems II01:18

Second Order systems II

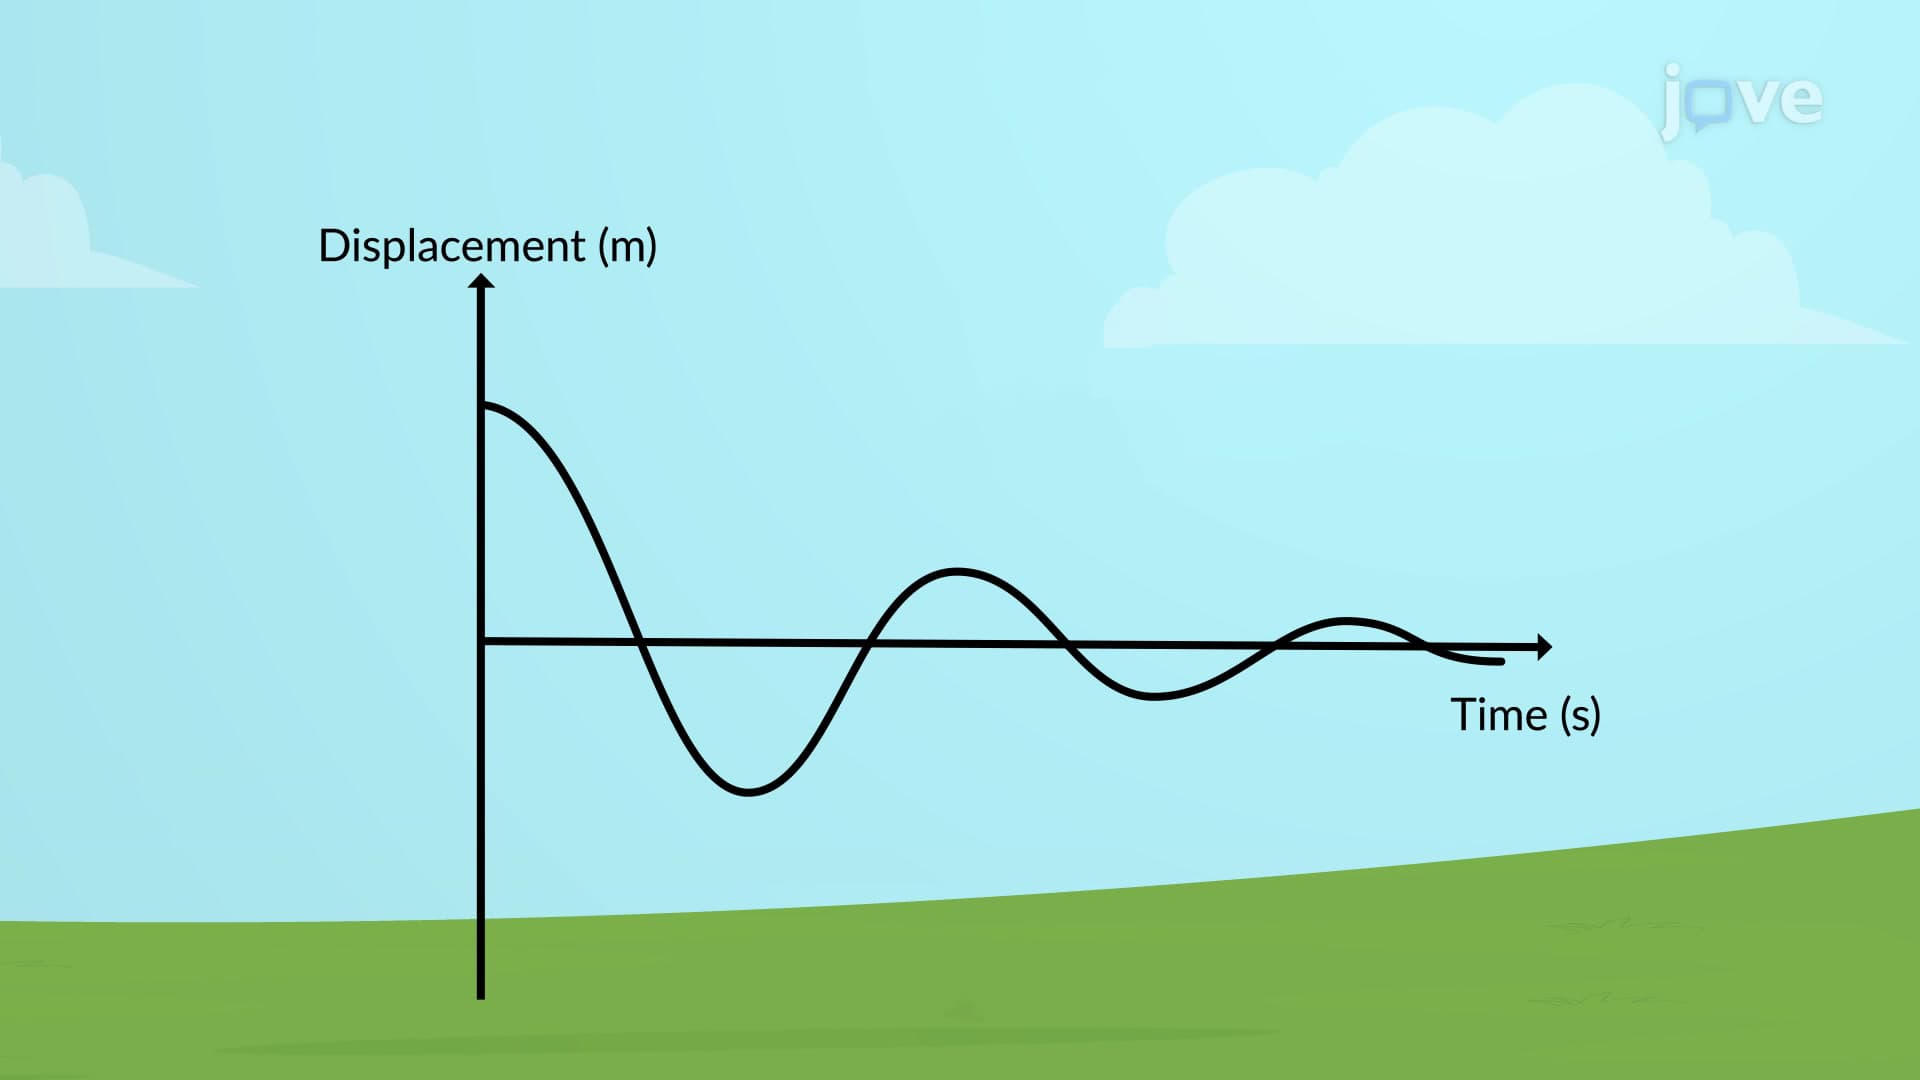
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
297
Propagation of Uncertainty from Systematic Error01:10

Propagation of Uncertainty from Systematic Error
The atomic mass of an element varies due to the relative ratio of its isotopes. A sample's relative proportion of oxygen isotopes influences its average atomic mass. For instance, if we were to measure the atomic mass of oxygen from a sample, the mass would be a weighted average of the isotopic masses of oxygen in that sample. Since a single sample is not likely to perfectly reflect the true atomic mass of oxygen for all the molecules of oxygen on Earth, the mass we obtain from this...
1.2K
Types of Damping01:20

Types of Damping

If the amount of damping in a system is gradually increased, the period and frequency start to become affected because damping opposes, and hence slows, the back and forth motion (the net force is smaller in both directions). If there is a very large amount of damping, the system does not even oscillate; instead, it slowly moves toward equilibrium. In brief, an overdamped system moves slowly towards equilibrium, whereas an underdamped system moves quickly to equilibrium but will oscillate about...
7.3K