Related Experiment Video
Updated: Dec 7, 2025


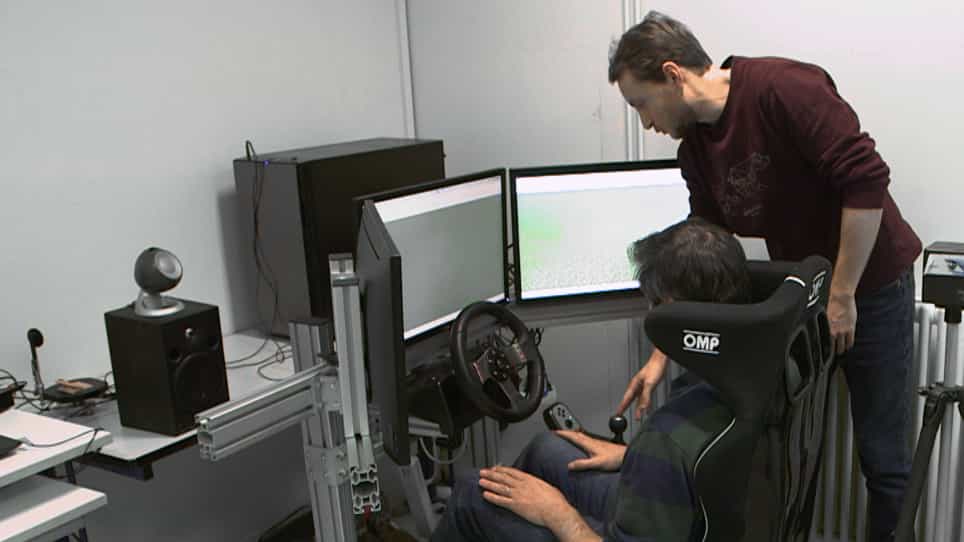
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Human-like driving behaviour emerges from a risk-based driver model
Sarvesh Kolekar1, Joost de Winter2, David Abbink2
1Department of Cognitive Robotics, Faculty of Mechanical, Maritime and Materials Engineering (3mE), Delft University of Technology, Mekelweg 2, 2628 CD, Delft, The Netherlands. s.b.kolekar@tudelft.nl.

Abstract:
Current driving behaviour models are designed for specific scenarios, such as curve driving, obstacle avoidance, car-following, or overtaking. However, humans can drive in diverse scenarios. Can we find an underlying principle from which driving behaviour in different scenarios emerges? We propose the Driver's Risk Field (DRF), a two-dimensional field that represents the driver's belief about the probability of an event occurring. The DRF, when multiplied with the consequence of the event, provides an estimate of the driver's perceived risk. Through human-in-the-loop and computer simulations, we show that human-like driving behaviour emerges when the DRF is coupled to a controller that maintains the perceived risk below a threshold-level. The DRF model predictions concur with driving behaviour reported in literature for seven different scenarios (curve radii, lane widths, obstacle avoidance, roadside furniture, car-following, overtaking, oncoming traffic). We conclude that our generalizable DRF model is scientifically satisfying and has applications in automated vehicles.
More Related Videos
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:27
Drive-Reduction Theory: Push Theory of Motivation
 01:25
Models of Health Promotion and Illness Prevention I
The health belief model (HBM) attempts to predict health-related behavior in specific belief patterns. According to the HBM, a person's...
 02:16
Stereotype Content Model
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...