Related Experiment Video
Updated: Dec 6, 2025
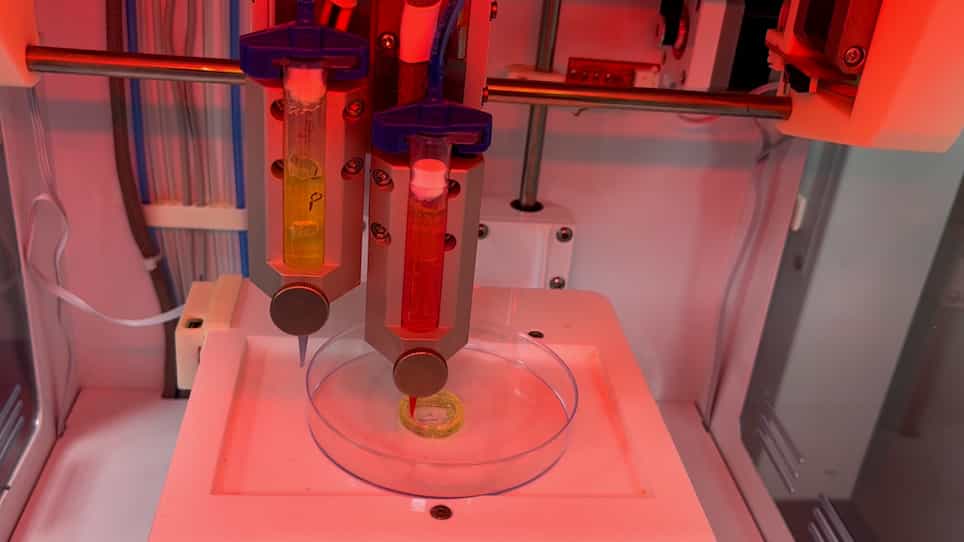

Four-Dimensional Printing of Stimuli-Responsive Hydrogel-Based Soft Robots
Published on: January 13, 2023
Autonomic perspiration in 3D-printed hydrogel actuators
Anand K Mishra1, Thomas J Wallin2,3, Wenyang Pan3
1Department of Mechanical and Aerospace Engineering, Cornell University, Ithaca, NY 14850, USA.

Abstract:
In both biological and engineered systems, functioning at peak power output for prolonged periods of time requires thermoregulation. Here, we report a soft hydrogel-based actuator that can maintain stable body temperatures via autonomic perspiration. Using multimaterial stereolithography, we three-dimensionally print finger-like fluidic elastomer actuators having a poly-N-isopropylacrylamide (PNIPAm) body capped with a microporous (~200 micrometers) polyacrylamide (PAAm) dorsal layer. The chemomechanical response of these hydrogel materials is such that, at low temperatures (<30°C), the pores are sufficiently closed to allow for pressurization and actuation, whereas at elevated temperatures (>30°C), the pores dilate to enable localized perspiration in the hydraulic actuator. Such sweating actuators exhibit a 600% enhancement in cooling rate (i.e., 39.1°C minute-1) over similar non-sweating devices. Combining multiple finger actuators into a single device yields soft robotic grippers capable of both mechanically and thermally manipulating various heated objects. The measured thermoregulatory performance of these sweating actuators (~107 watts kilogram-1) greatly exceeds the evaporative cooling capacity found in the best animal systems (~35 watts kilogram-1) at the cost of a temporary decrease in actuation efficiency.
More Related Videos
 08:17
An Additive Manufacturing Technique for the Facile and Rapid Fabrication of Hydrogel-based Micromachines with Magnetically Responsive Components
Published on: July 18, 2018
 05:32
3D Printing of In Vitro Hydrogel Microcarriers by Alternating Viscous-Inertial Force Jetting
Published on: April 21, 2021