Bioinspired soft enteroscopic robot for intestinal locomotion, steering, and intervention
Related Experiment Video
Updated: Oct 30, 2026
Bioinspired Soft Robot with Incorporated Microelectrodes
Published on: February 28, 2020
Binbin Ying1,2,3,4,5,6, Ahmad Mujtaba Jebran1, Sahab Babaee1,2,3
1Department of Mechanical Engineering, Massachusetts Institute of Technology, Cambridge, MA, USA.

Abstract:
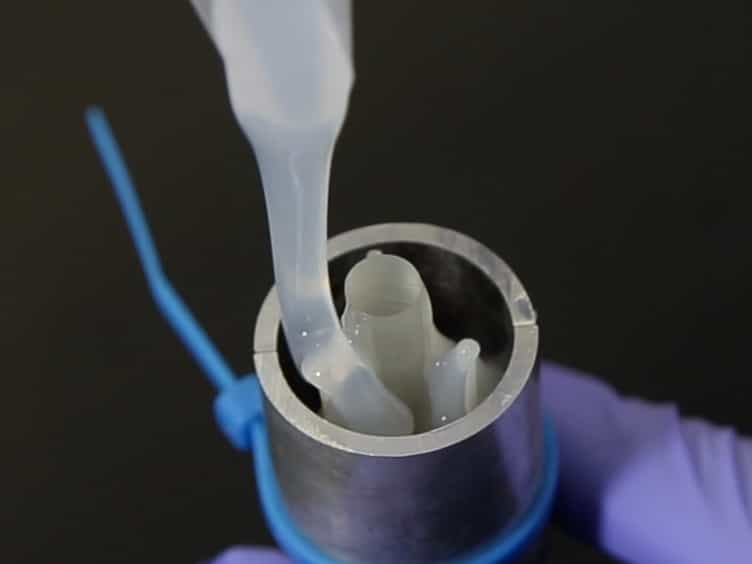
Diagnosing and treating small intestinal disorders such as bleeding, inflammatory bowel disease, and tumors present challenges because of limited access to this anatomical compartment. We present BIOSENTER, a bioinspired soft enteroscopic robot for deep procedures in the small intestine that addresses locomotion, steering, and intervention constraints of existing soft robotic systems. BIOSENTER features a hollow cylinder architecture comprising a linearly deformable soft pneumatic actuator as the body, two radially expandable soft pneumatic actuators wrapped with kirigami sleeves as the head and tail, a central hollow channel for accessory endoscopic tools, and a control box for navigation. Inspired by snake locomotion, the robotic body incorporates a fiber-reinforced actuator with four embedded inflatable chambers, enabling steering and axial expansion. The dynamic kirigami sleeves generate an anchoring force of ∼1.5 newtons on intestinal mucosa while requiring substantially less radial expansion than the corresponding nonkirigami configuration. A reinforced central channel supports tool passage for diagnostic and therapeutic interventions. The control box enables locomotion and steering at autonomous speeds of ∼100 millimeters per minute in vitro and ∼43 millimeters per minute in tissue-covered tubing. BIOSENTER successfully navigated the collapsed, tortuous small intestine for 2 meters in 11 minutes, with gentle forward pushing forces of 2.2 to 6.4 newtons in pig studies. In vivo pig studies demonstrated technical feasibility of tissue biopsy, localized fluid delivery as a model for future drug administration, and real-time visualization of the deep intestine, without macroscopic overdistention or visible tissue damage under the tested conditions.