Leg Locomotion Adaption for Quadruped Robots with Ground Compliance Estimation
Related Experiment Video
Updated: Dec 6, 2025
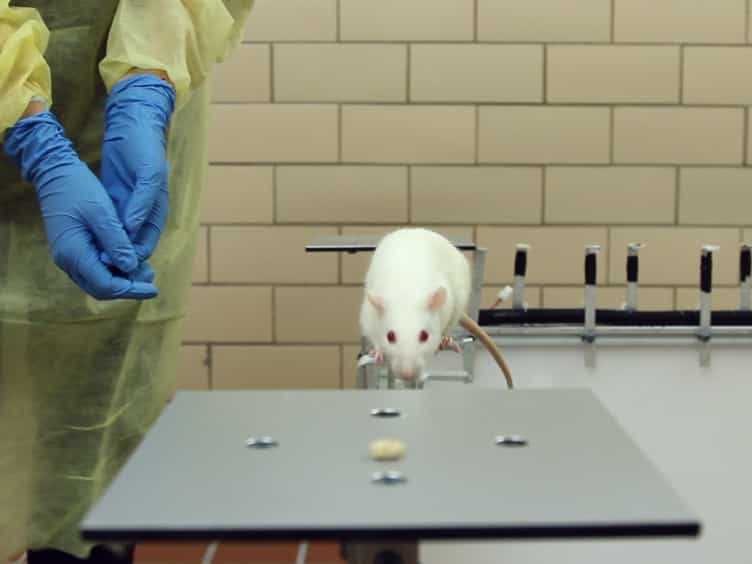
Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
Songyuan Zhang1, Hongji Zhang1, Yili Fu1
1State Key Laboratory of Robotics and System, Harbin Institute of Technology, 150001, China.

Abstract:
Locomotion control for quadruped robots is commonly applied on rigid terrains with modelled contact dynamics. However, the robot traversing different terrains is more important for real application. In this paper, a single-leg prototype and a test platform are built. The Cartesian coordinates of the foot-end are obtained through trajectory planning, and then, the virtual polar coordinates in the impedance control are obtained through geometric transformation. The deviation from the planned and actual virtual polar coordinates and the expected force recognized by the ground compliance identification system are sent to the impedance controller for different compliances. At last, several experiments are carried out for evaluating the performance including the ground compliance identification, the foot-end trajectory control, and the comparison between pure position control and impedance control.