A New Quaternion-Based Kalman Filter for Human Body Motion Tracking Using the Second Estimator of the Optimal Quaternion Algorithm and the Joint Angle Constraint Method with Inertial and Magnetic Sensors
Related Experiment Video
Updated: Dec 3, 2025
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Yingbo Duan1, Xiaoyue Zhang1, Zhibing Li1
1School of Instrumentation and Optoelectronic Engineering, Beihang University, Beijing 100191, China.

Abstract:
Human body motion tracking is a key technique in robotics, virtual reality and other human-computer interaction fields. This paper proposes a novel simple-structure Kalman filter to improve the accuracy of human body motion tracking, named the Second EStimator of the Optimal Quaternion Kalman Filter (E2QKF). The new algorithm is the combination of the Second Estimator of the Optimal Quaternion (ESOQ-2) algorithm, the linear Kalman filter and the joint angle constraint method. In the proposed filter, the ESOQ-2 algorithm is used to produce an observation quaternion by preprocessing accelerometer and magnetometer measurements. The compensation for the accelerometer added in the ESOQ-2 algorithm is to eliminate the influence of human body motion acceleration included in the results. The state vector of the filter is the quaternion, which is calculated with gyroscope measurements, and the Kalman filter is to calculate the optimal quaternion by fusing the state quaternion and the observation quaternion. Therefore, the filter becomes a simple first-order linear system model, which avoids the linearization error of measurement equations and reduces the computational complexity. Furthermore, the joint angle constraint is considered in the proposed algorithm, which makes the results more accurate. To verify the accuracy of the proposed algorithm, inertial/magnetic sensors are used to perform the upper limb motion experiment, and the result of E2QKF (without joint angle constraint) is compared with an optical motion capture system and two traditional methods. Test results demonstrate the effectiveness of the proposed filter: the root mean square error (RMSE) of E2QKF is less than 2.0° and the maximum error is less than 4.6°. The result of E2QKF (with joint angle constraint) is compared with E2QKF (without joint angle constraint). Test results demonstrate the superiority of E2QKF (with joint angle constraint): the joint angle constraint method can further improve the accuracy of human body motion tracking.

Related Concept Videos
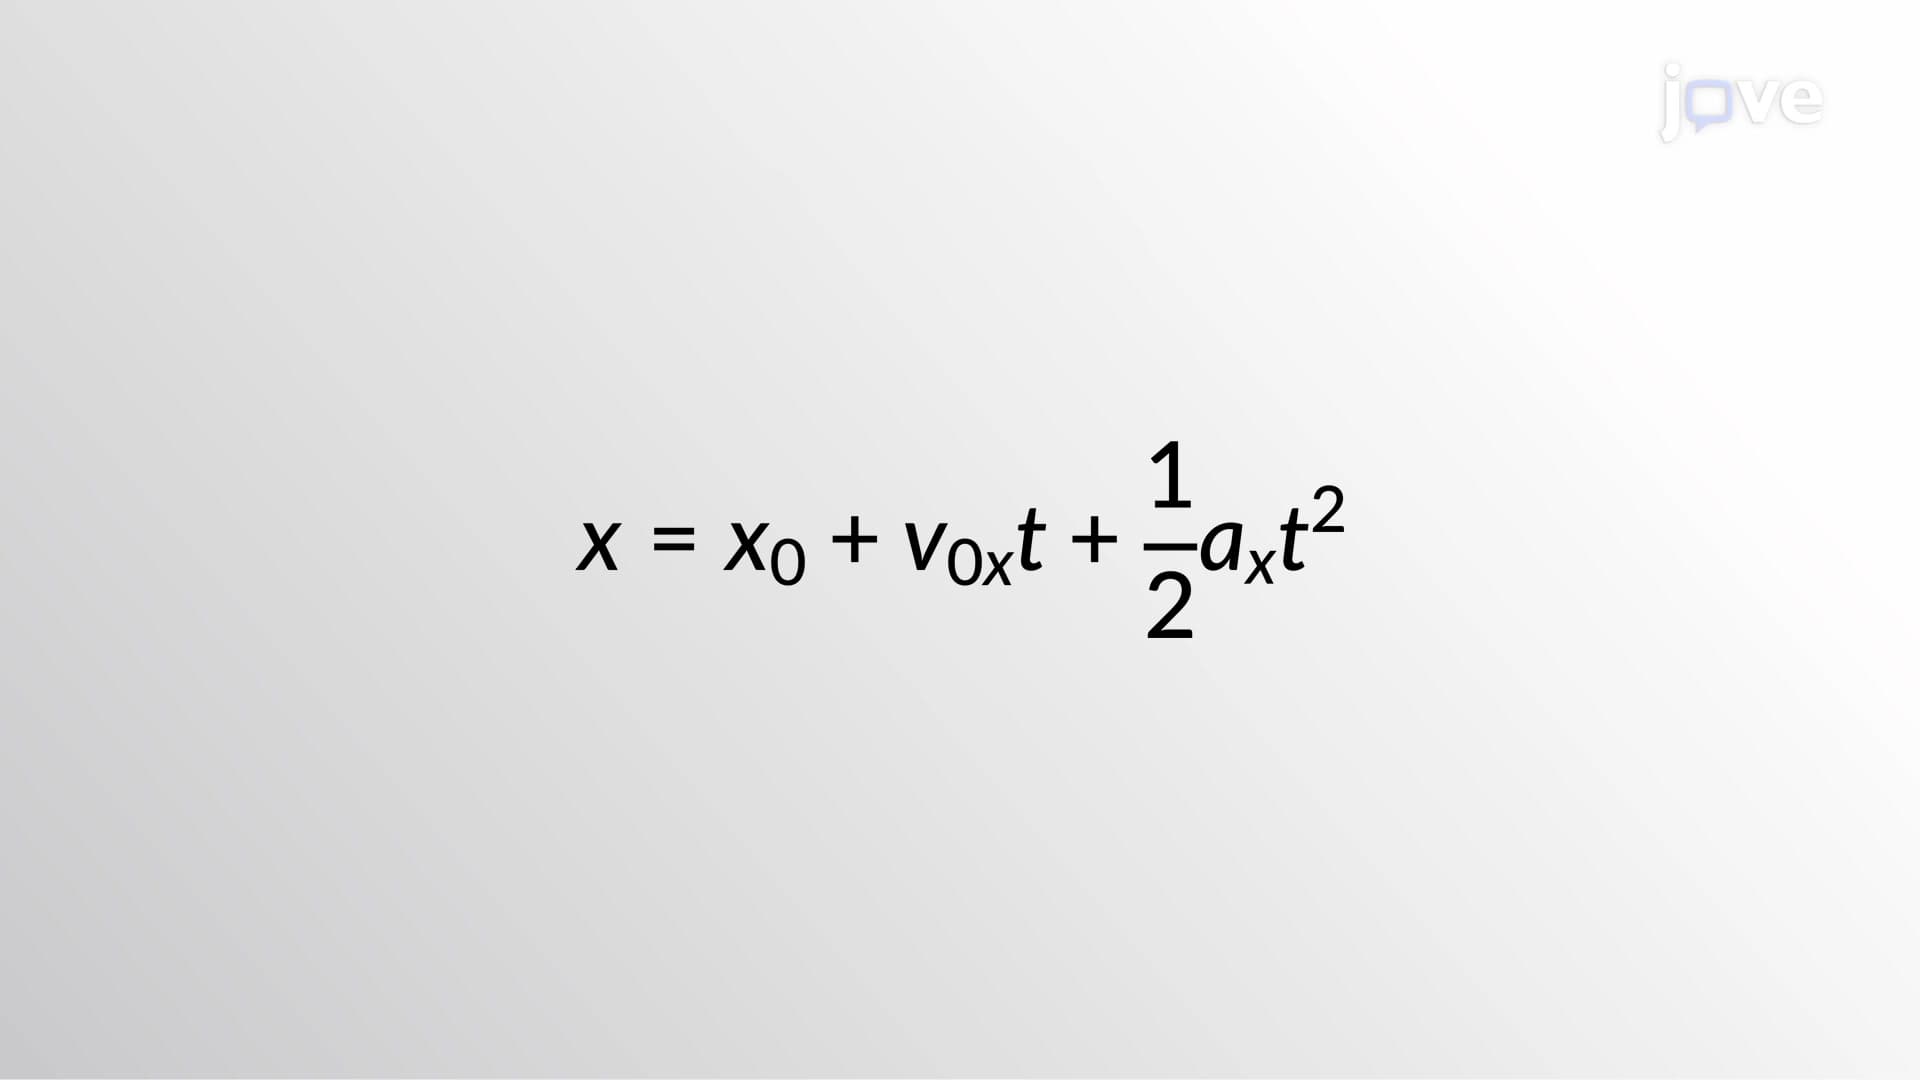 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
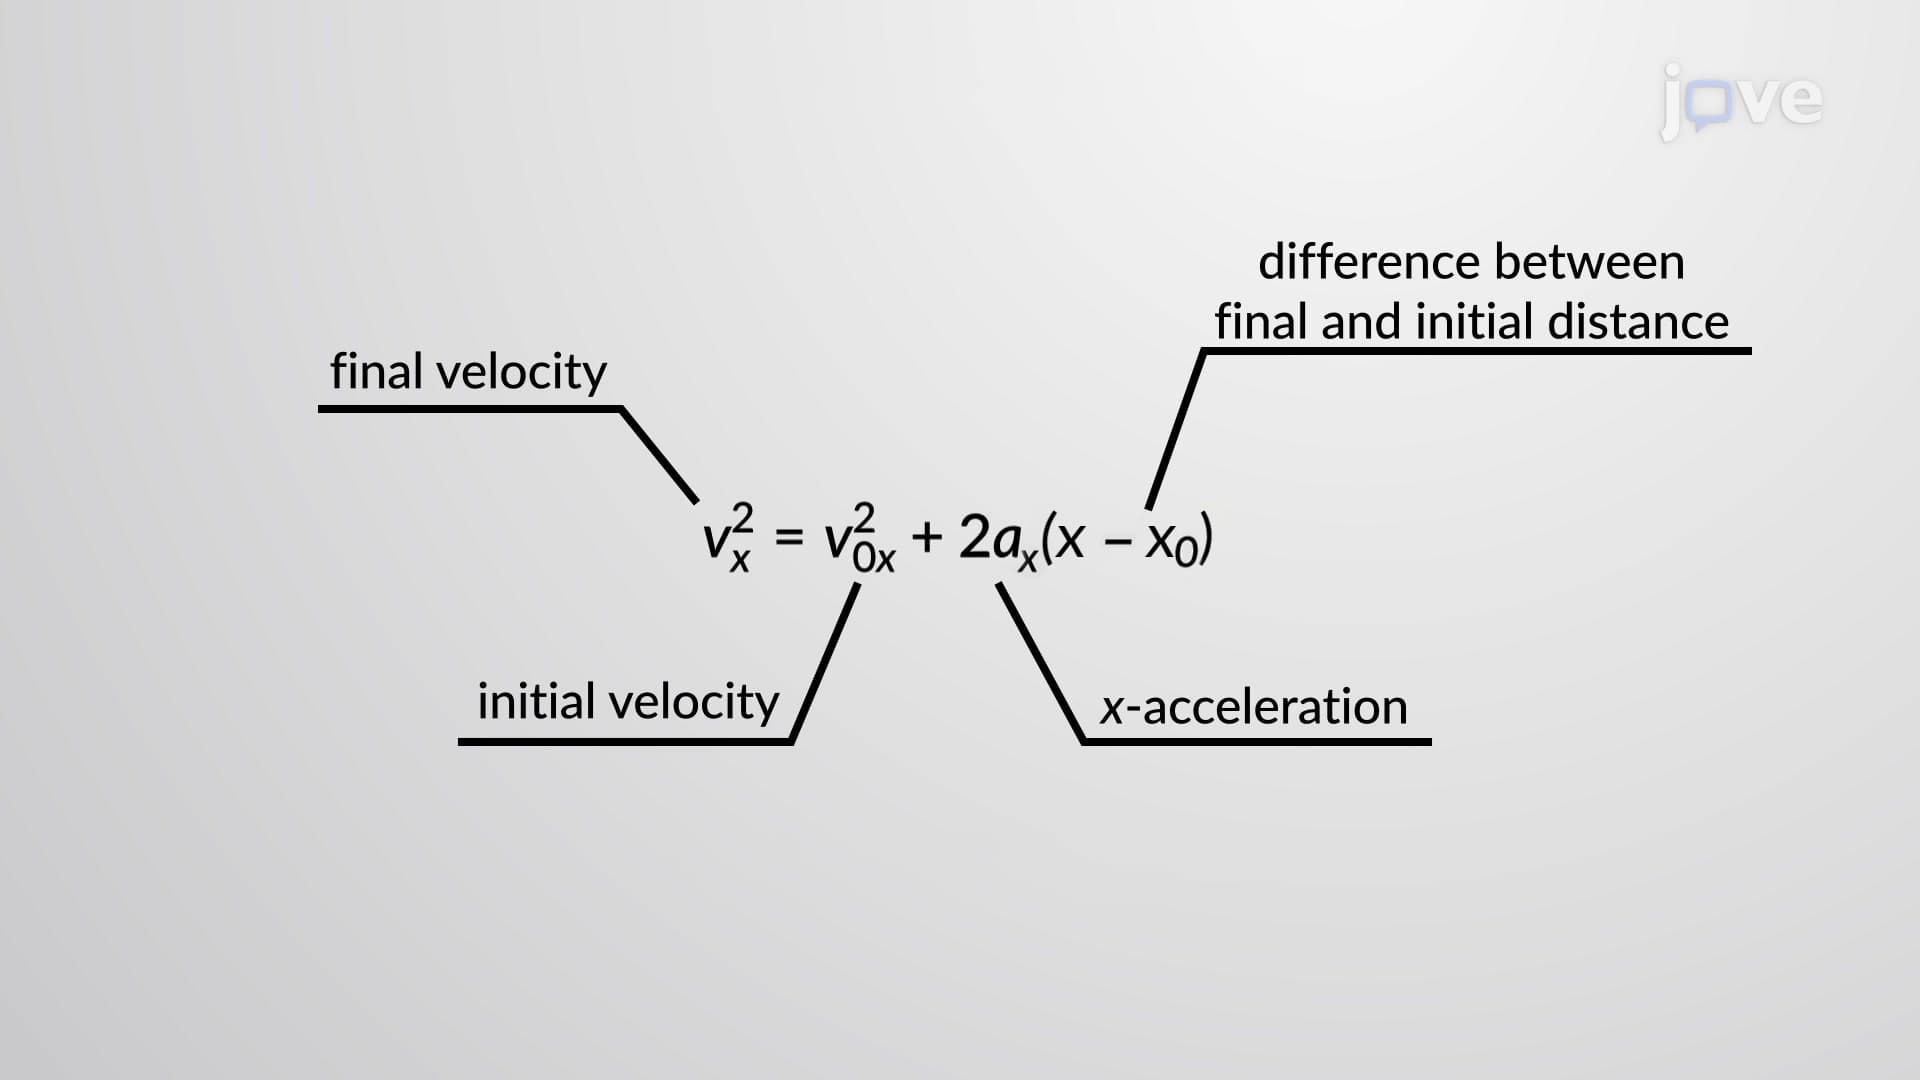
Kinematic Equations - III
Using the kinematic equations,...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
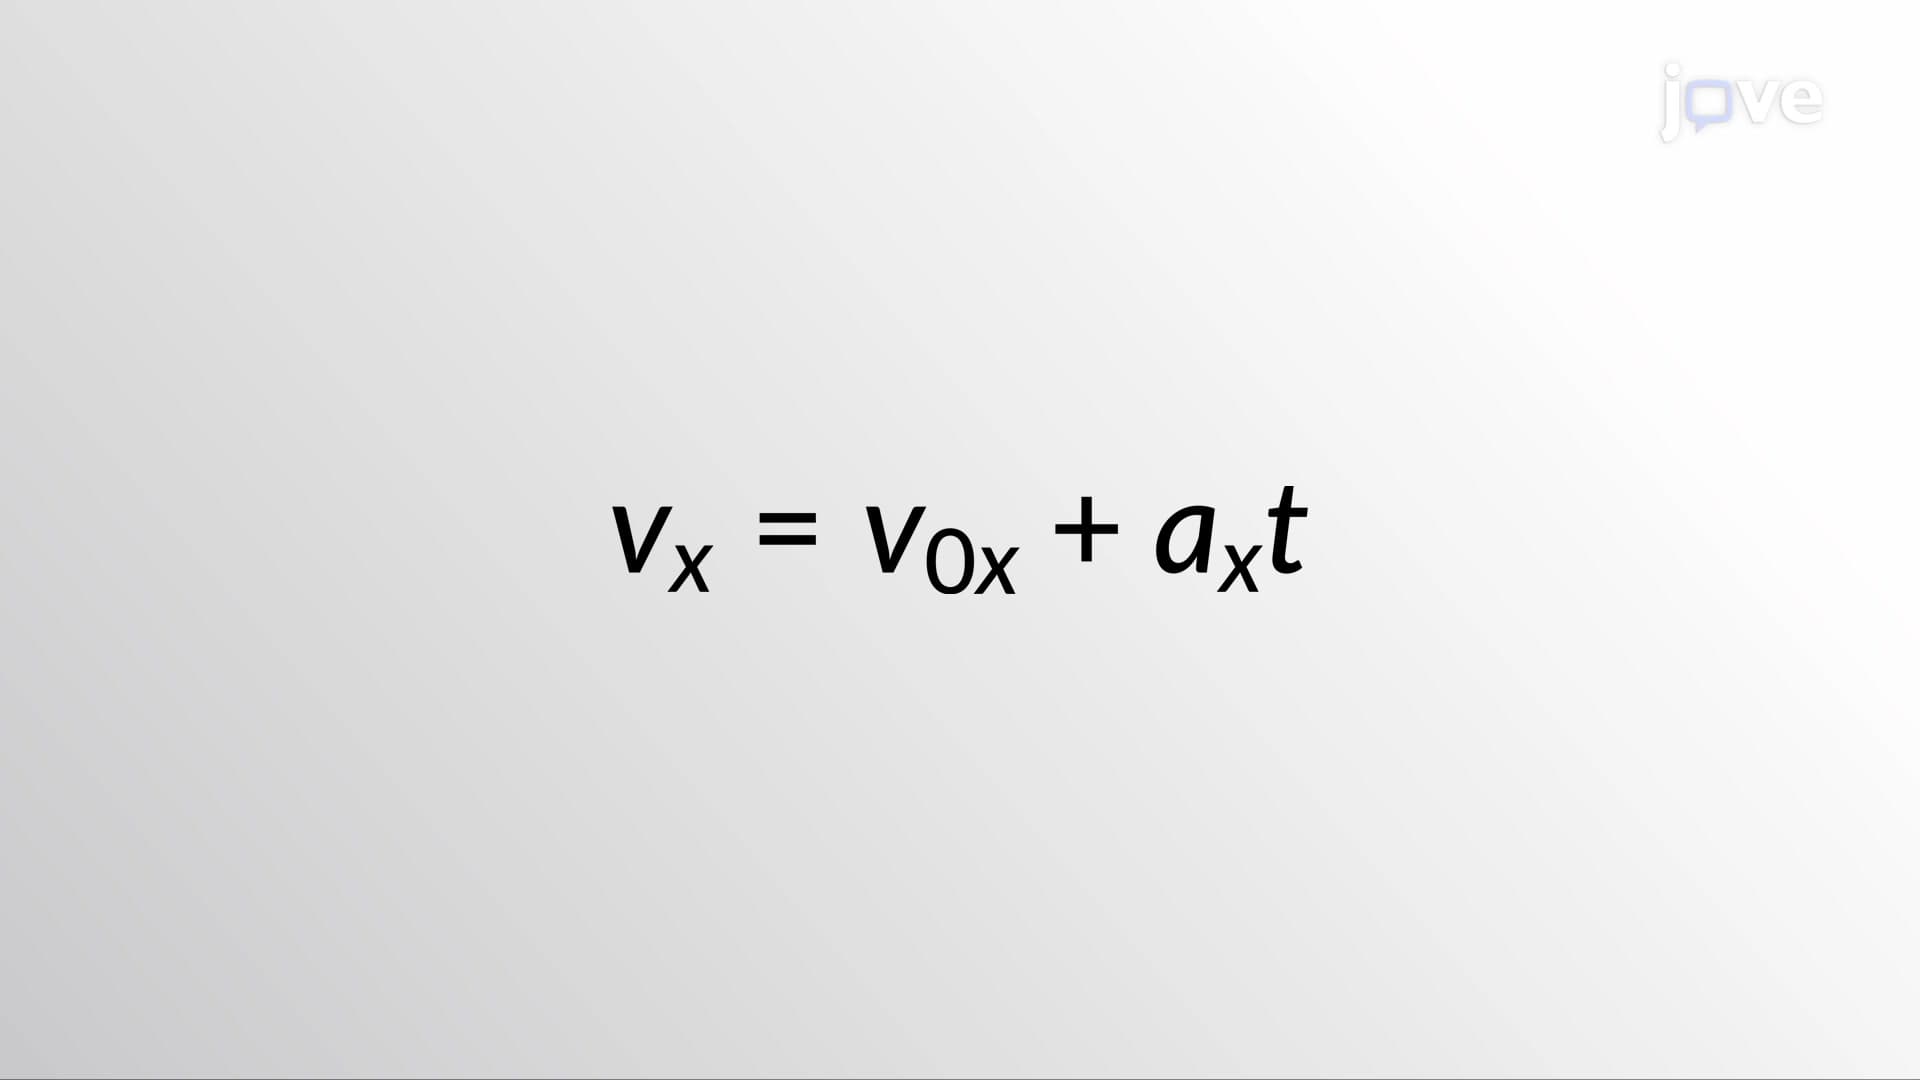 01:26
Kinematic Equations - I
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...