Related Experiment Video
Updated: Dec 3, 2025

Simulator Training for Endovascular Neurosurgery
Published on: May 6, 2020
Development and validation of non-guided bladder-neck and neurovascular-bundle dissection modules of the
Jan Ebbing1,2, Peter N Wiklund2,3,4, Olof Akre2,3
1University Hospital Basel, Department of Urology, Basel, Switzerland.

Background:
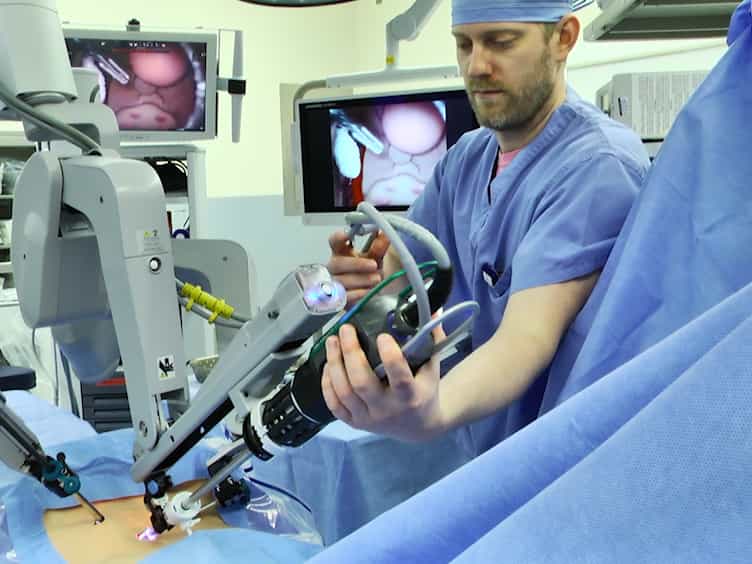
Full-procedure virtual reality (VR) simulator training in robotic-assisted radical prostatectomy (RARP) is a new tool in surgical education.
Methods:
Description of the development of a VR RARP simulation model, (RobotiX-Mentor®) including non-guided bladder neck (ngBND) and neurovascular bundle dissection (ngNVBD) modules, and assessment of face, content, and construct validation of the ngBND and ngNVBD modules by robotic surgeons with different experience levels.
Results:
Simulator and ngBND/ngNVBD modules were rated highly by all surgeons for realism and usability as training tool. In the ngBND-task construct, validation was not achieved in task-specific performance metrics. In the ngNVBD, task-specific performance of the expert/intermediately experienced surgeons was significantly better than that of novices.
Conclusions:
We proved face and content validity of simulator and both modules, and construct validity for generic metrics of the ngBND module and for generic and task-specific metrics of the ngNVBD module.