Related Experiment Video
Updated: Dec 2, 2025

Fabrication and Characterization of Disordered Polymer Optical Fibers for Transverse Anderson Localization of Light
Published on: July 29, 2013
Nonlocal operators are chaotic
Carlos Lizama1, Marina Murillo-Arcila2, Alfred Peris2
1Departamento de Matemática y Ciencia de la Computación, Facultad de Ciencias, Universidad de Santiago de Chile, Casilla 307, Correo 2, Santiago, Chile.

Abstract:
We characterize for the first time the chaotic behavior of nonlocal operators that come from a broad class of time-stepping schemes of approximation for fractional differential operators. For that purpose, we use criteria for chaos of Toeplitz operators in Lebesgue spaces of sequences. Surprisingly, this characterization is proved to be-in some cases-dependent of the fractional order of the operator and the step size of the scheme.
More Related Videos

Related Concept Videos
 01:10
Entropy Change in Reversible Processes
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
 00:59
Propagation of Uncertainty from Random Error
 01:23
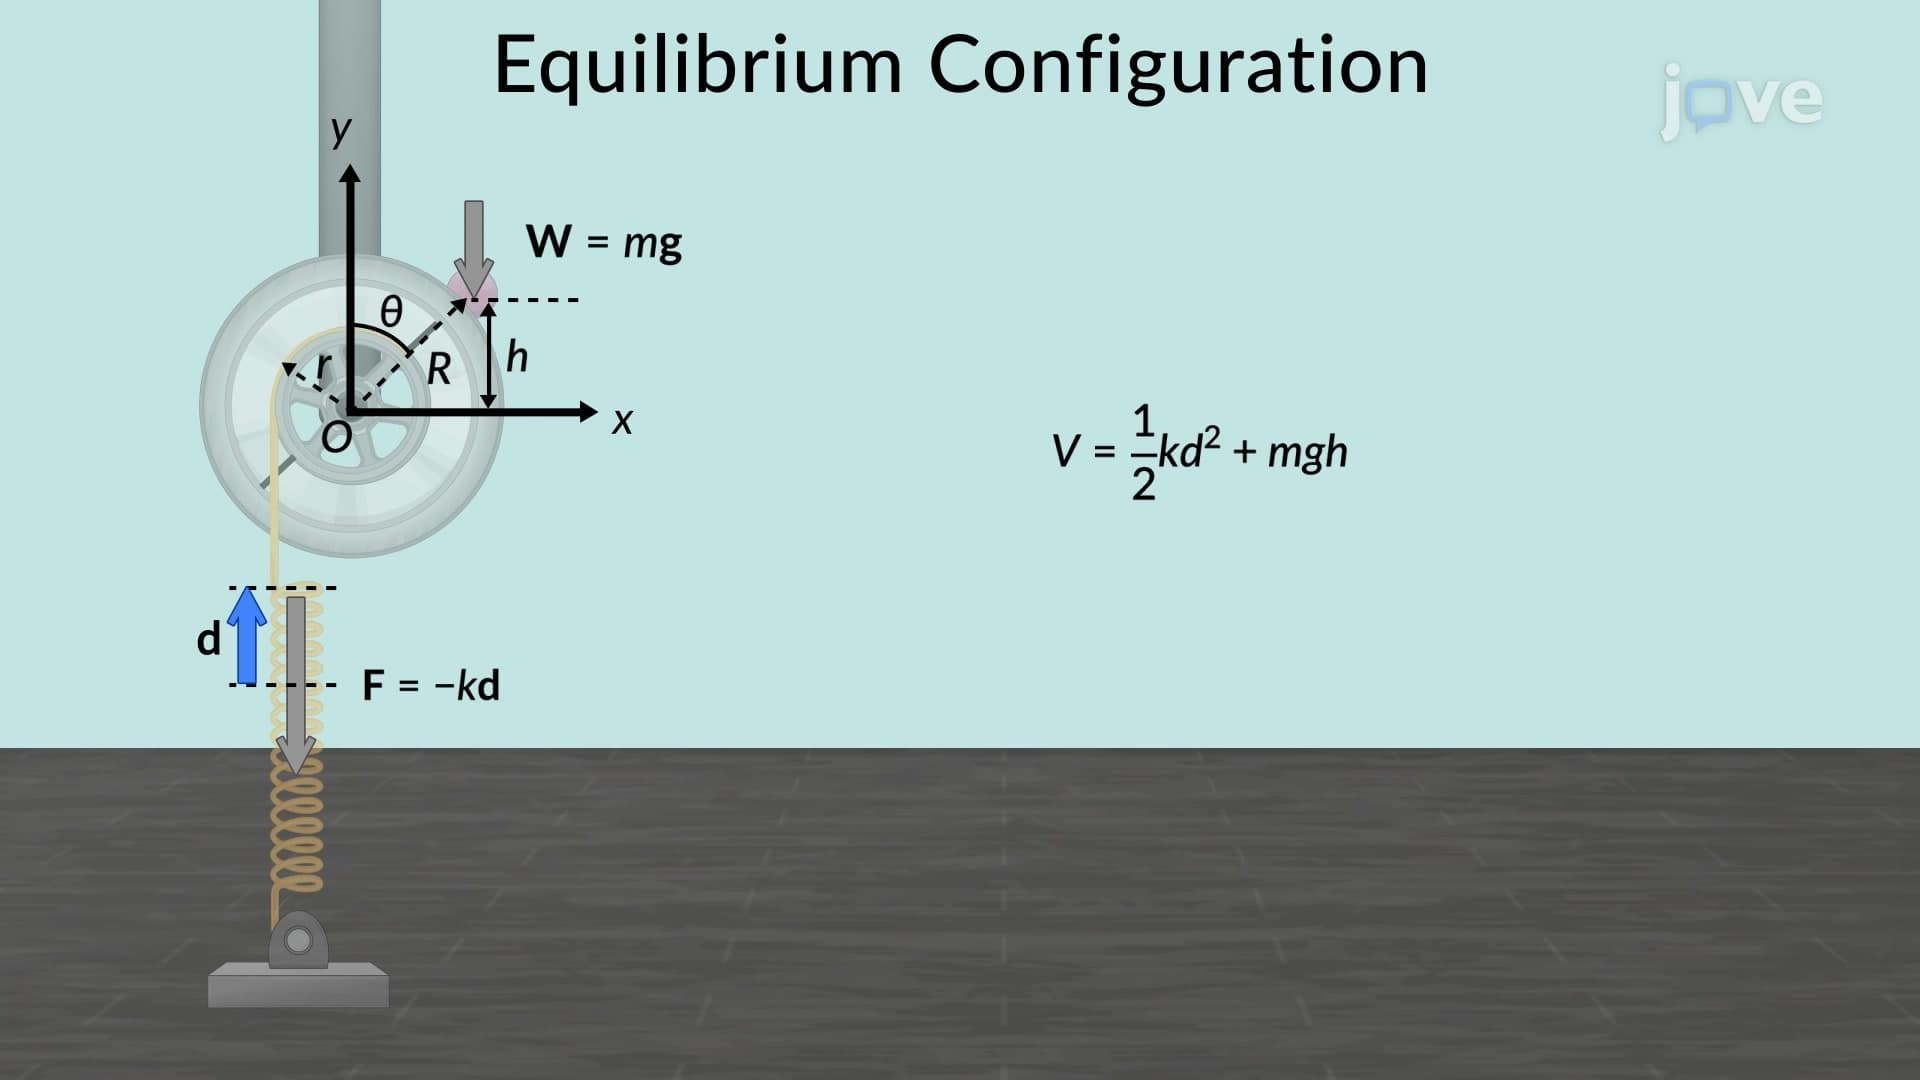
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:19
Limits with Oscillating Discontinuities