Related Experiment Video
Updated: Dec 2, 2025
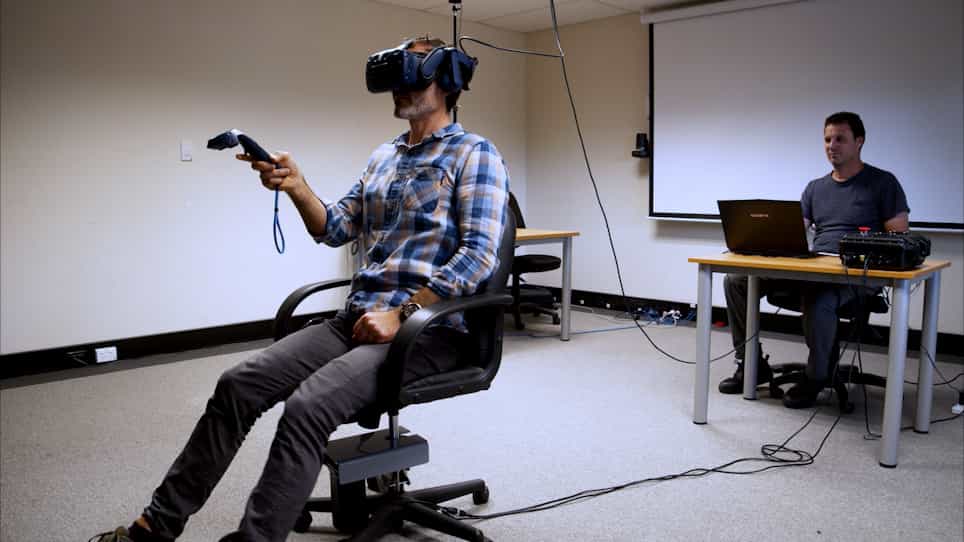

Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
The Rotating Snakes Illusion Is a Straightforward Consequence of Nonlinearity in Arrays of Standard Motion Detectors
Michael Bach1, Lea Atala-Gérard1
1Eye Center, Medical Center - University of Freiburg, Faculty of Medicine, University of Freiburg, Germany.

Abstract:
The Rotating Snakes illusion is a motion illusion based on repeating, asymmetric luminance patterns. Recently, we found certain gray-value conditions where a weak illusory motion occurs in the opposite direction. Of the four models for explaining the illusion, one also explains the unexpected perceived opposite direction.We here present a simple new model, without free parameters, based on an array of standard correlation-type motion detectors with a subsequent nonlinearity (e.g., saturation) before summing the detector outputs. The model predicts (a) the pattern-appearance motion illusion for steady fixation, (b) an illusion under the real-world situation of saccades across or near the pattern (pattern shift), (c) a relative maximum of illusory motion for the same gray values where it is found psychophysically, and (d) the opposite illusion for certain luminance values. We submit that the new model's sparseness of assumptions justifies adding a fifth model to explain this illusion.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:26
Rotational Motion about a Fixed Axis