On the Organization of the Locomotor CPG: Insights From Split-Belt Locomotion and Mathematical Modeling
Related Experiment Video
Updated: Nov 30, 2025
Using a Split-belt Treadmill to Evaluate Generalization of Human Locomotor Adaptation
Published on: August 23, 2017
Elizaveta M Latash1, Charly G Lecomte2, Simon M Danner3
1Department of Mathematics and Statistics, Georgia State University, Atlanta, GA, United States.

Abstract:
Rhythmic limb movements during locomotion are controlled by central pattern generator (CPG) circuits located in the spinal cord. It is considered that these circuits are composed of individual rhythm generators (RGs) for each limb interacting with each other through multiple commissural and long propriospinal circuits. The organization and operation of each RG are not fully understood, and different competing theories exist about interactions between its flexor and extensor components, as well as about left-right commissural interactions between the RGs. The central idea of circuit organization proposed in this study is that with an increase of excitatory input to each RG (or an increase in locomotor speed) the rhythmogenic mechanism of the RGs changes from "flexor-driven" rhythmicity to a "classical half-center" mechanism. We test this hypothesis using our experimental data on changes in duration of stance and swing phases in the intact and spinal cats walking on the ground or tied-belt treadmills (symmetric conditions) or split-belt treadmills with different left and right belt speeds (asymmetric conditions). We compare these experimental data with the results of mathematical modeling, in which simulated CPG circuits operate in similar symmetric and asymmetric conditions with matching or differing control drives to the left and right RGs. The obtained results support the proposed concept of state-dependent changes in RG operation and specific commissural interactions between the RGs. The performed simulations and mathematical analysis of model operation under different conditions provide new insights into CPG network organization and limb coordination during locomotion.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:10
Relative Motion Analysis - Acceleration
 01:19
Root-Locus Method
This system can be represented by a block...
 01:28
Major Somatic Sensory Pathways
 01:11
Direct Motor Pathways
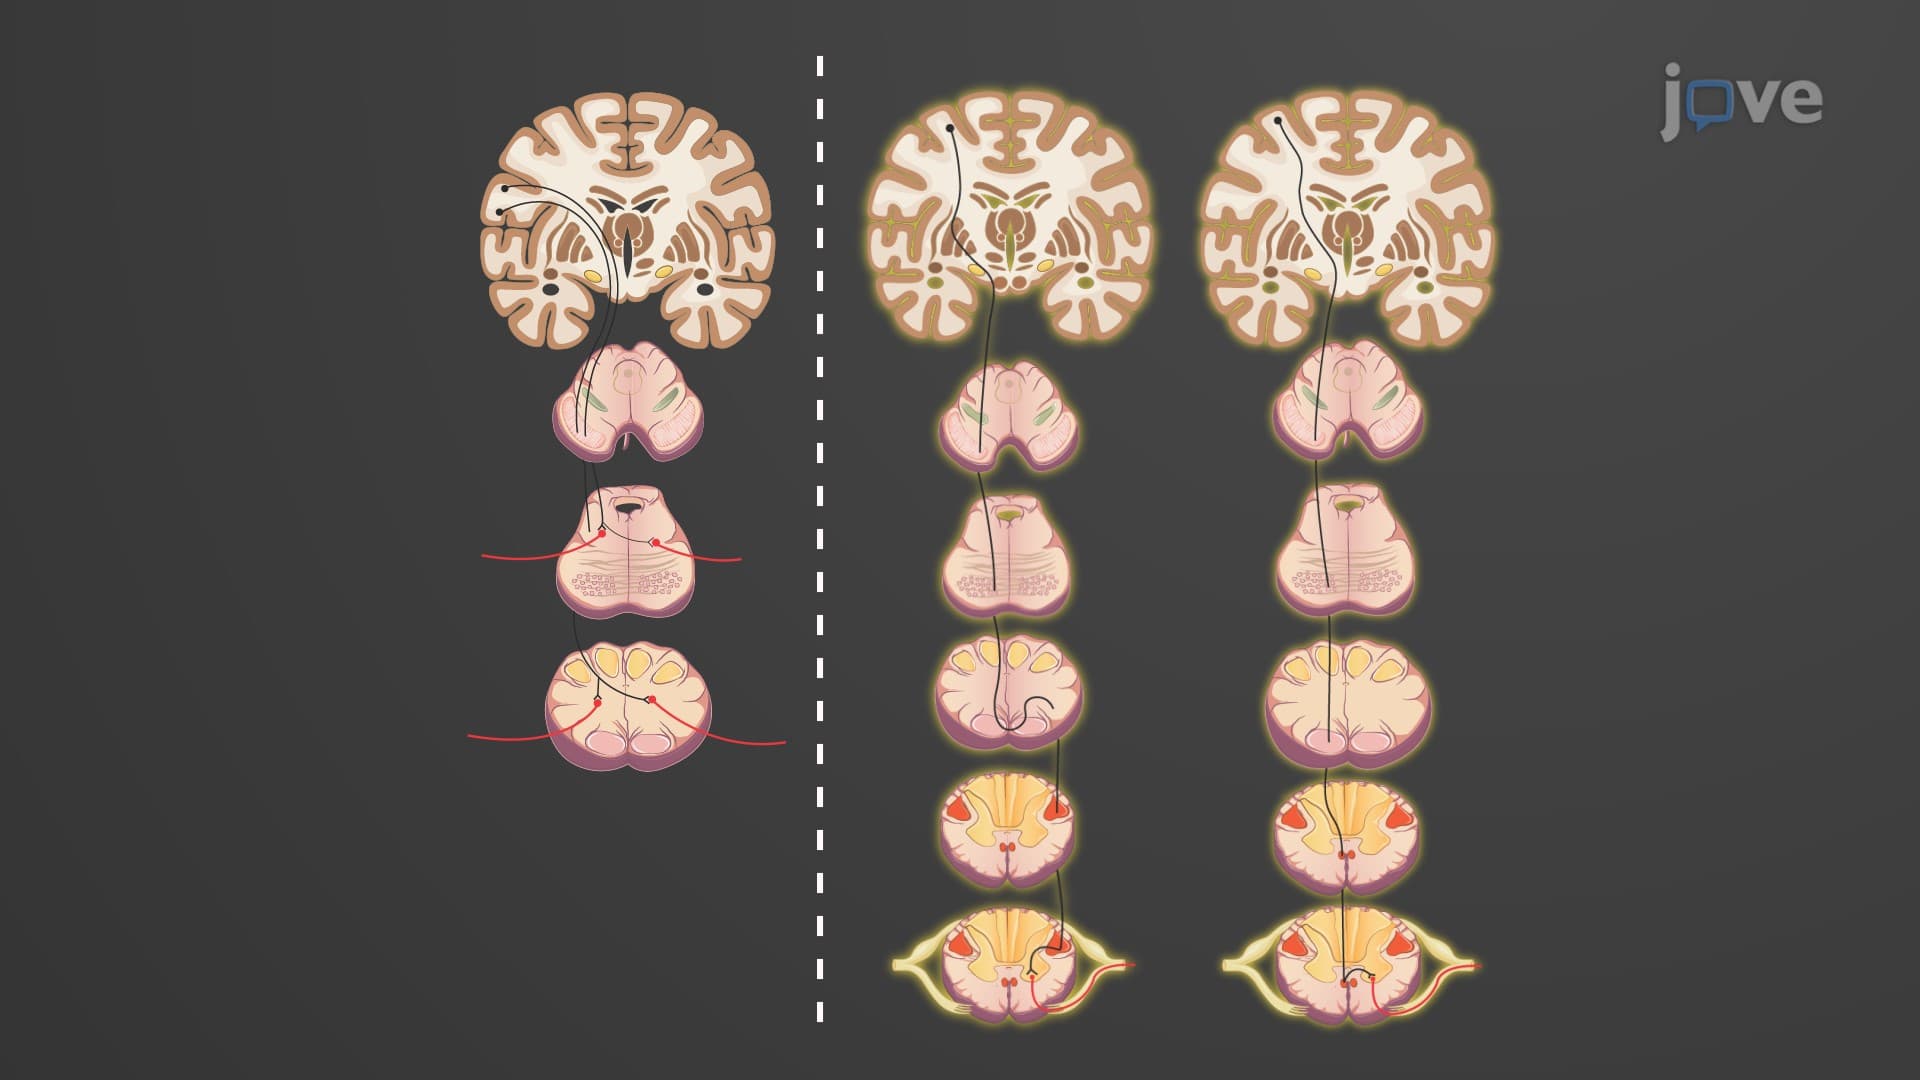
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...