A Robotic Laparoscope Holder With High Bending Curvature Based on an Origami Metamaterial
Related Experiment Video
Updated: Nov 1, 2026
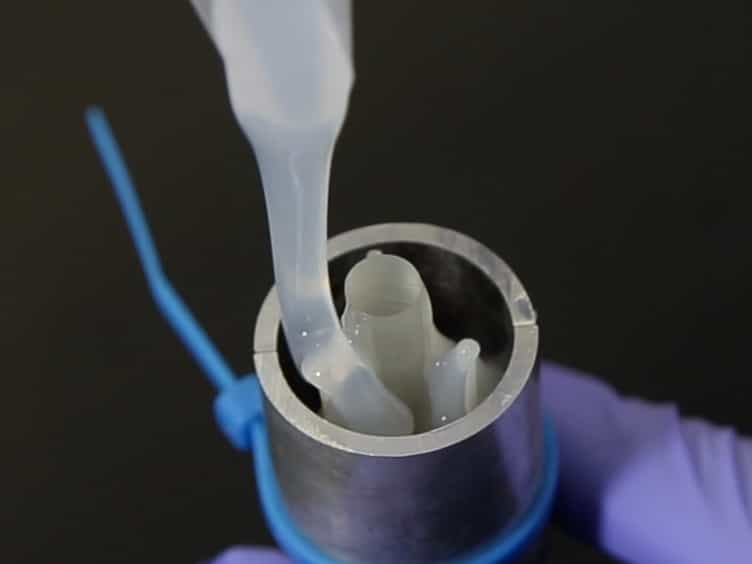
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Haixin Zhao1, Jinhua Li1, Yue Yu1
1School of Mechanical Engineering, Tianjin University, Tianjin, China.

Background:
Robotic laparoscope holders offer stable visualisation and reduce operator fatigue, thereby enhancing surgical efficiency. Flexible endoscopes provide better manoeuverability than rigid ones but struggle to achieve large bending in confined abdominal spaces.
Methods:
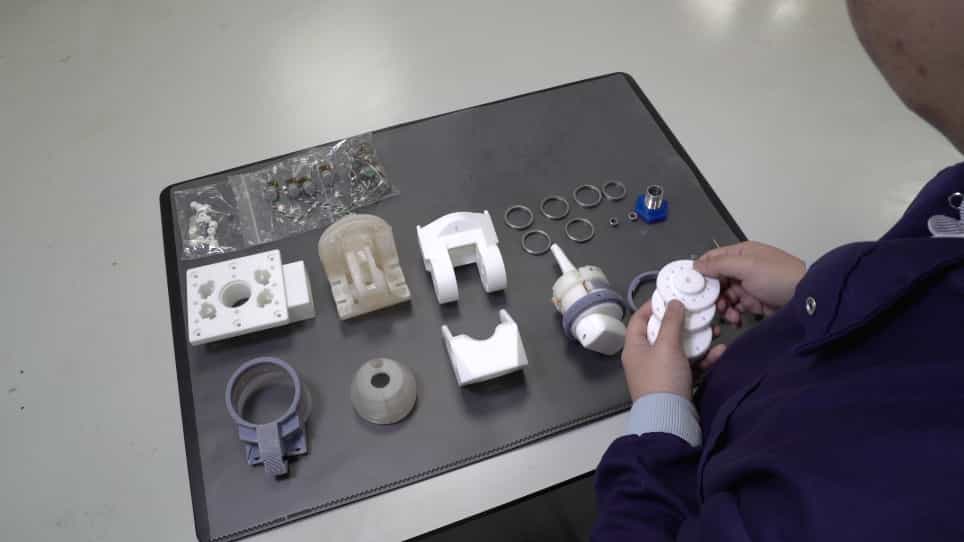
This study proposes a robotic laparoscope holder with high bending curvature based on an origami metamaterial composed of serially connected spatial bending units and umbrella-like motion components. The bending motion is achieved through rotational coupling between linkages, without cable actuation. A prototype was fabricated to experimentally validate the feasibility of the proposed mechanism.
Results:
Experimental results show that the proposed robotic laparoscope holder can achieve a bending range exceeding 240 within an effective bending length of approximately 29 mm, with a maximum positional error of around 2.5 mm and a payload capacity of 200 g.
Conclusions:
This design provides surgeons with enhanced operational flexibility and stable visualisation, demonstrating strong potential for laparoscopic surgery applications.