
Steady state analysis of modern industrial variable speed drive systems using controllers adjusted via grey wolf
Safwan Nadweh1, Ola Khaddam1, Ghassan Hayeh1
1Electrical Power Engineering Department, Tishreen University, 2230 Lattakia, Syria.

Abstract:
This paper presents the reconfiguration of control circuit designed to control four-quadrant chopper placed in the variable speed drive system (VSDS)'s DC-link. The purpose of this design is to reduce the overall total harmonic distortion THD% of input current, and the ripple factor (RF) of the DC-link current in this system. Both of Grey Wolf Algorithm (GWO) & Particle Swarm Optimization (PSO) have been used to get the optimal parameters of proportional integral PI and proportional integral differential with filter PIDN controllers. The variable speed drive system and the proposed filter have been modeled in integration with the suggested algorithms to determine the optimal values of the controllers' parameters. The grey wolf algorithm GWO outperformed the PSO algorithm in term of reaching the optimum parameters in less number of iterations in both dynamic and static work conditions. Also, the time response of the system with GWO is better than with PSO.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:21
The Swing Equation
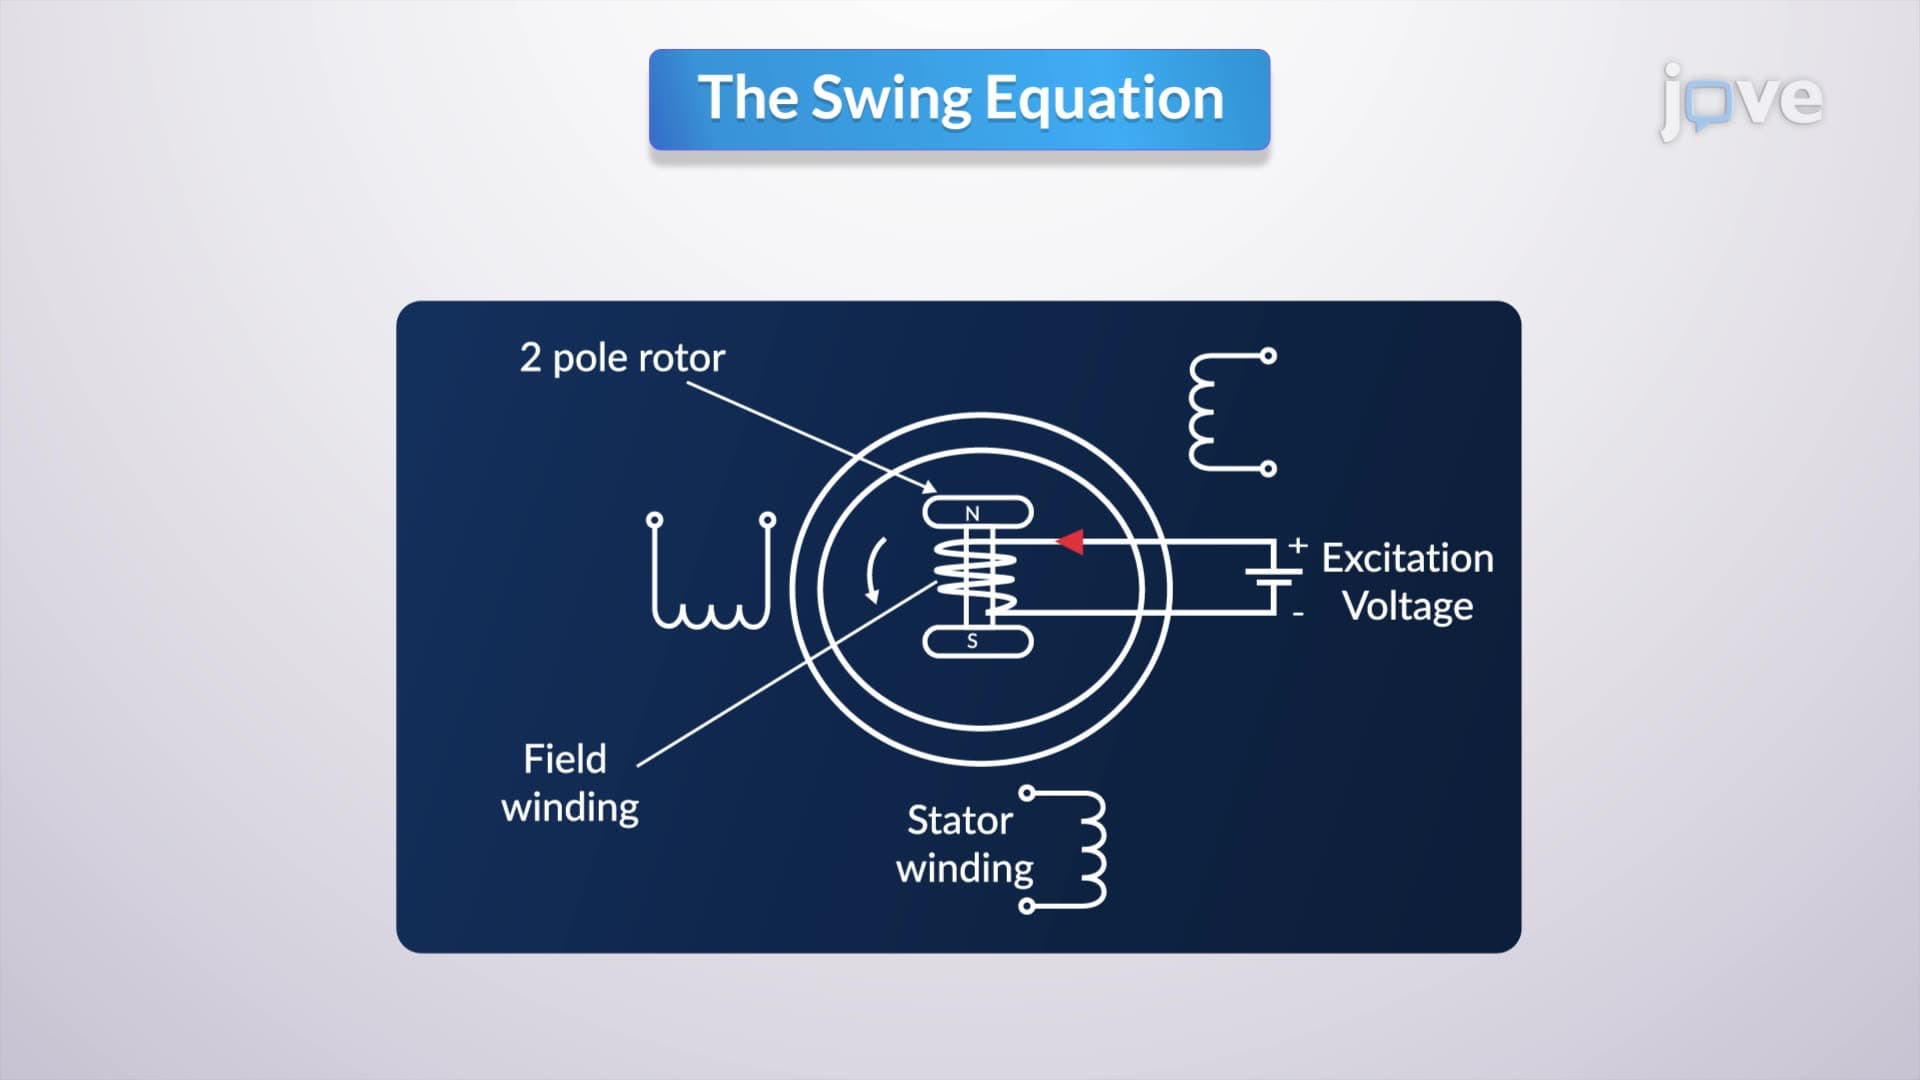
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque (Τe)...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:19
PID Controller
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...