Related Experiment Video
Updated: Nov 27, 2025


Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Smooth and slipless walking mechanism inspired by the open-close cycle of a beetle claw
Daiki Shima1, Jia Hui Gan2, Shinjiro Umezu1
1School of Department of Modern Mechanical Engineering, Waseda University, Japan.

Abstract:
This study investigated the function of the beetle's claw for its smooth and slipless walking and designed an artificial claw open-close cycle mechanism to mimic the beetle's walking. First, the effects of claw opening and closing on beetles' ability to attach to surfaces were examined. A beetle does not have an attachment pad, and only its claws work to grip the ground; its claw opens and closes and attaches with two sharp hooks. With their claws, beetles can smoothly walk, neither slipping on nor having their claws stuck in the surface. How do they perform smooth walking with sharp claws? In this study, we observed that beetles close their claws when they raise and swung their legs forward, while they open their claws when they lowered their legs to the ground. We then conducted non-destructive tests: their claws were forced open or closed. There was a significant difference in the trajectories of forced-closed claws compared to intact claws and forced-open claws. When their claws were forced-closed, this caused slippage in walking. On the other hand, when a claw was forced-open and its rotation was also inhibited, the claw stuck heavily in the surface, and the beetle could not walk. Based on these findings, we designed an artificial claw to open and close in the same cyclic manner as in the case of natural beetles. The performance of the artificial claw was consistent with the conclusions drawn from natural beetles: the locomotive robot with the artificial claw smoothly moved without slippage. Through these observations, non-destructive tests and performance of the bio-inspired artificial claws, this study confirmed the function of the open-close cycle of beetle claws and demonstrated and successfully adopted it for a locomotive robot.


Related Concept Videos
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:31
Mechanism of Lamellipodia Formation
 01:05
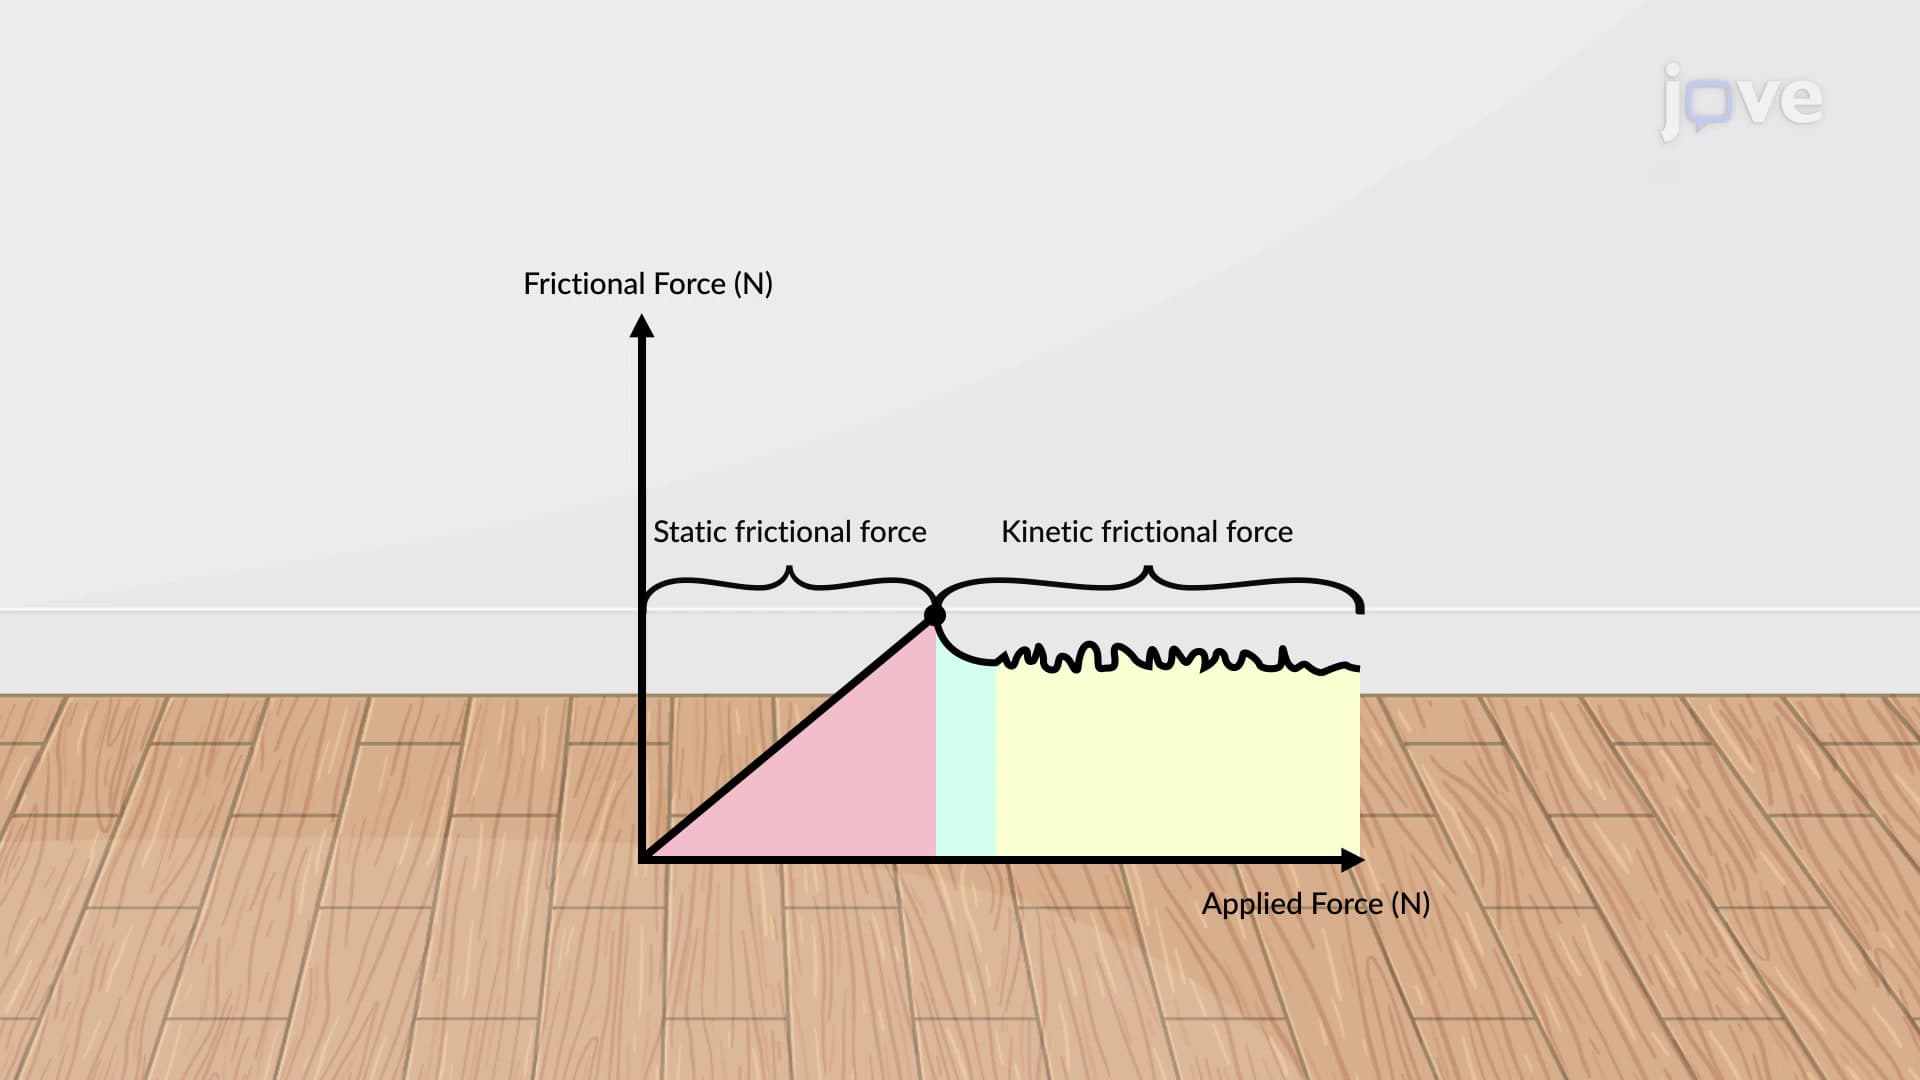
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:26
Kinetic Friction
 01:10
Relative Motion Analysis - Acceleration
 01:39
Mechanism of Filopodia Formation
Their main function is to guide migrating cells during normal tissue morphogenesis or cancer metastasis by recognizing and making initial contacts with the extracellular matrix. However, they can also act as stationary cell anchors or help to establish communication...