Related Experiment Video
Updated: Nov 26, 2025
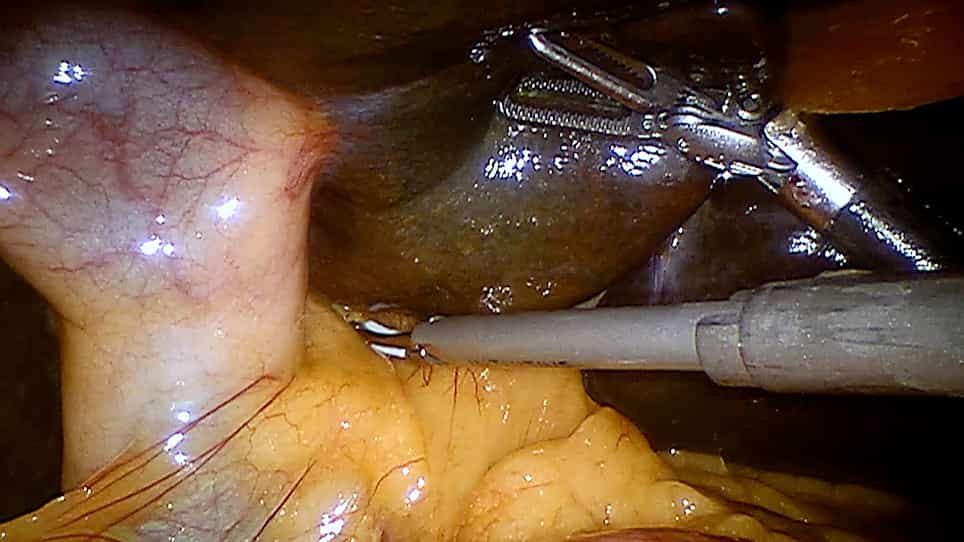

Robotic Taj Mahal Hepatectomy for Hilar Cholangiocarcinoma
Published on: July 14, 2022
Robotic central hepatectomy for hepatocarcinoma by glissonean approach (with video)
Antoine Camerlo1, Thomas Delayre1, Regis Fara1
1Department of digestive surgery, Hôpital Européen, 6 rue désirée Clary, 13003, Marseille, France.

Background:
Central bisegmentectomy of the liver implies excising Couinaud's segments IV, V and VIII (Couinaud and Le Foie, 1957) [1]. In a recent classification of laparoscopic liver resections, it belongs to the highly advanced level procedure group (Kawaguchi and et al., 2018 Jan) [2]. Improvement in laparoscopic devices should lead to a wider accessibility of such indications that are currently expert prerogatives. In order to illustrate the assets of robotic-assistance in the management of highly difficult mini-invasive hepatic resections, we present the case of a robotic central hepatectomy.
Methods:
This video illustrates robotic central hepatectomy in a 70-year-old male. A liver tumor involving segments IV, V and VIII was incidentally detected during abdominal ultrasonography. CT scan and MRI suggested the diagnosis of a seventy-millimeter centrally located hepatocellular carcinoma and surgical resection was decided.
Results:
The patient was placed supine in anti-Trendelenburg position. Four robotic trocars were placed and the da Vinci X robotic system was docked. Two laparoscopic ports were placed for the second surgeon (ultrasonic dissector and suction/irrigation set). Central hepatectomy was performed with a glissonean approach. Robotic irrigated bipolar coagulation and laparoscopic ultrasonic dissector was used for parenchymal transection. Postoperative course was uneventful. The patient was discharged on postoperative day eight.
Conclusion:
The recent publication of an International consensus statement demonstrates the growing involvement of robotics in liver surgery (Liu and et al., 2019 March 28) [3]. Robotic advantages (flexibility, absence of fulcrum effect and visual field stability) could improve accessibility to minimal invasive approach for difficult liver resection.