Related Experiment Video
Updated: Nov 23, 2025
Quasi-light Storage for Optical Data Packets
Published on: February 6, 2014
Space-Time Block Coded Cooperative MIMO Systems
1Engineering Research Center of Digitized Textile & Apparel Technology, College of Information Science and Technology, Donghua University, Shanghai 201620, China.

Abstract:
The main objective of a Cooperative Multiple-Input Multiple-Output (CMIMO) system is to improve network throughput and network coverage and save energy. By grouping wireless devices as virtual multi-antenna nodes, it can thus simulate the functions of multi-antenna systems. A Space-Time Block Code (STBC) was proposed to utilize the spatial diversity of MIMO systems to improve the diversity gain and coding gain. In this paper, we proposed a cooperative strategy based on STBC and CMIMO, which is referred to as Space-Time Block Coded Cooperative Multiple-Input Multiple-Output (STBC-CMIMO) to inherit the advantages from both STBC and CMIMO. The theoretical performance analysis for the proposed STBC-CMIMO is presented. The performance advantages of the STBC-CMIMO are also shown by simulations. In the simulations, it is demonstrated that STBC-CMIMO can obtain significant performance compared with the existing CMIMO system.
Related Concept Videos
 01:22
Block Diagram Reduction
The first step in this process is the identification and relocation of a branch point. A branch point, where a...
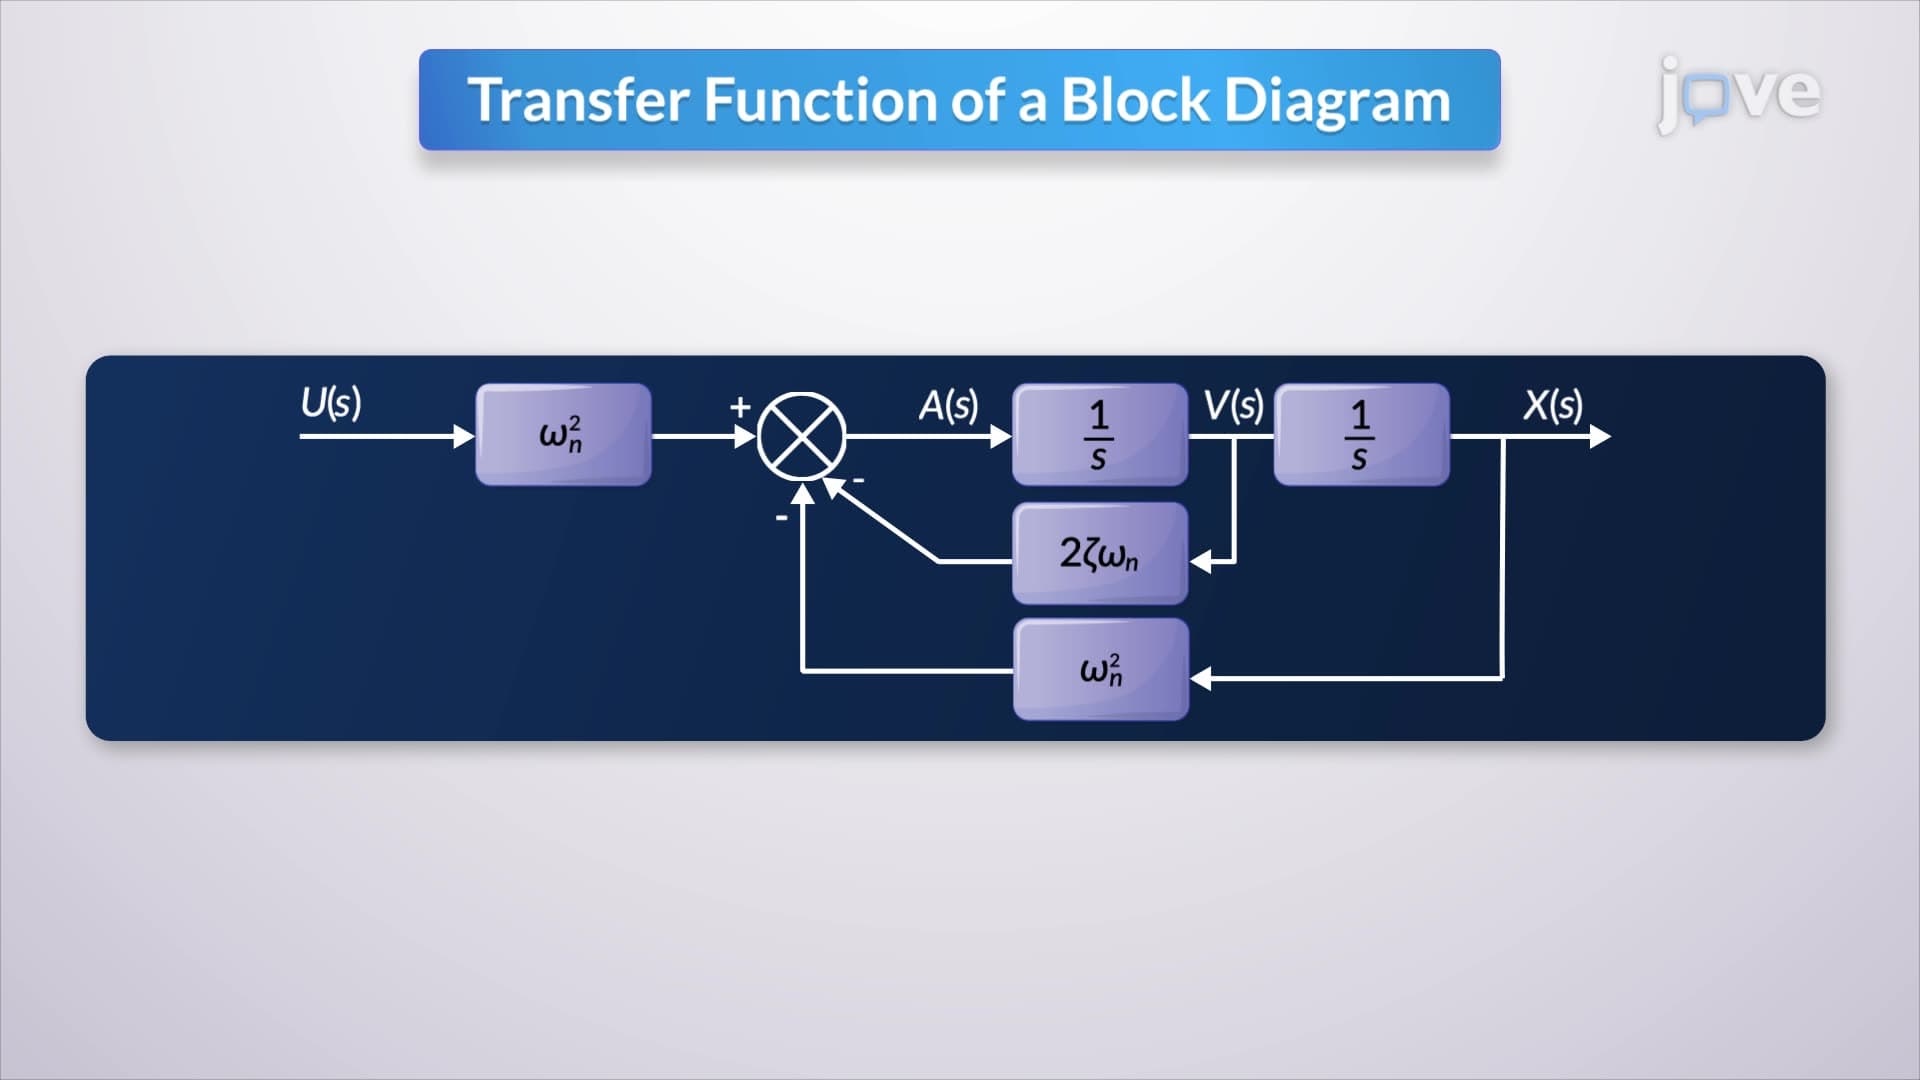 01:20
Relation between Mathematical Equations and Block Diagrams
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:25
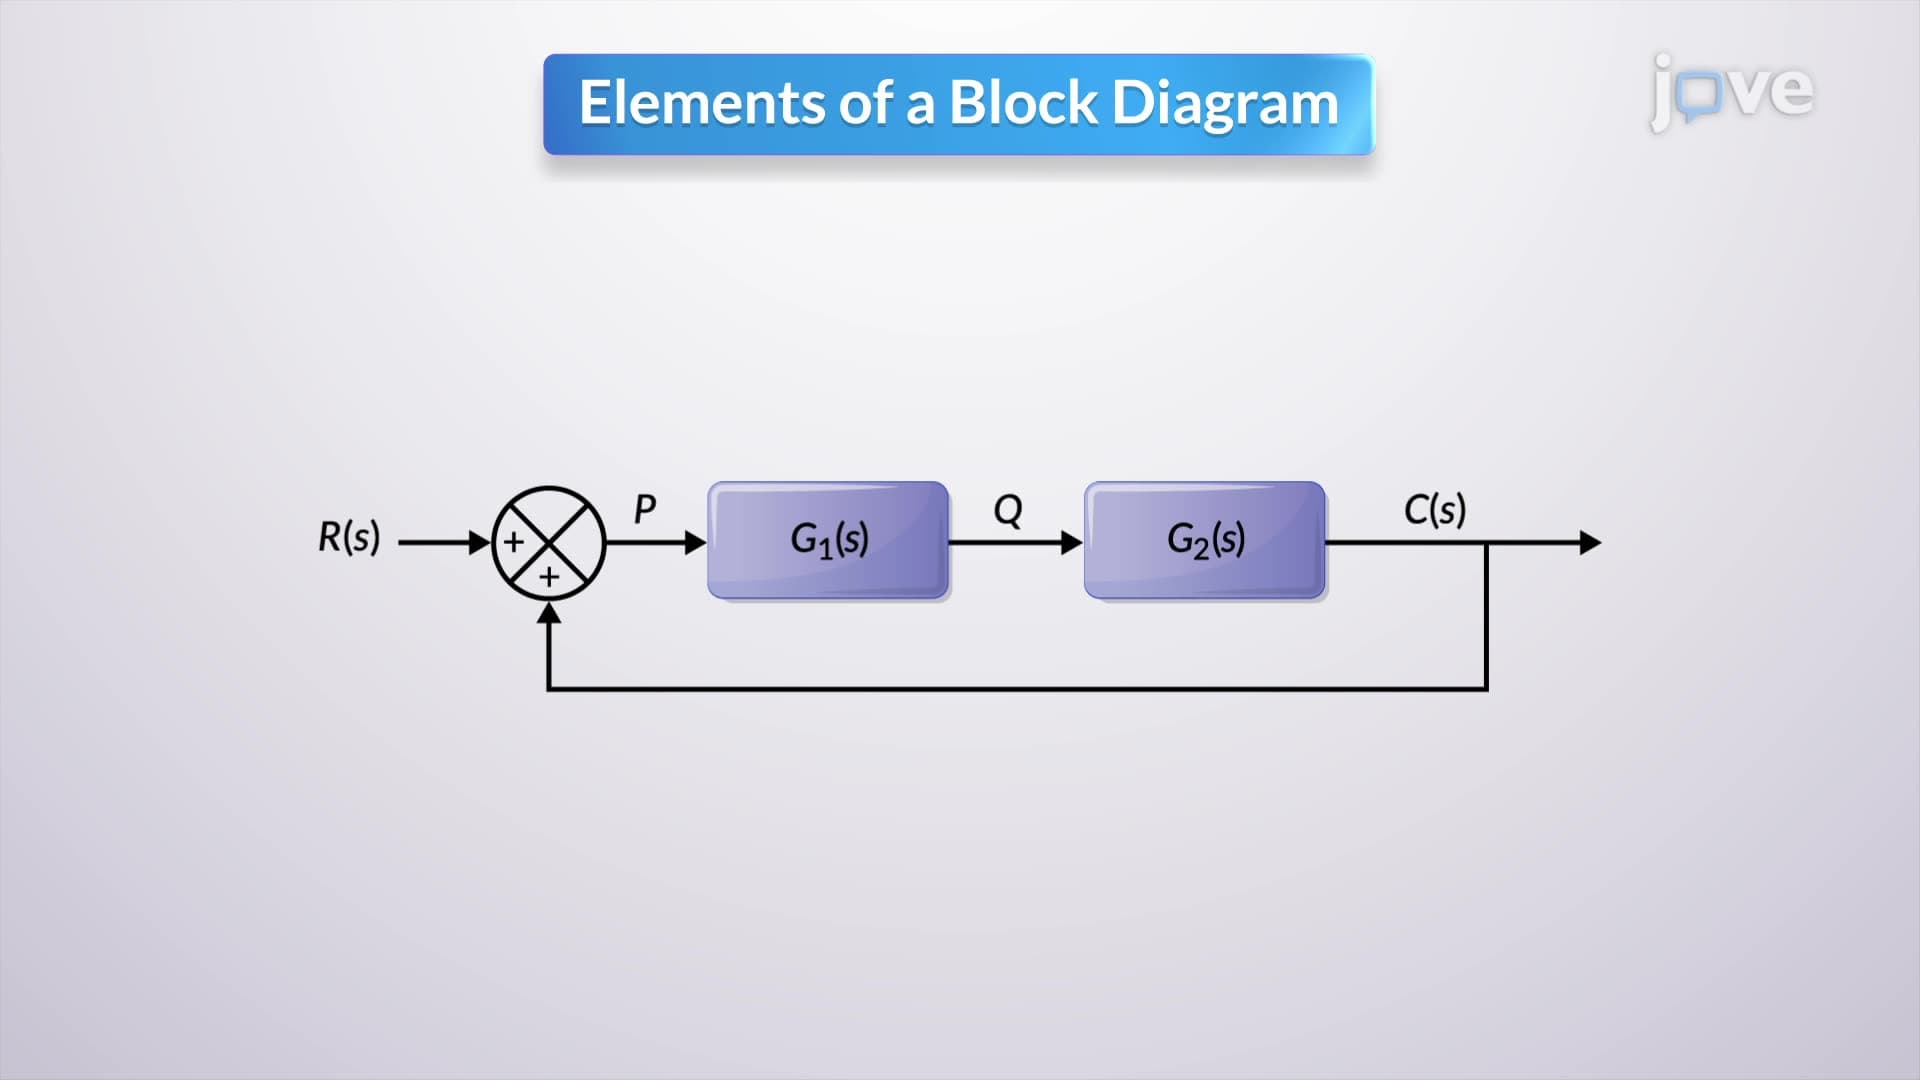
Elements of Block Diagrams
A block diagram typically includes essential elements such as comparators, blocks, and feedback loops. Each of these elements...
 01:16
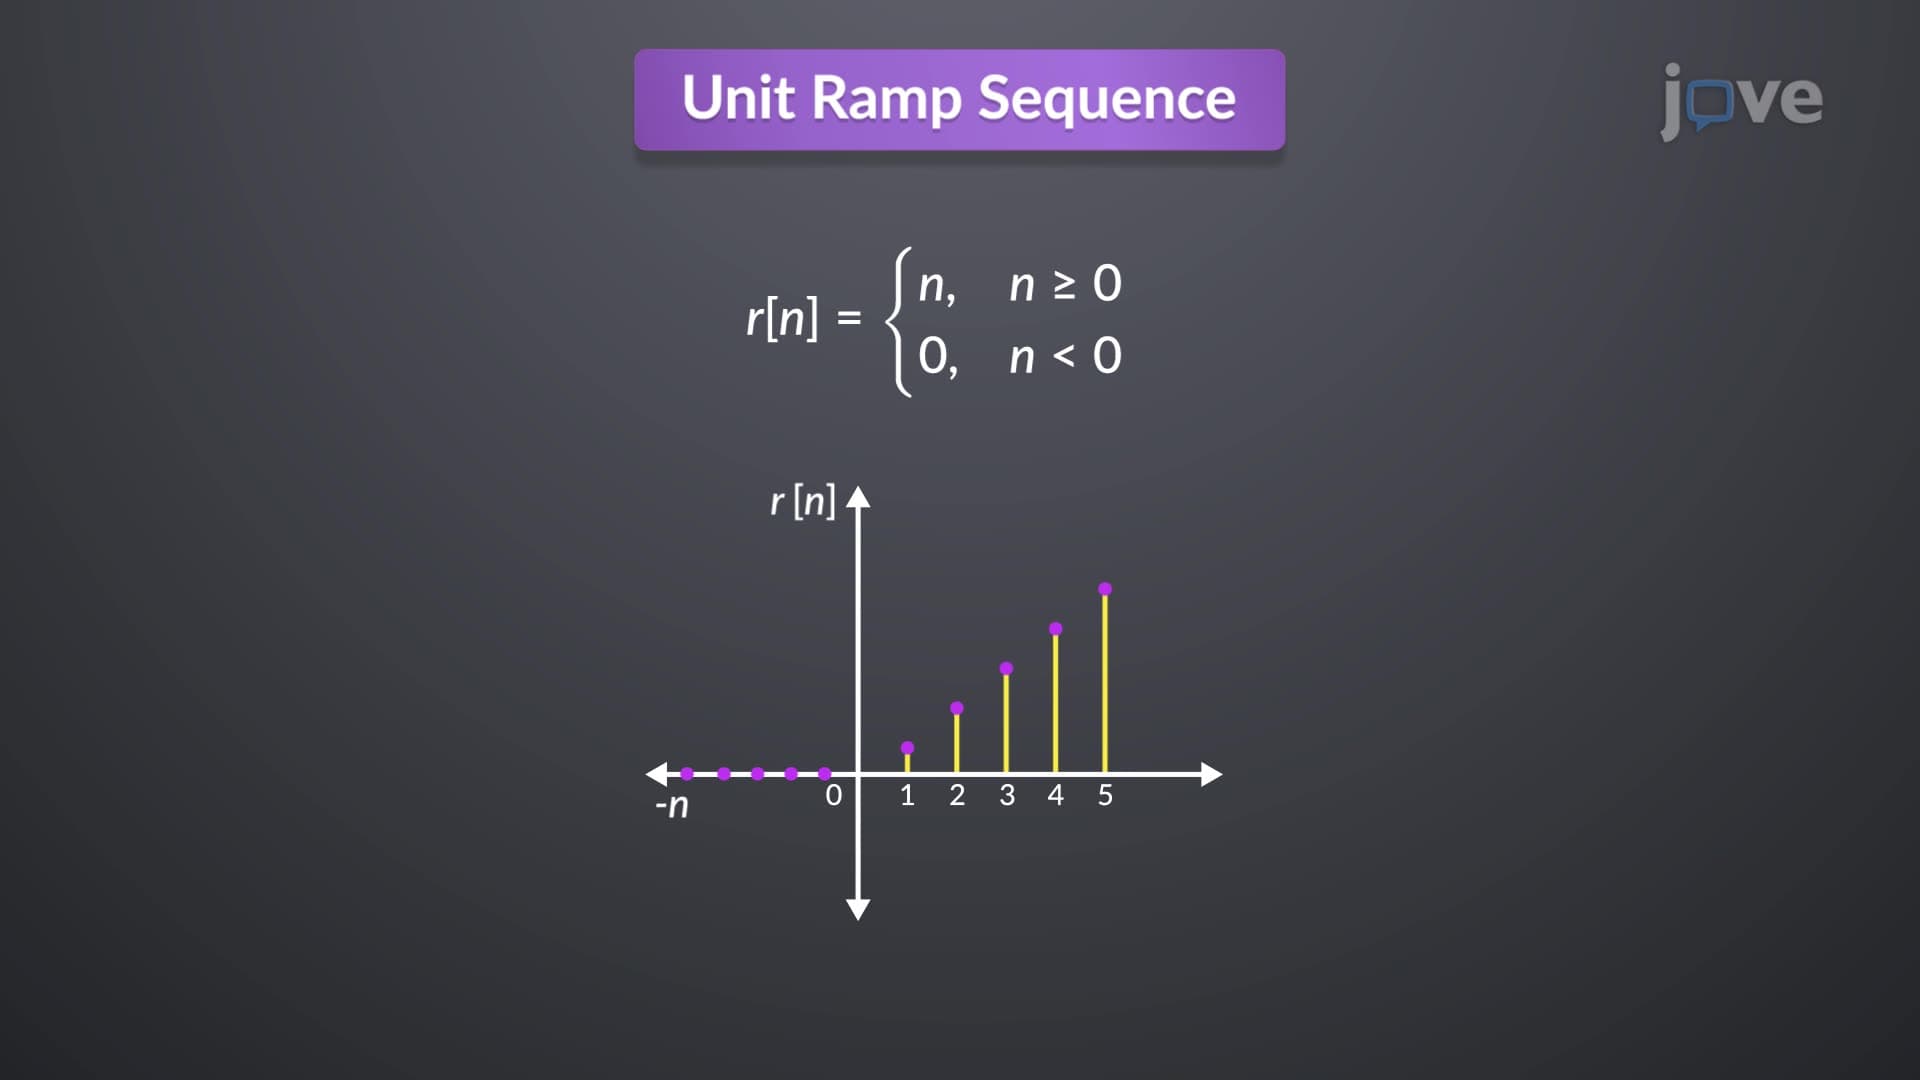
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...