Related Experiment Video
Updated: Nov 23, 2025
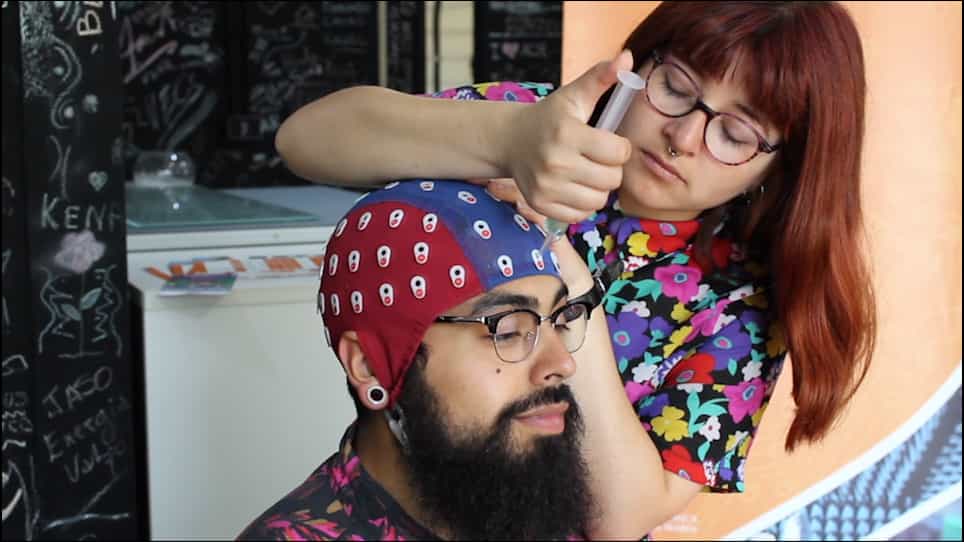
A Method for Tracking the Time Evolution of Steady-State Evoked Potentials
Published on: May 25, 2019
Study of the nonlocal active sound control with preservation of desired field in time domain
Chuxiong Zhou1, Sergey Utyuzhnikov1
1Department of Mechanical, Aerospace & Civil Engineering, University of Manchester, Manchester M13 9PL, United Kingdom.

Abstract:
In the active sound control, a domain is protected from externally generated noise via constructing secondary sound sources, which are called controls. These controls are applied on the boundary of the shielded domain. Apart from the external noise, a desired sound generated by interior sources should also be retained inside the shielded domain. However, it turns out it is a challenge to preserve the internally generated sound unaffected due to both the reverse effect of the controls on the input data and sparse distribution on the boundary. To take into account the reverse effect, an innovative algorithm based on nonlocal control is implemented in the time domain for the first time. Its real-time practical implementation may include preliminary tuning to the real surrounding conditions. A number of test cases are considered including external broadband noise and internal monochromatic desired sound. A sensitivity analysis is carried out with respect to some key design parameters such as density of sensors and controls as well as respective geometrical displacement from one another determined by the Hausdorff distance. It is demonstrated that the nonlocal control provides the noise attenuation level, which is not very sensitive to the presence of the desired sound.
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:24
Frequency-Domain Interpretation of PD Control
The proportional control gain, combined with the...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...