Related Experiment Video
Updated: Nov 21, 2025
Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
Enhanced-coupling nonlinear controller design for load swing suppression in three-dimensional overhead cranes with
Huimin Ouyang1, Bingqing Zhao1, Guangming Zhang1
1College of Electrical Engineering and Control Science, Nanjing Tech University, No.30, Puzhu Road(s), Nanjing, 211816, China.

Abstract:
To date, most control strategies have been designed for the two-dimensional and three-dimensional overhead crane systems with the single pendulum effect. In fact, three-dimensional overhead crane systems often exhibit the double-pendulum effect in practical applications, which is more controlled than the general single-pendulum crane, and also makes the controller design more challenging. This paper proposes a new nonlinear control strategy that enhances the coupling between the trolley speed and the swing angle components. Specifically, we devise a new energy-like function by introducing two generalized signals that can reflect the trolley speed and the hook and load swing angle components. This strategy greatly improves the effectiveness of the transient control process. Meanwhile, the asymptotic stability of the closed-loop system is not only guaranteed, but also the desired position of the trolley and swing angle suppression are achieved using the control strategy.

Related Concept Videos
 01:24
Frames: Problem Solving I
 01:14
Stability of structures
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:13
Impact Loading on a Cantilever Beam
When an object is dropped onto the free end of a cantilever, its potential energy due to gravity is...
 01:09
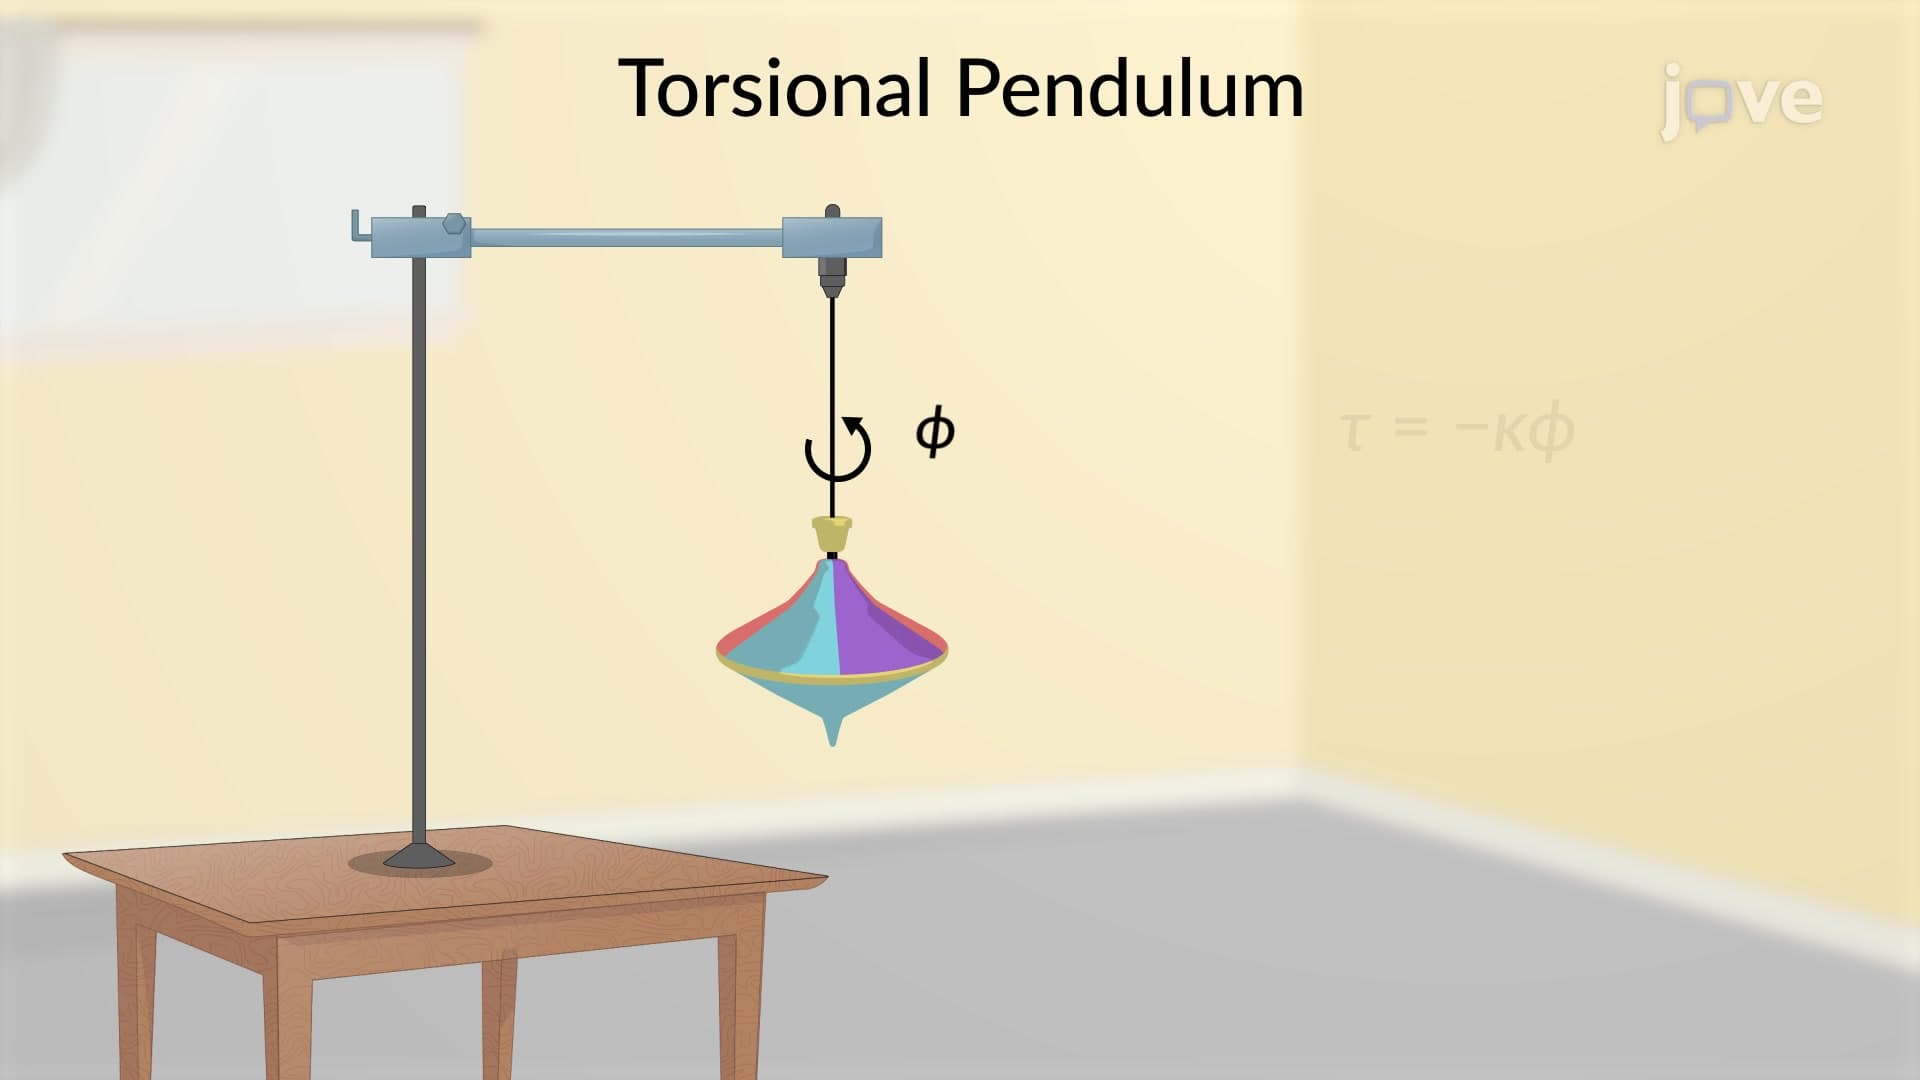
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...