Related Experiment Video
Updated: Nov 19, 2025
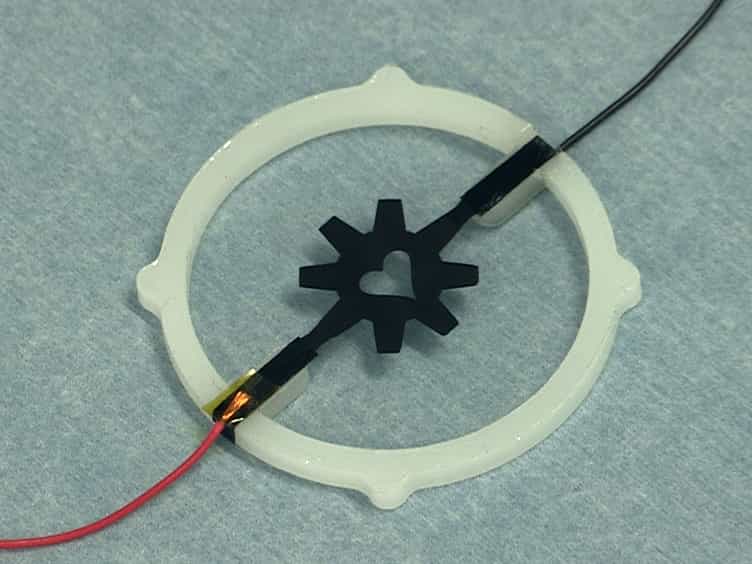

Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
A Worm-Like Biomimetic Crawling Robot Based on Cylindrical Dielectric Elastomer Actuators
Sascha Pfeil1, Markus Henke2,3, Konrad Katzer4,5
1Faculty of Electrical and Computer Engineering, Institute of Solid State Electronics, Technische Universität Dresden, Dresden, Germany.

Abstract:
In recent years the field of soft robotics has gained a lot of interest both in academia and industry. In contrast to rigid robots, which are potentially very powerful and precise, soft robots are composed of compliant materials like gels or elastomers (Rich et al., 2018; Majidi, 2019). Their exclusive composition of nearly entirely soft materials offers the potential to extend the use of robotics to fields like healthcare (Burgner-Kahrs et al., 2015; Banerjee et al., 2018) and advance the emerging domain of cooperative human-machine interaction (Asbeck et al., 2014). One material class used frequently in soft robotics as actuators are electroactive polymers (EAPs). Especially dielectric elastomer actuators (DEAs) consisting of a thin elastomer membrane sandwiched between two compliant electrodes offer promising characteristics for actuator drives (Pelrine et al., 2000). Under an applied electric field, the resulting electrostatic pressure leads to a reduction in thickness and an expansion in the free spatial directions. The resulting expansion can reach strain levels of more than 300% (Bar-Cohen, 2004). This paper presents a bioinspired worm-like crawling robot based on DEAs with additional textile reinforcement in its silicone structures. A special focus is set on the developed cylindrical actuator segments that act as linear actuators.

Related Concept Videos
 01:31
Mechanism of Lamellipodia Formation
 01:13
Actin Polymerization and Cell Motility
Actin cytoskeleton dynamics can produce pushing, pulling, and resistance forces that help the cell to migrate....
 01:18
Actin Treadmilling